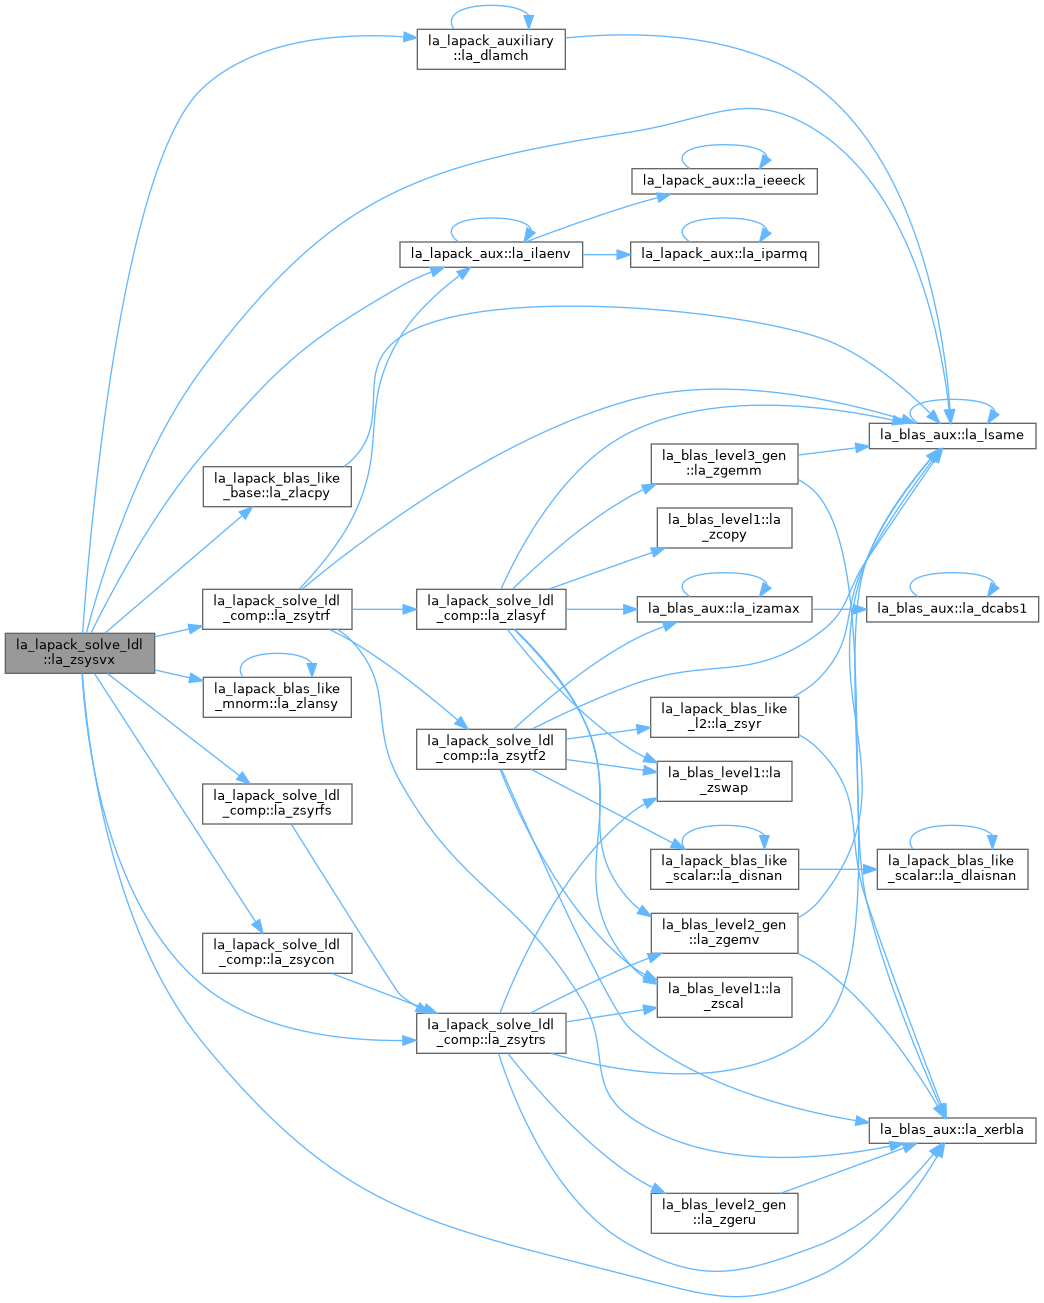
Symmetric and Hermitian indefinite drivers. More...
Functions/Subroutines | |
| pure subroutine, public | la_sspsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| SSPSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_dspsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| DSPSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_qspsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| QSPSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| subroutine, public | la_sspsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, iwork, info) |
| SSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_dspsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, iwork, info) |
| DSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_qspsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, iwork, info) |
| QSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| pure subroutine, public | la_ssysv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| SSYSV_RK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. SSYTRF_RK is called to compute the factorization of a real symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine SSYTRS_3. | |
| pure subroutine, public | la_dsysv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| DSYSV_RK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. DSYTRF_RK is called to compute the factorization of a real symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine DSYTRS_3. | |
| pure subroutine, public | la_qsysv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| QSYSV_RK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. QSYTRF_RK is called to compute the factorization of a real symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine QSYTRS_3. | |
| pure subroutine, public | la_ssysv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| SSYSV_ROOK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. SSYTRF_ROOK is called to compute the factorization of a real symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling SSYTRS_ROOK. | |
| pure subroutine, public | la_dsysv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| DSYSV_ROOK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. DSYTRF_ROOK is called to compute the factorization of a real symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling DSYTRS_ROOK. | |
| pure subroutine, public | la_qsysv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| QSYSV_ROOK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. QSYTRF_ROOK is called to compute the factorization of a real symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling QSYTRS_ROOK. | |
| pure subroutine, public | la_ssysv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| SSYSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_dsysv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| DSYSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_qsysv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| QSYSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| subroutine, public | la_ssysvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, iwork, info) |
| SSYSVX: uses the diagonal pivoting factorization to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_dsysvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, iwork, info) |
| DSYSVX: uses the diagonal pivoting factorization to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_qsysvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, iwork, info) |
| QSYSVX: uses the diagonal pivoting factorization to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
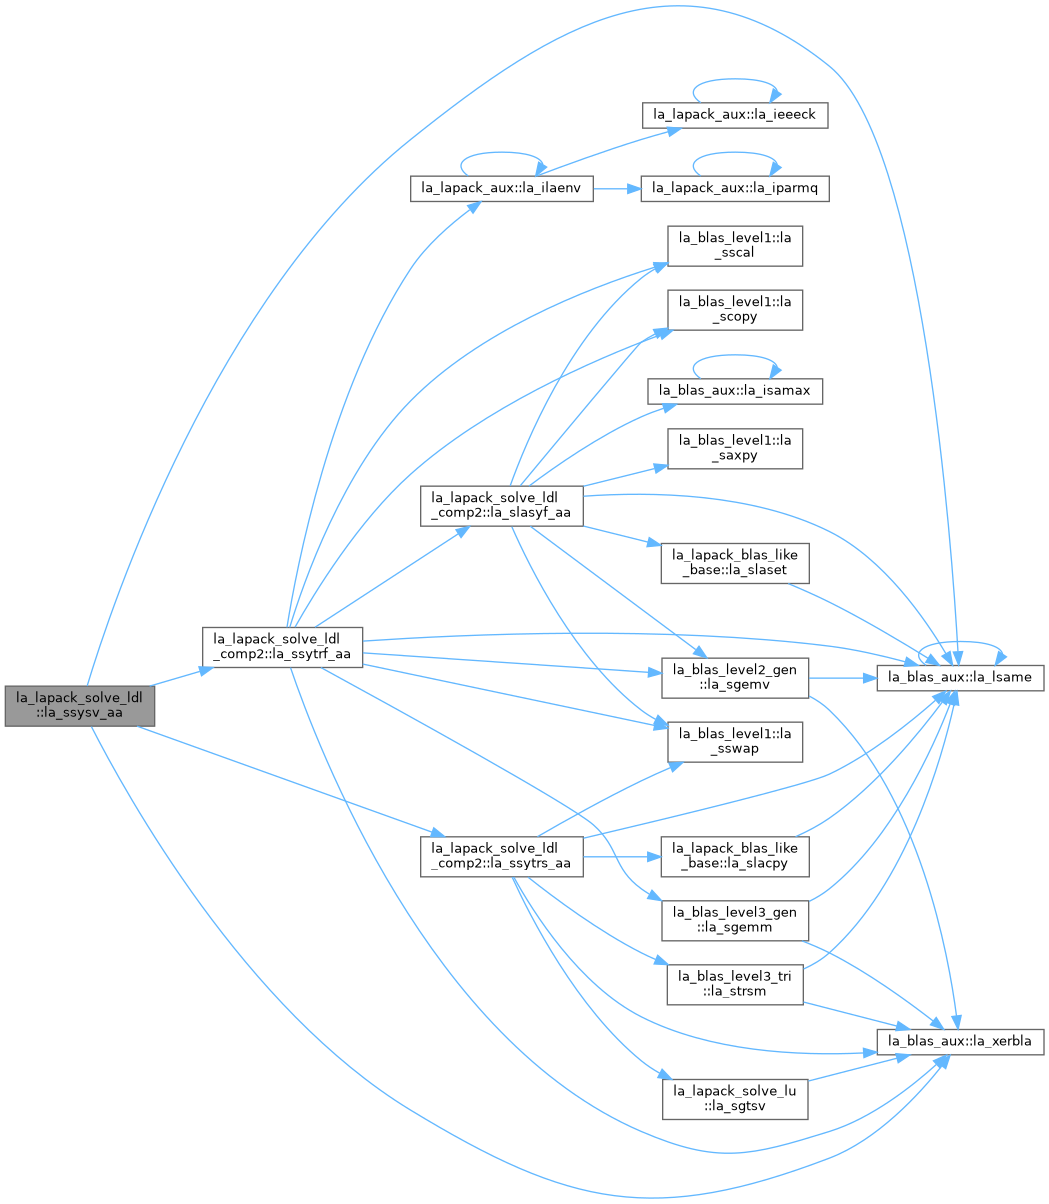
| pure subroutine, public | la_ssysv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| SSYSV computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_dsysv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| DSYSV computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_qsysv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| QSYSV computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_cspsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| CSPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_zspsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| ZSPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_wspsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| WSPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| subroutine, public | la_cspsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, rwork, info) |
| CSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_zspsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, rwork, info) |
| ZSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_wspsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, rwork, info) |
| WSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| pure subroutine, public | la_csysv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| CSYSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_zsysv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| ZSYSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_wsysv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| WSYSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_csysv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| CSYSV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CSYTRF_RK is called to compute the factorization of a complex symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine CSYTRS_3. | |
| pure subroutine, public | la_zsysv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| ZSYSV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZSYTRF_RK is called to compute the factorization of a complex symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine ZSYTRS_3. | |
| pure subroutine, public | la_wsysv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| WSYSV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WSYTRF_RK is called to compute the factorization of a complex symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine WSYTRS_3. | |
| pure subroutine, public | la_csysv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| CSYSV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CSYTRF_ROOK is called to compute the factorization of a complex symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling CSYTRS_ROOK. | |
| pure subroutine, public | la_zsysv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| ZSYSV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZSYTRF_ROOK is called to compute the factorization of a complex symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling ZSYTRS_ROOK. | |
| pure subroutine, public | la_wsysv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| WSYSV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WSYTRF_ROOK is called to compute the factorization of a complex symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling WSYTRS_ROOK. | |
| subroutine, public | la_csysvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, rwork, info) |
| CSYSVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_zsysvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, rwork, info) |
| ZSYSVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_wsysvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, rwork, info) |
| WSYSVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| pure subroutine, public | la_chesv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| CHESV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_zhesv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| ZHESV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_whesv (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| WHESV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_chesv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| CHESV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**H)*(P**T), if UPLO = 'U', or A = P*L*D*(L**H)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**H (or L**H) is the conjugate of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CHETRF_RK is called to compute the factorization of a complex Hermitian matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine CHETRS_3. | |
| pure subroutine, public | la_zhesv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| ZHESV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**H)*(P**T), if UPLO = 'U', or A = P*L*D*(L**H)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**H (or L**H) is the conjugate of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZHETRF_RK is called to compute the factorization of a complex Hermitian matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine ZHETRS_3. | |
| pure subroutine, public | la_whesv_rk (uplo, n, nrhs, a, lda, e, ipiv, b, ldb, work, lwork, info) |
| WHESV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**H)*(P**T), if UPLO = 'U', or A = P*L*D*(L**H)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**H (or L**H) is the conjugate of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WHETRF_RK is called to compute the factorization of a complex Hermitian matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine WHETRS_3. | |
| pure subroutine, public | la_chesv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| CHESV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman ("rook") diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CHETRF_ROOK is called to compute the factorization of a complex Hermition matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling CHETRS_ROOK (uses BLAS 2). | |
| pure subroutine, public | la_zhesv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| ZHESV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman ("rook") diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZHETRF_ROOK is called to compute the factorization of a complex Hermition matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling ZHETRS_ROOK (uses BLAS 2). | |
| pure subroutine, public | la_whesv_rook (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| WHESV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman ("rook") diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WHETRF_ROOK is called to compute the factorization of a complex Hermition matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling WHETRS_ROOK (uses BLAS 2). | |
| subroutine, public | la_chesvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, rwork, info) |
| CHESVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_zhesvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, rwork, info) |
| ZHESVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_whesvx (fact, uplo, n, nrhs, a, lda, af, ldaf, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, lwork, rwork, info) |
| WHESVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| pure subroutine, public | la_chpsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| CHPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_zhpsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| ZHPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_whpsv (uplo, n, nrhs, ap, ipiv, b, ldb, info) |
| WHPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B. | |
| subroutine, public | la_chpsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, rwork, info) |
| CHPSVX: uses the diagonal pivoting factorization A = U*D*U**H or A = L*D*L**H to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_zhpsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, rwork, info) |
| ZHPSVX: uses the diagonal pivoting factorization A = U*D*U**H or A = L*D*L**H to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| subroutine, public | la_whpsvx (fact, uplo, n, nrhs, ap, afp, ipiv, b, ldb, x, ldx, rcond, ferr, berr, work, rwork, info) |
| WHPSVX: uses the diagonal pivoting factorization A = U*D*U**H or A = L*D*L**H to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided. | |
| pure subroutine, public | la_chesv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| CHESV_AA: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**H * T * U, if UPLO = 'U', or A = L * T * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is Hermitian and tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_zhesv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| ZHESV_AA: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**H * T * U, if UPLO = 'U', or A = L * T * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is Hermitian and tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_whesv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| WHESV_AA: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**H * T * U, if UPLO = 'U', or A = L * T * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is Hermitian and tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_csysv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| CSYSV computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_zsysv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| ZSYSV computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
| pure subroutine, public | la_wsysv_aa (uplo, n, nrhs, a, lda, ipiv, b, ldb, work, lwork, info) |
| WSYSV computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B. | |
Detailed Description
Symmetric and Hermitian indefinite drivers.
Function/Subroutine Documentation
◆ la_chesv()
| pure subroutine, public la_lapack_solve_ldl::la_chesv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
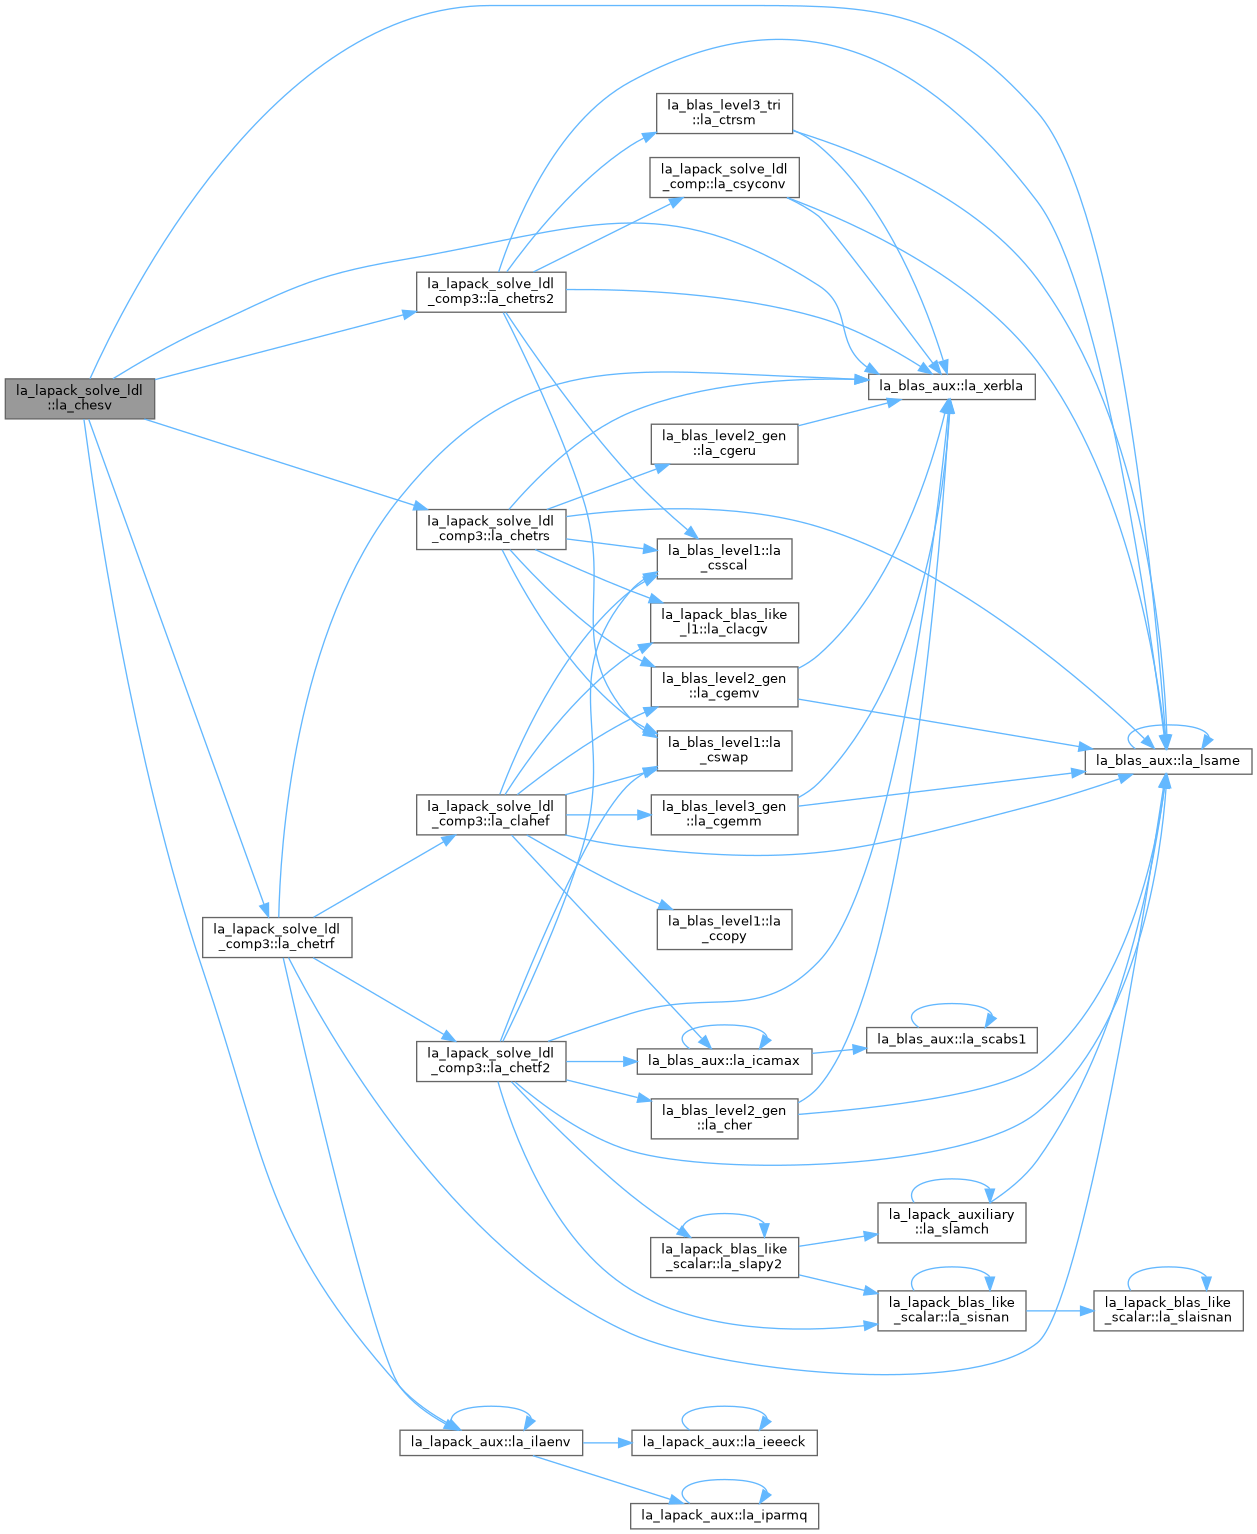
CHESV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_chesv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_chesv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
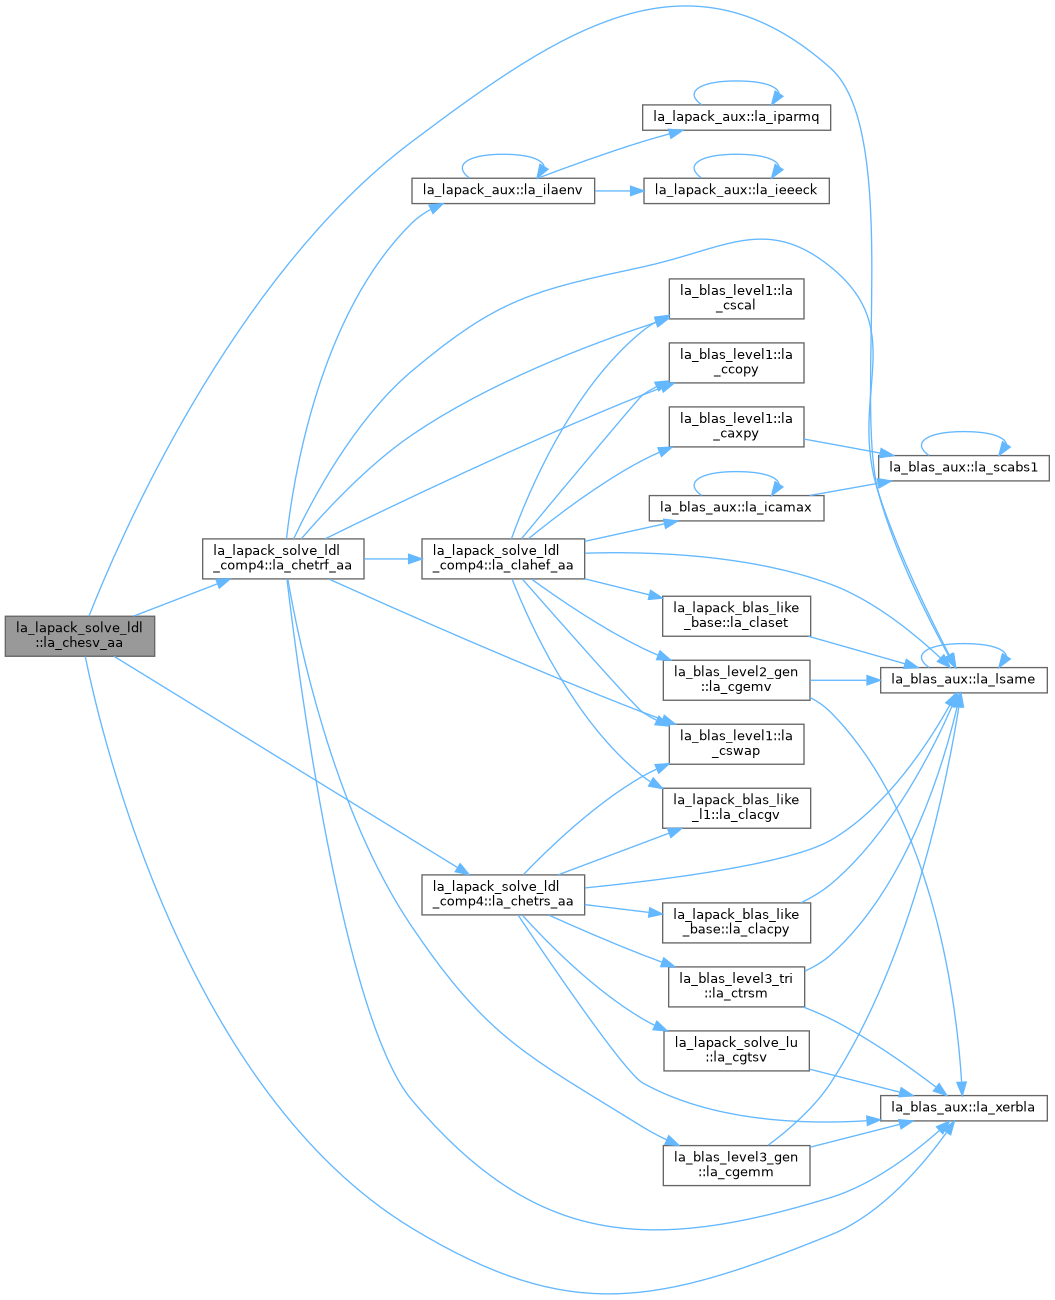
CHESV_AA: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**H * T * U, if UPLO = 'U', or A = L * T * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is Hermitian and tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_chesv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_chesv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(sp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
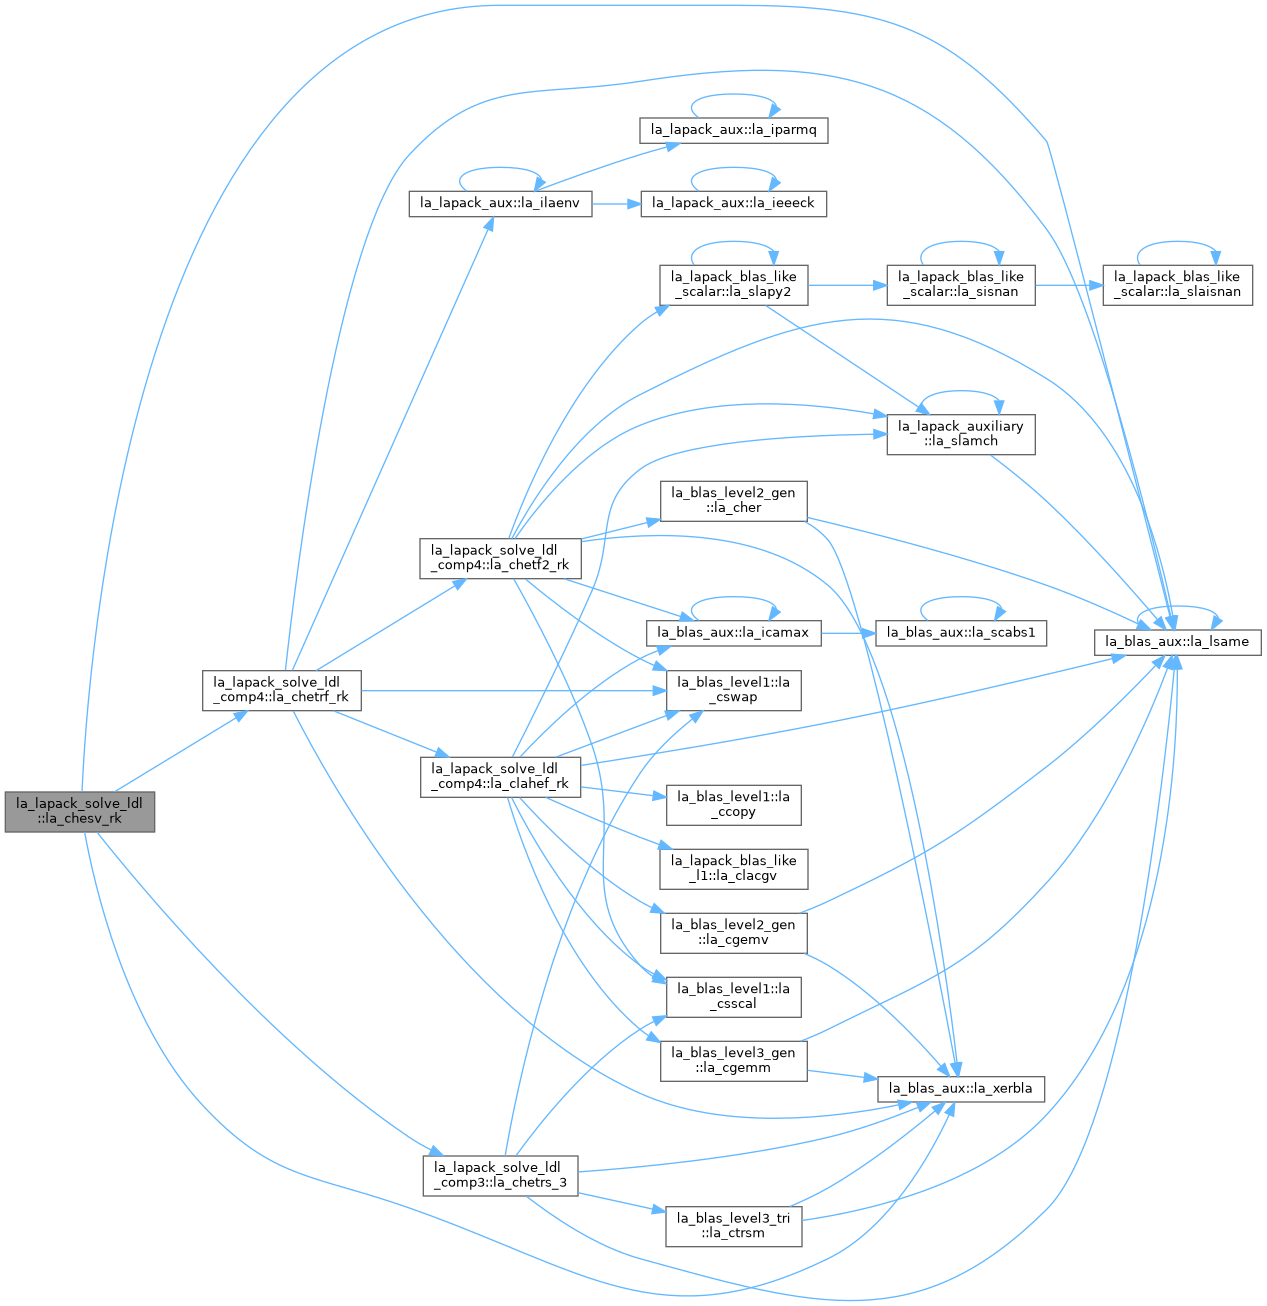
CHESV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**H)*(P**T), if UPLO = 'U', or A = P*L*D*(L**H)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**H (or L**H) is the conjugate of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CHETRF_RK is called to compute the factorization of a complex Hermitian matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine CHETRS_3.
◆ la_chesv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_chesv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
CHESV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman ("rook") diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CHETRF_ROOK is called to compute the factorization of a complex Hermition matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling CHETRS_ROOK (uses BLAS 2).
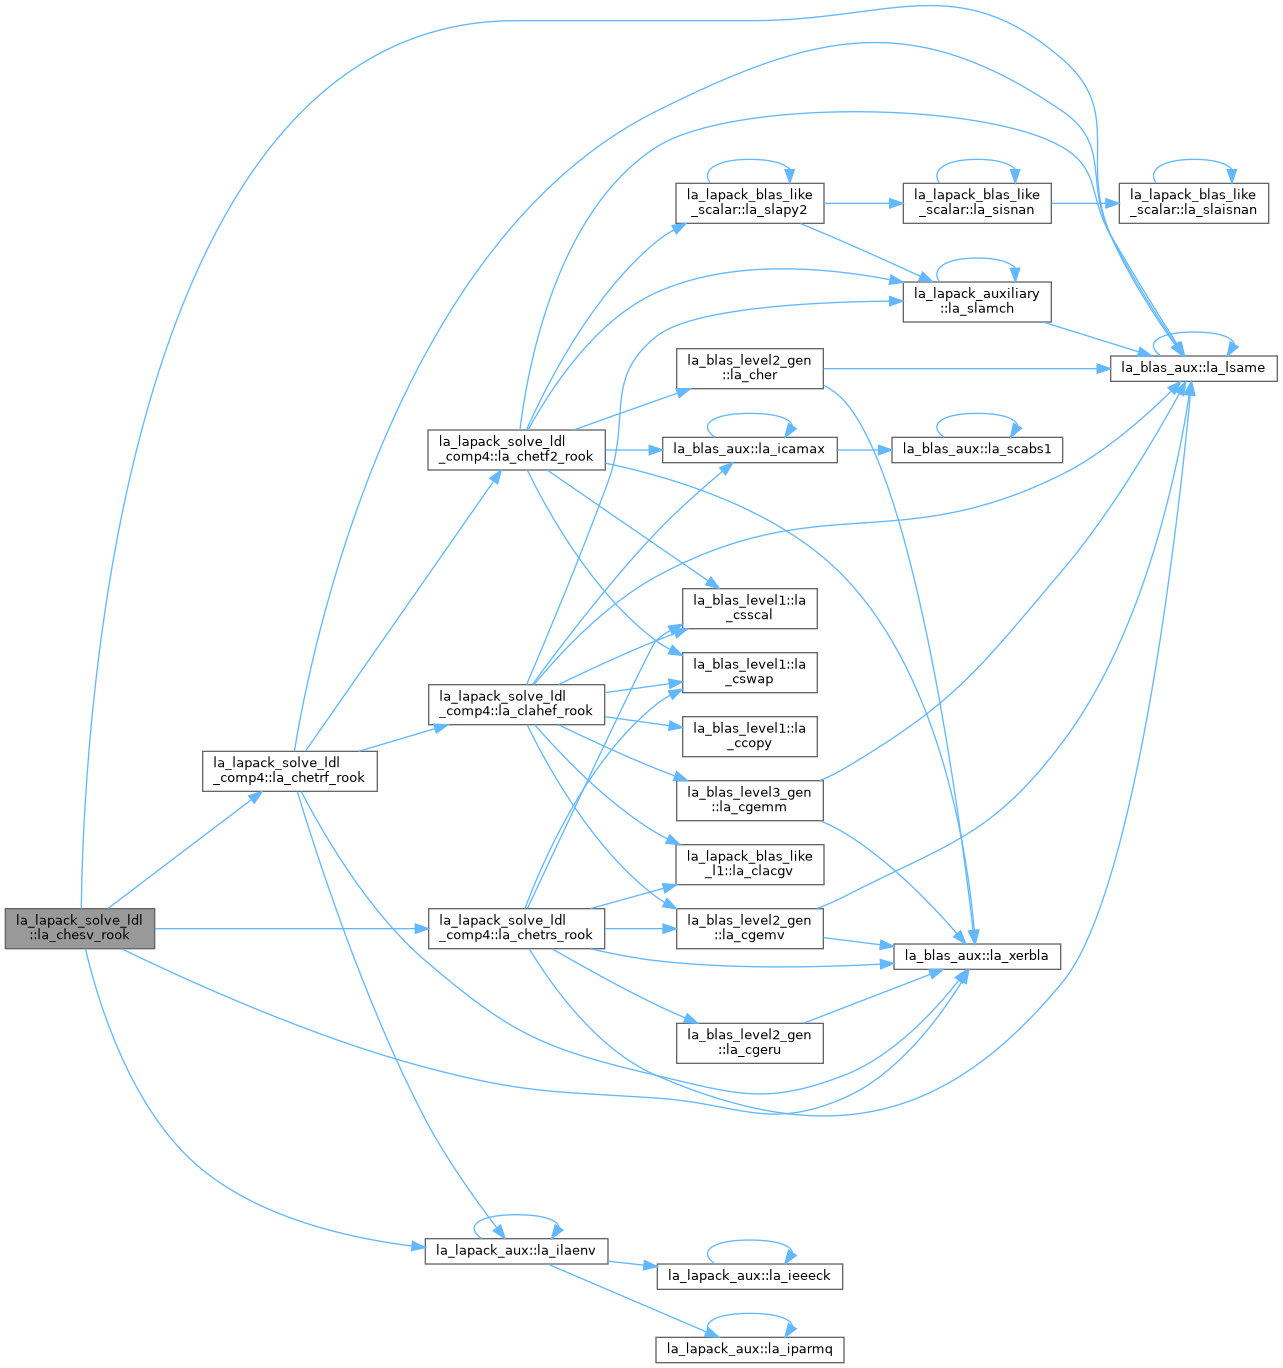
◆ la_chesvx()
| subroutine, public la_lapack_solve_ldl::la_chesvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(sp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(sp), intent(out) | rcond, | ||
| real(sp), dimension(*), intent(out) | ferr, | ||
| real(sp), dimension(*), intent(out) | berr, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| real(sp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
CHESVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
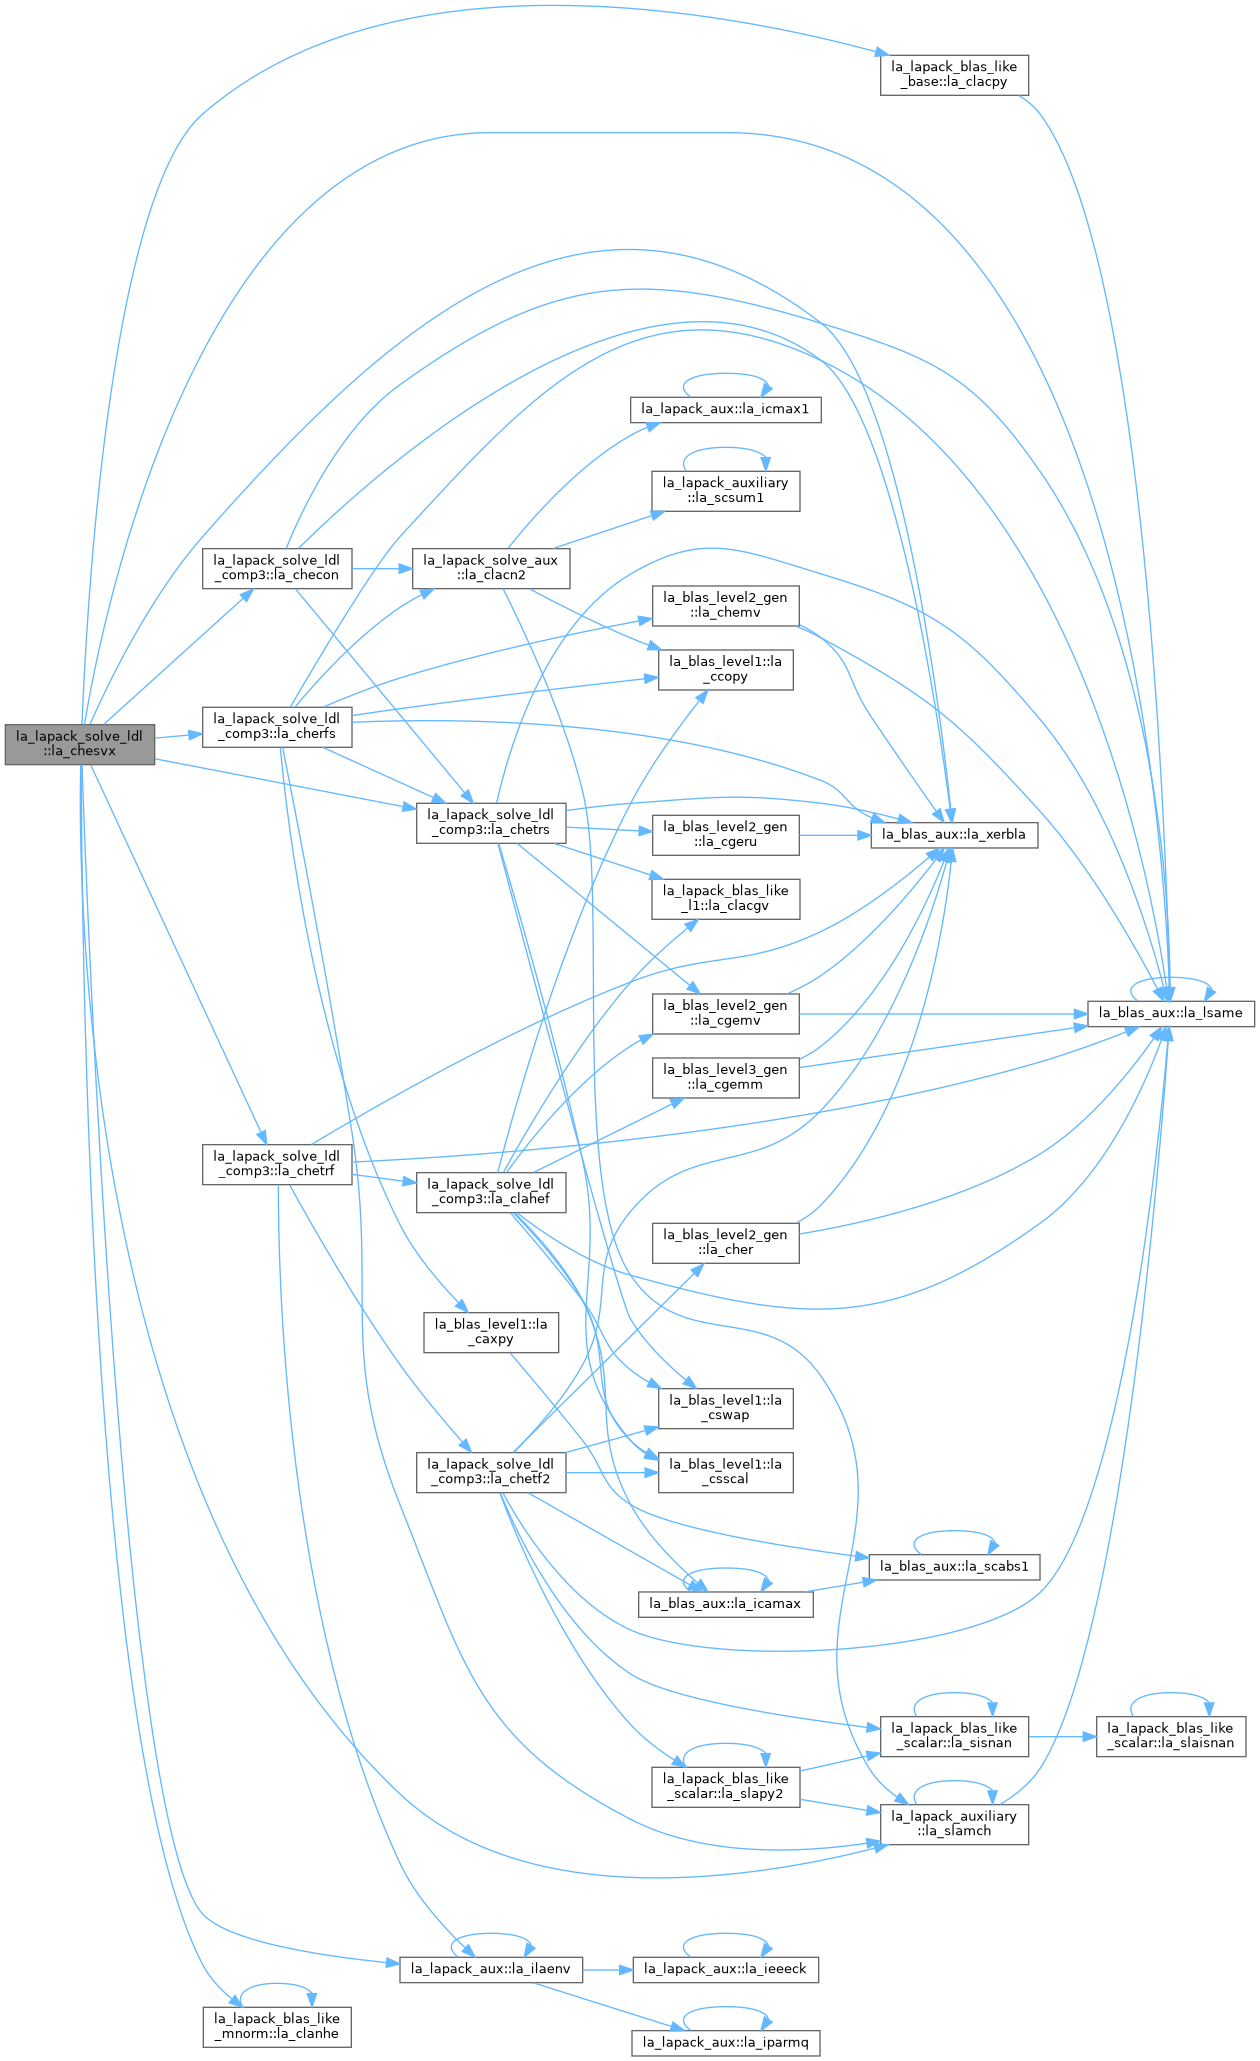
◆ la_chpsv()
| pure subroutine, public la_lapack_solve_ldl::la_chpsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
CHPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
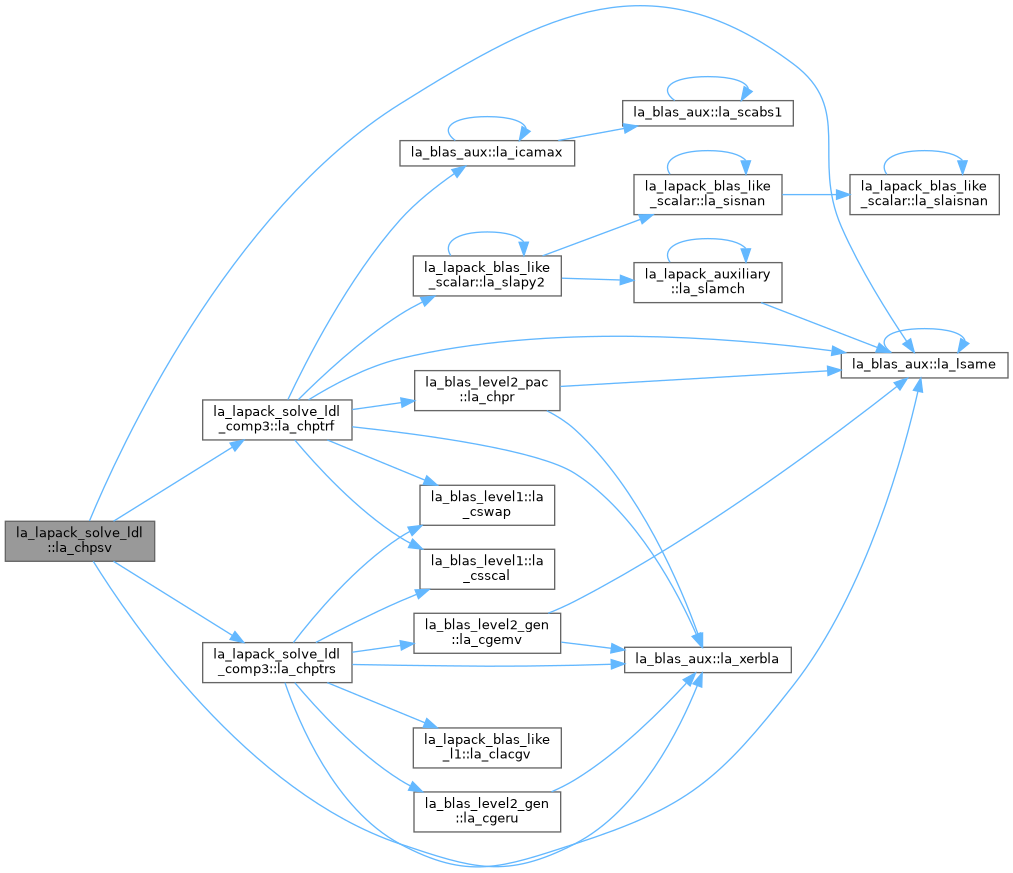
◆ la_chpsvx()
| subroutine, public la_lapack_solve_ldl::la_chpsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(*), intent(in) | ap, | ||
| complex(sp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(sp), intent(out) | rcond, | ||
| real(sp), dimension(*), intent(out) | ferr, | ||
| real(sp), dimension(*), intent(out) | berr, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| real(sp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
CHPSVX: uses the diagonal pivoting factorization A = U*D*U**H or A = L*D*L**H to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
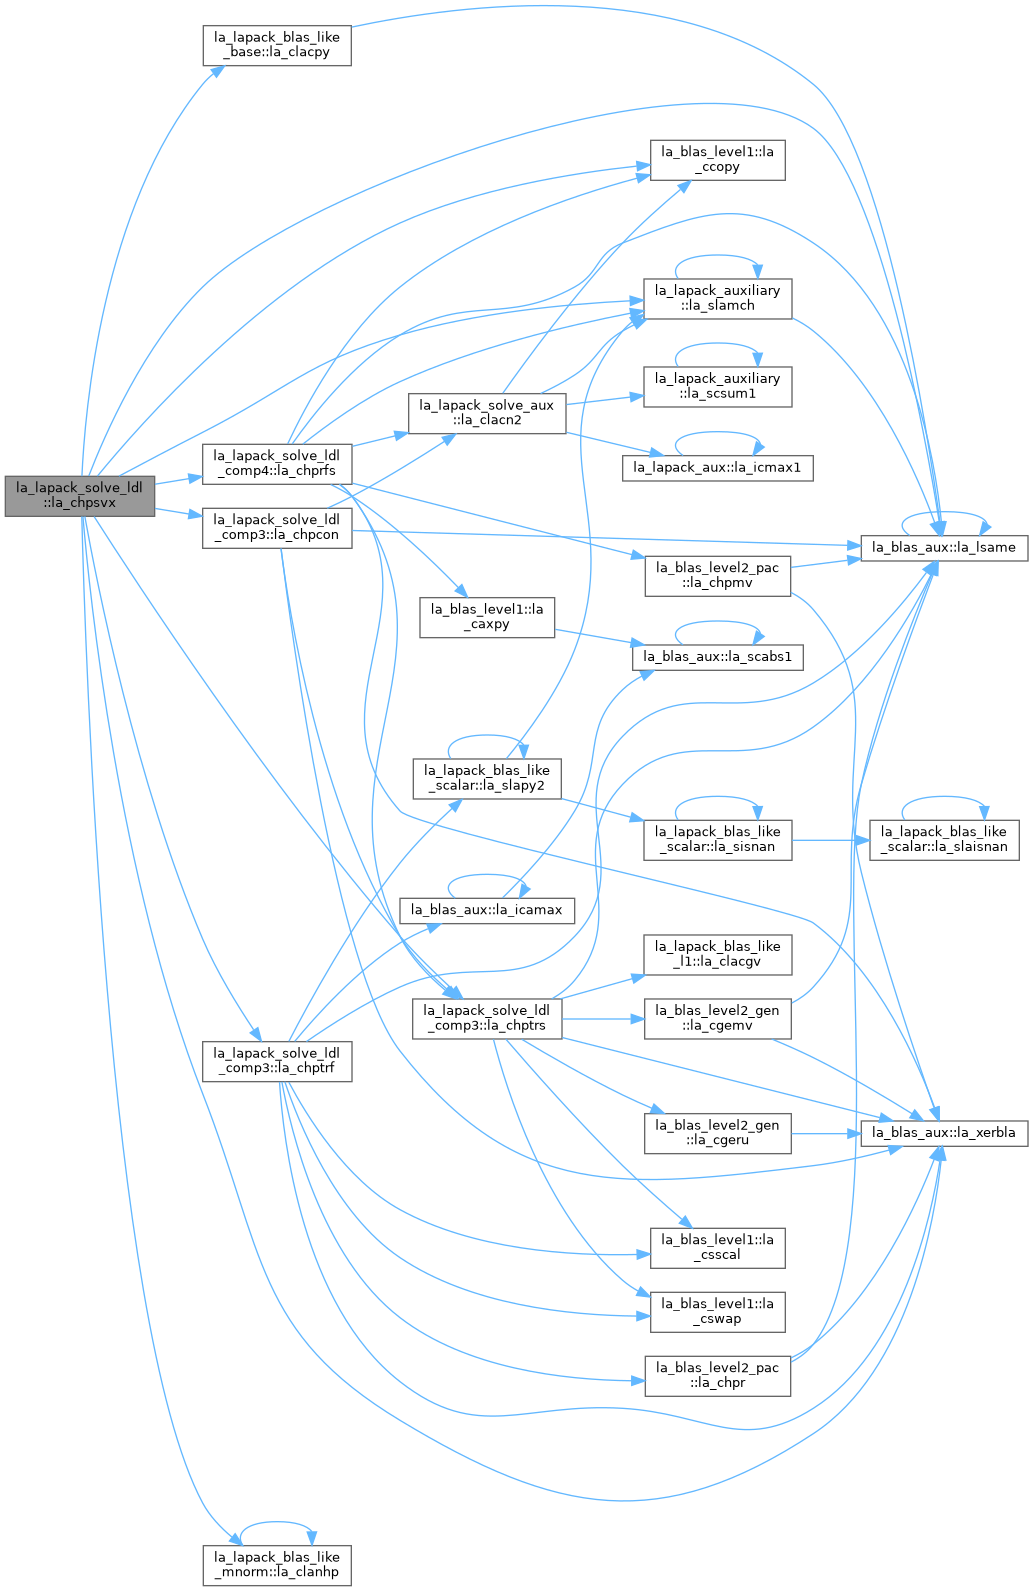
◆ la_cspsv()
| pure subroutine, public la_lapack_solve_ldl::la_cspsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
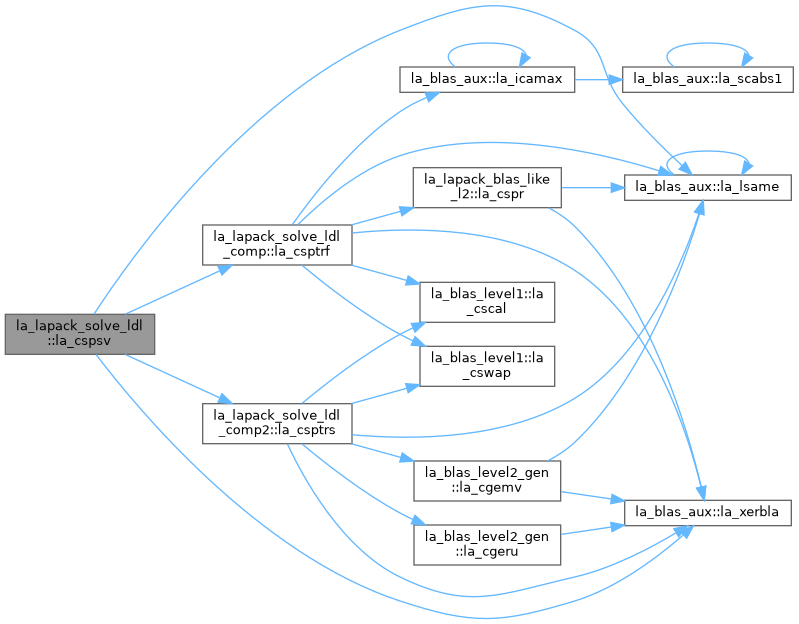
CSPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_cspsvx()
| subroutine, public la_lapack_solve_ldl::la_cspsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(*), intent(in) | ap, | ||
| complex(sp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(sp), intent(out) | rcond, | ||
| real(sp), dimension(*), intent(out) | ferr, | ||
| real(sp), dimension(*), intent(out) | berr, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| real(sp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
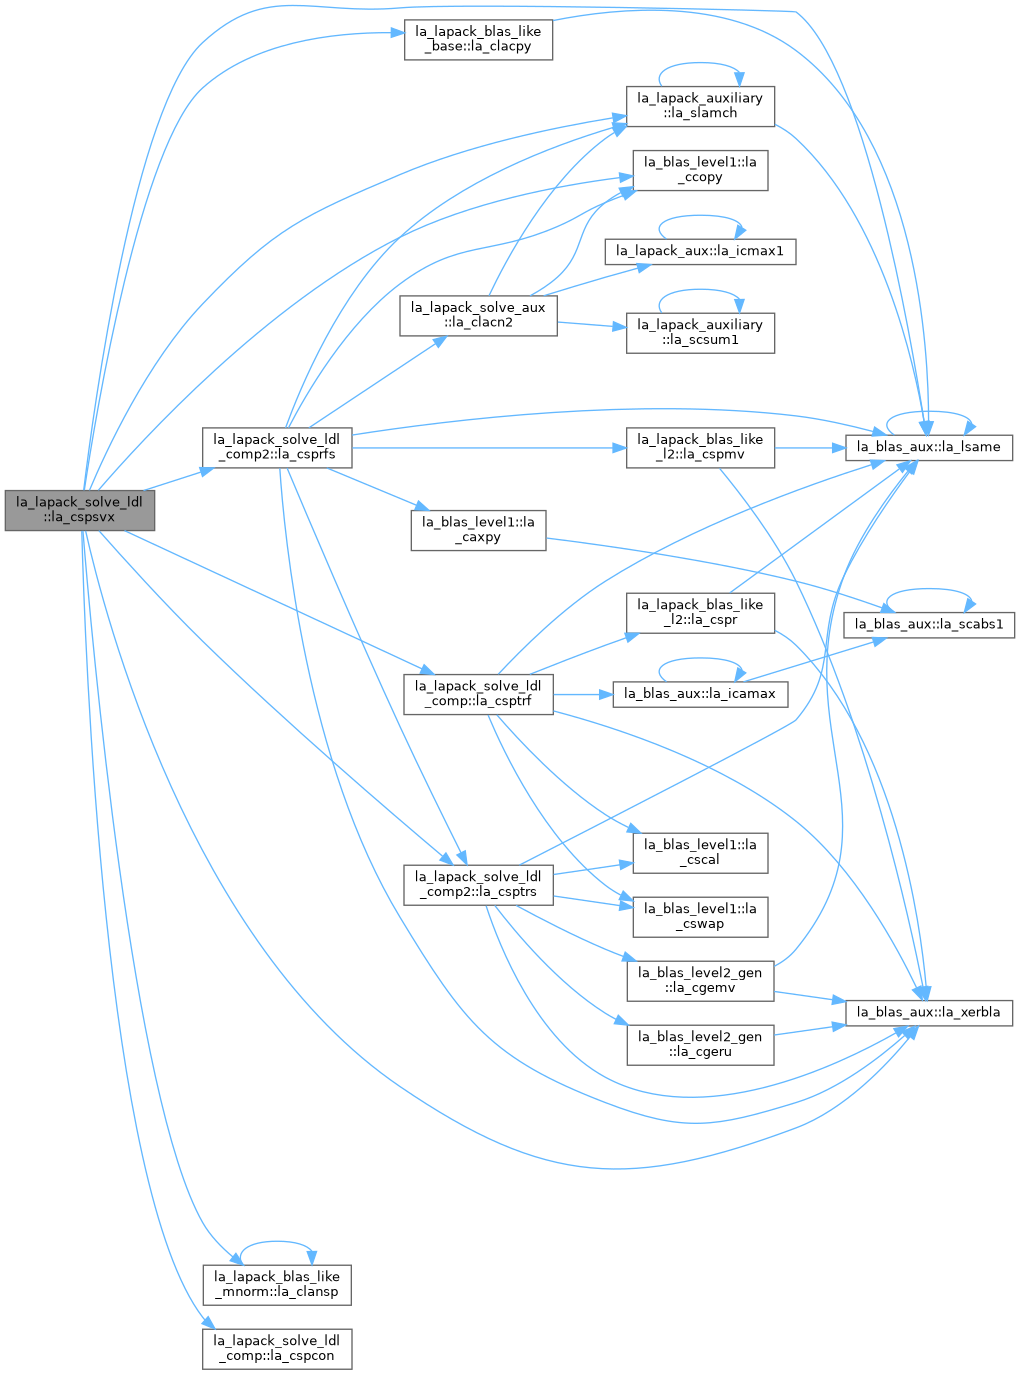
CSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
◆ la_csysv()
| pure subroutine, public la_lapack_solve_ldl::la_csysv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
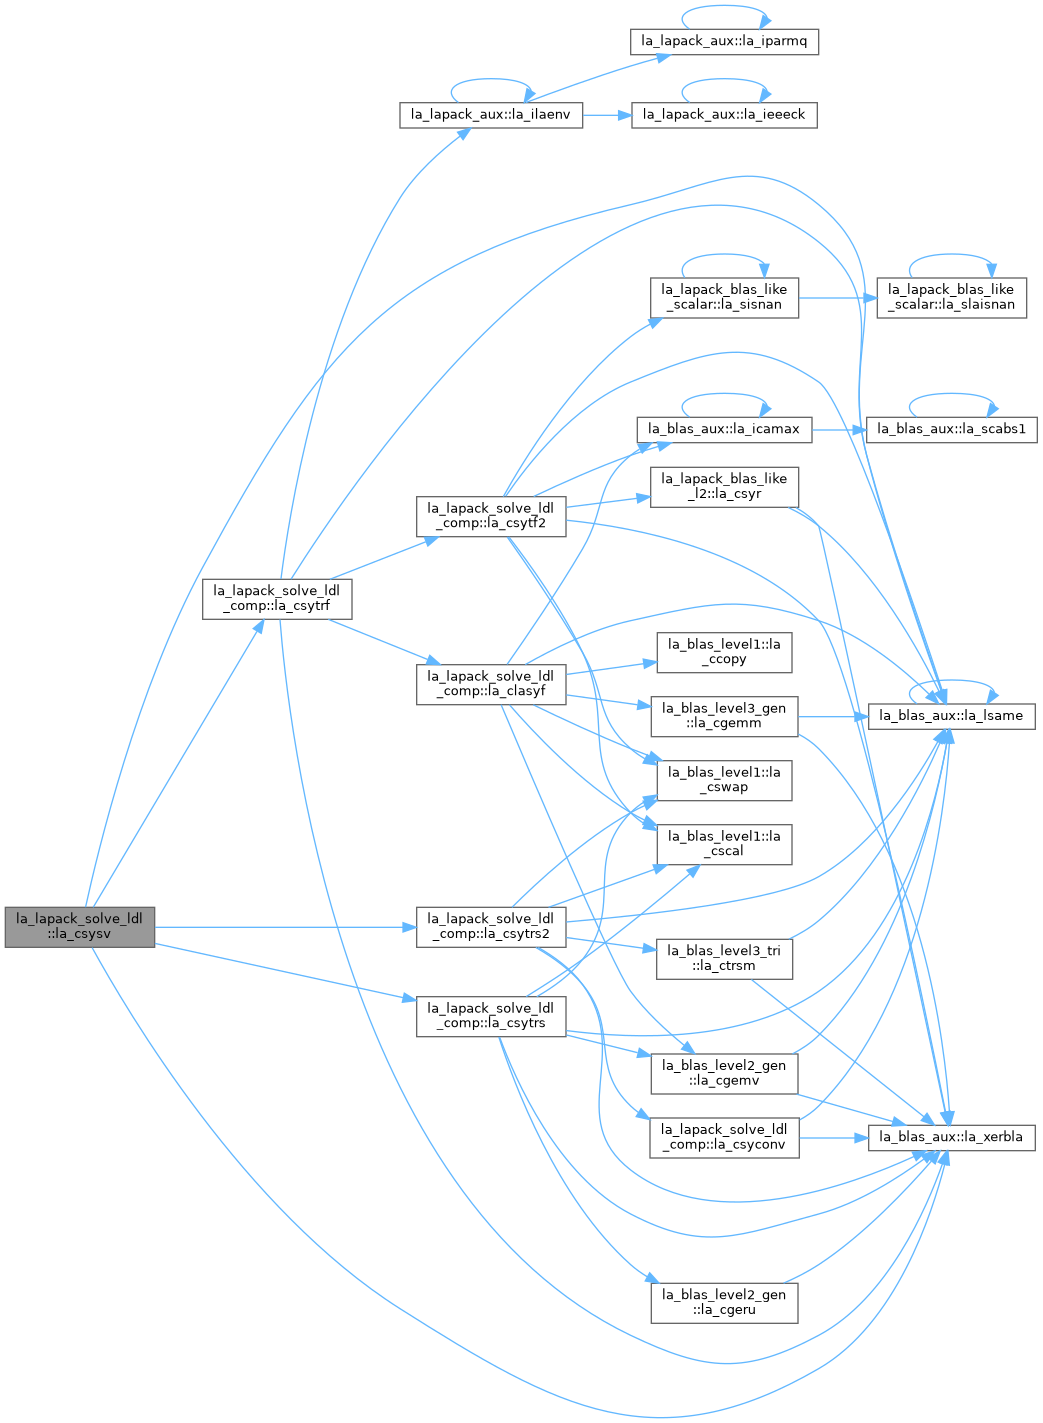
CSYSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_csysv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_csysv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
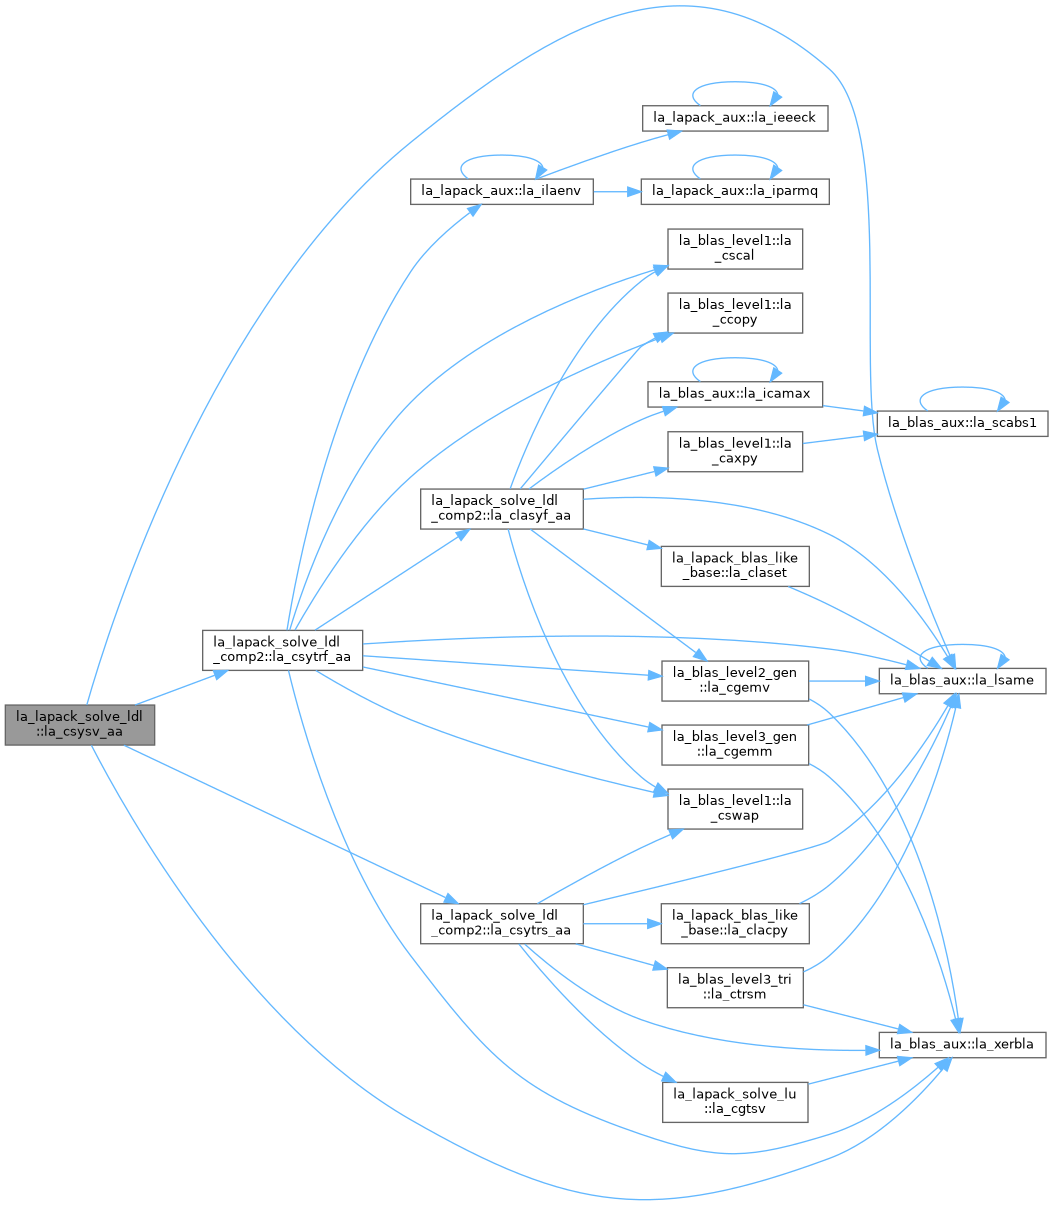
CSYSV computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_csysv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_csysv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(sp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
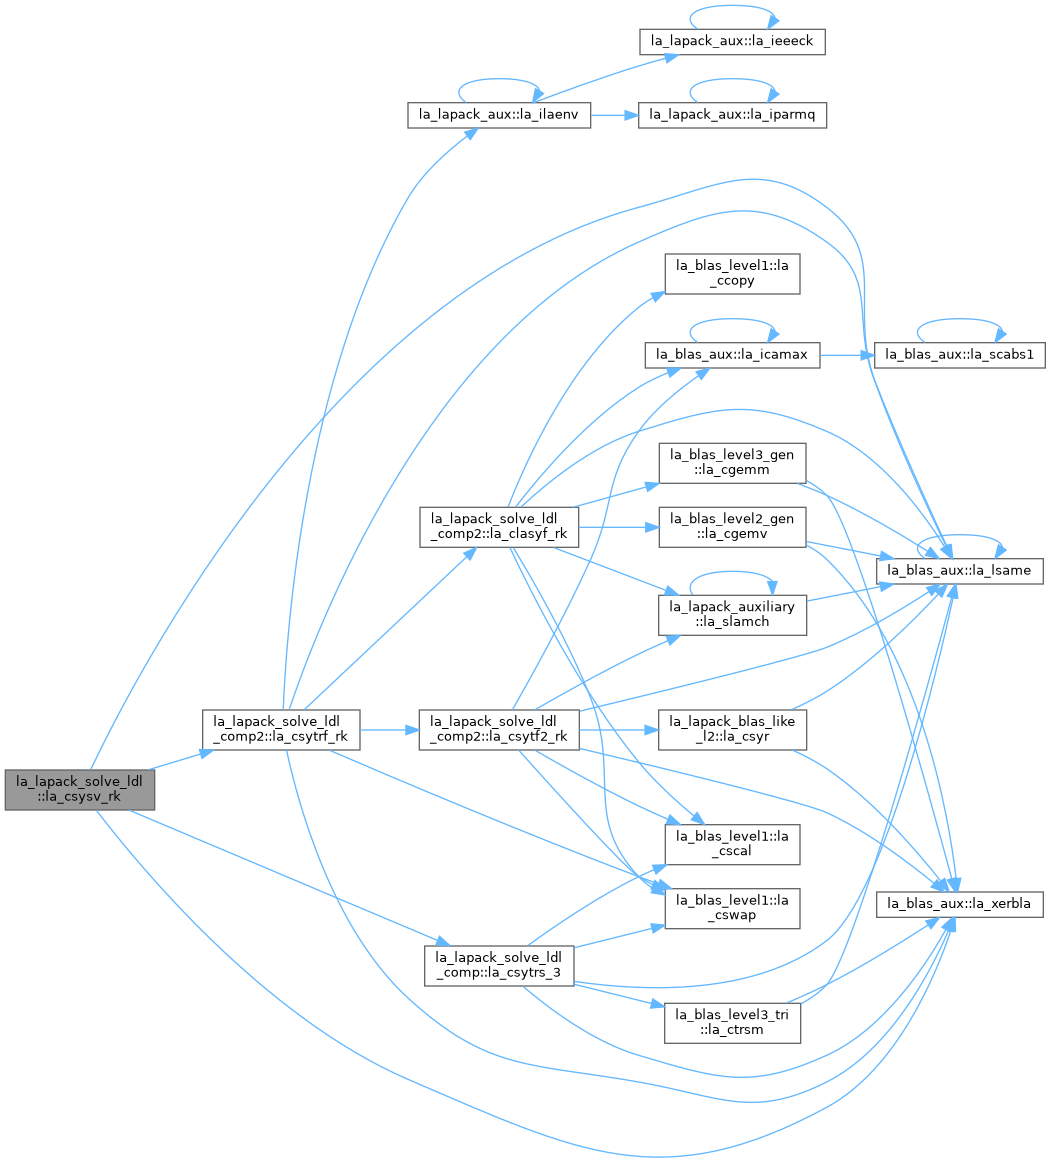
CSYSV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CSYTRF_RK is called to compute the factorization of a complex symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine CSYTRS_3.
◆ la_csysv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_csysv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
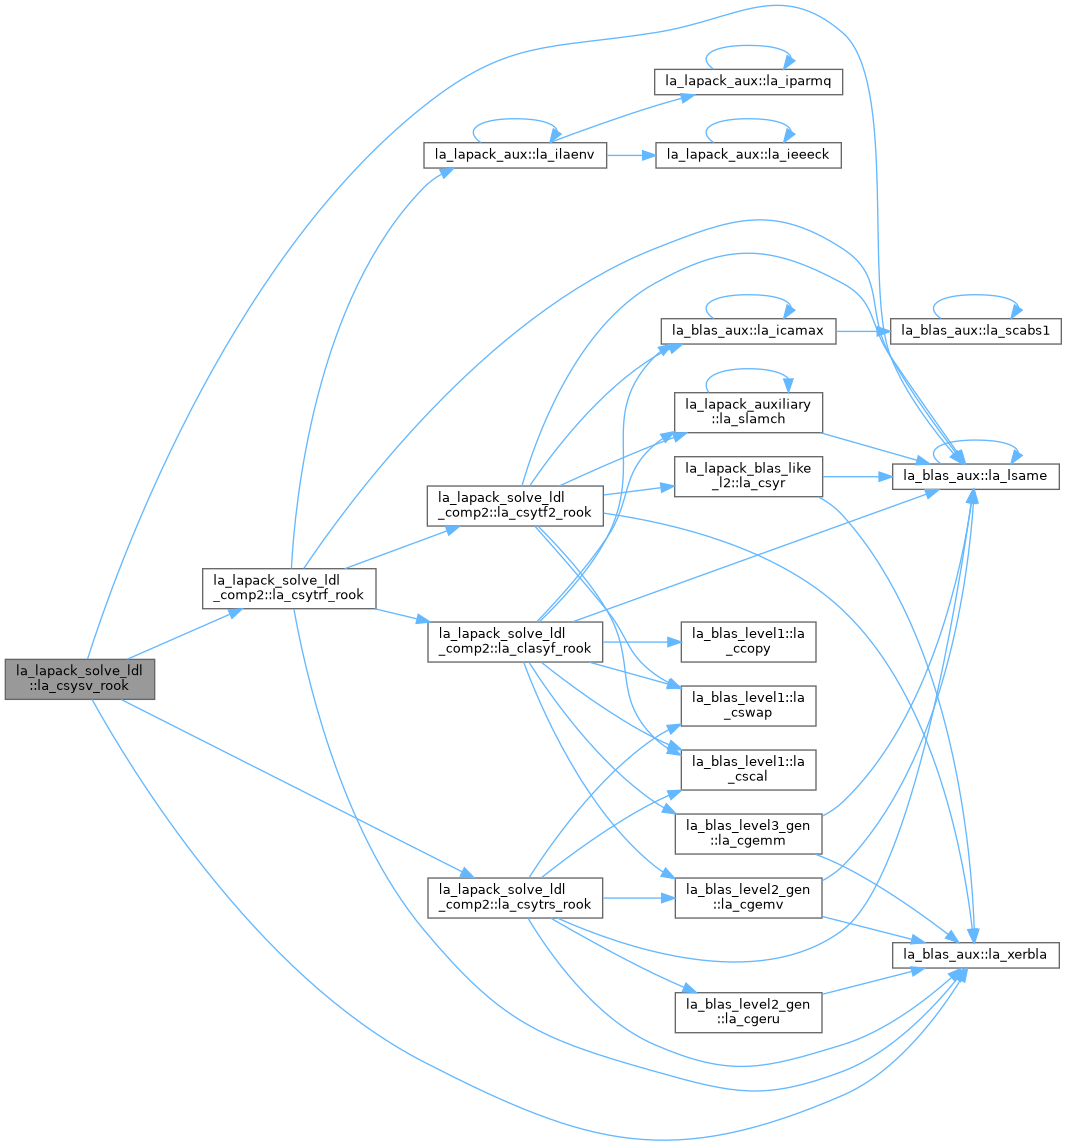
CSYSV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. CSYTRF_ROOK is called to compute the factorization of a complex symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling CSYTRS_ROOK.
◆ la_csysvx()
| subroutine, public la_lapack_solve_ldl::la_csysvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(sp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(sp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(sp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(sp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(sp), intent(out) | rcond, | ||
| real(sp), dimension(*), intent(out) | ferr, | ||
| real(sp), dimension(*), intent(out) | berr, | ||
| complex(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| real(sp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
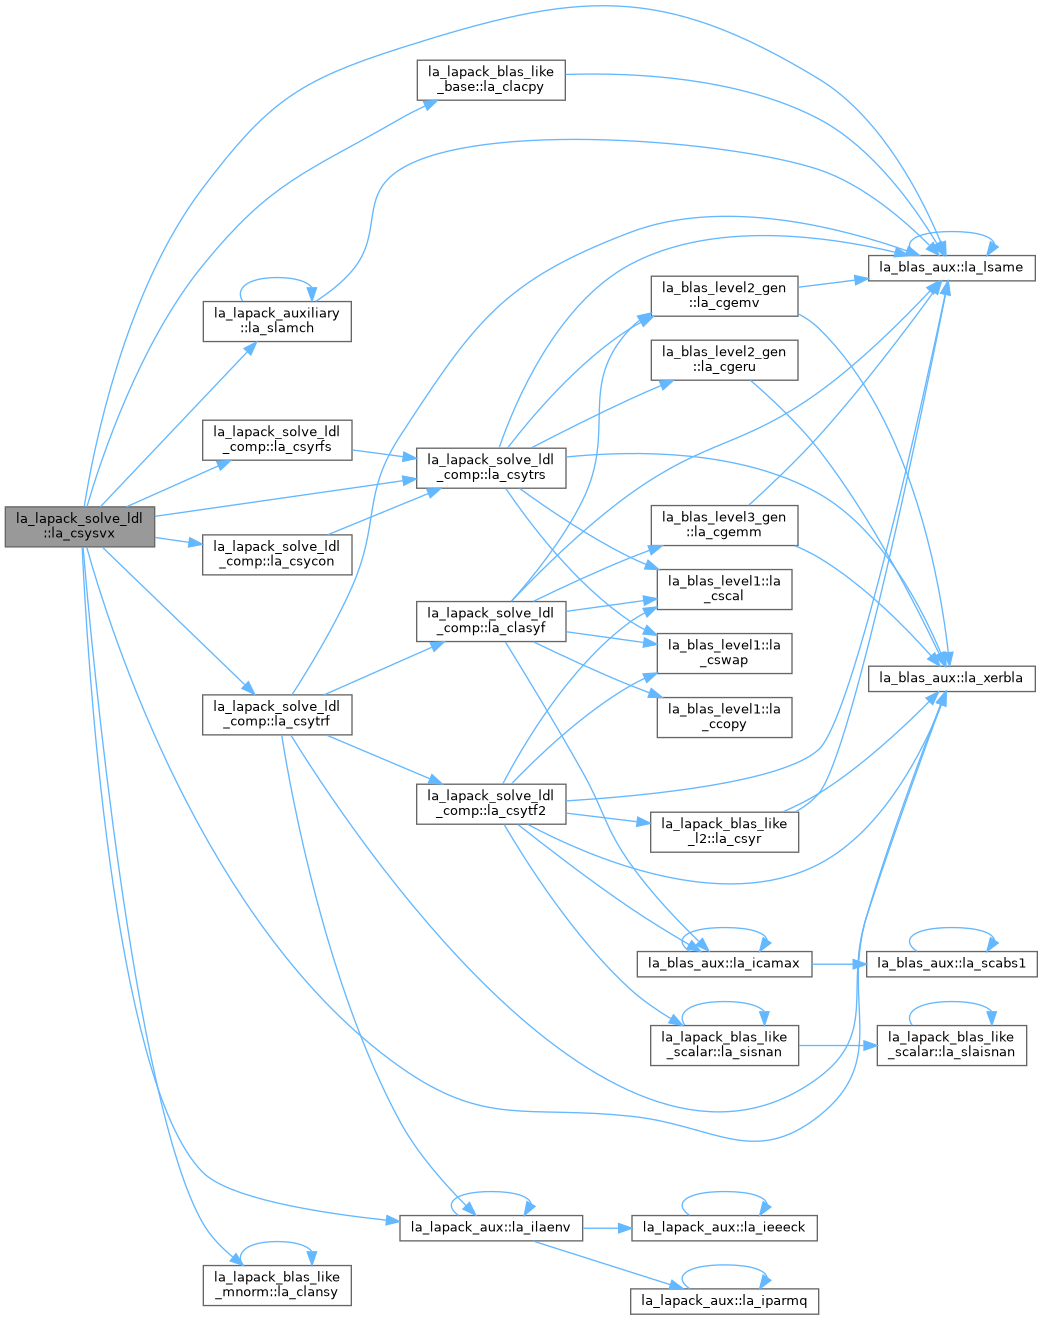
CSYSVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
◆ la_dspsv()
| pure subroutine, public la_lapack_solve_ldl::la_dspsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
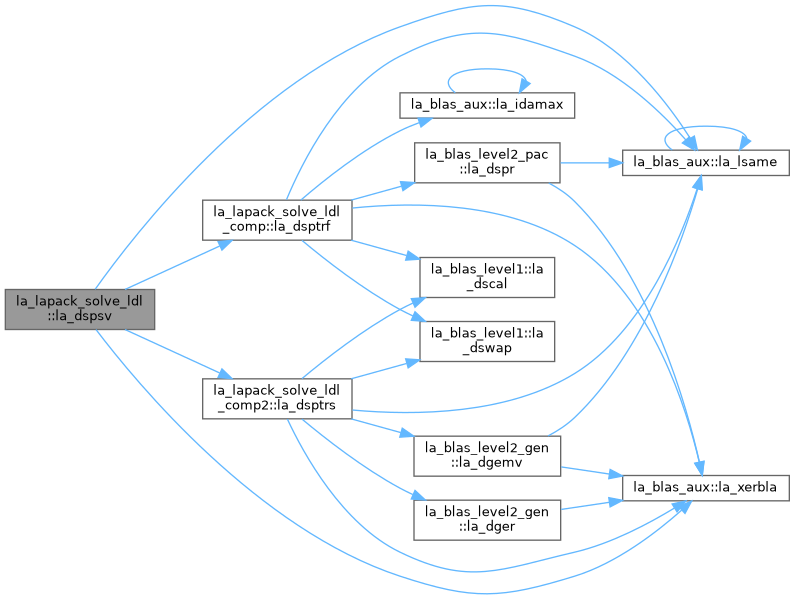
DSPSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
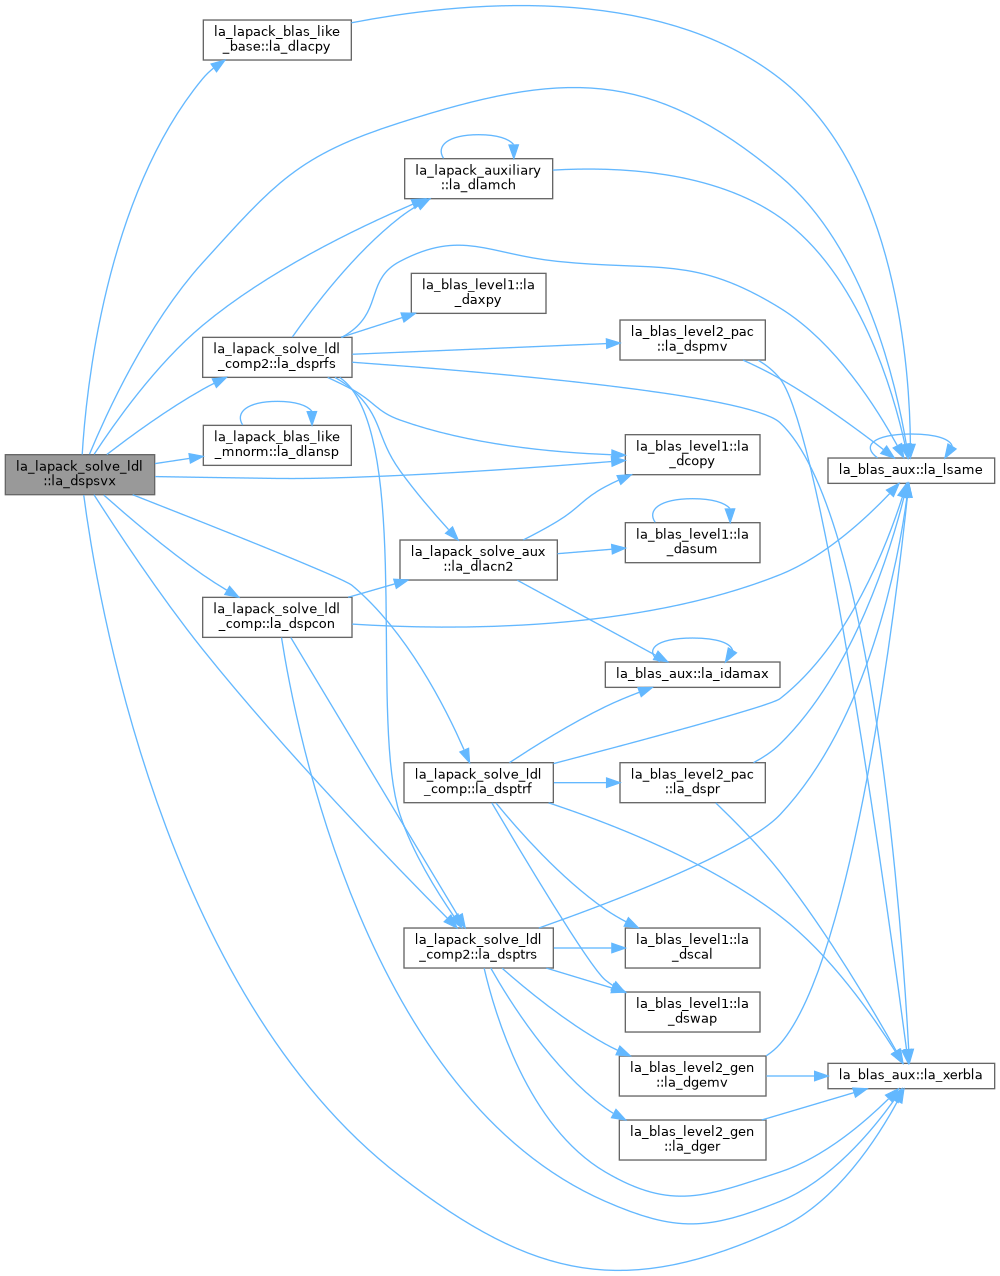
◆ la_dspsvx()
| subroutine, public la_lapack_solve_ldl::la_dspsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(*), intent(in) | ap, | ||
| real(dp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(dp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(dp), intent(out) | rcond, | ||
| real(dp), dimension(*), intent(out) | ferr, | ||
| real(dp), dimension(*), intent(out) | berr, | ||
| real(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), dimension(*), intent(out) | iwork, | ||
| integer(ilp), intent(out) | info ) |
DSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
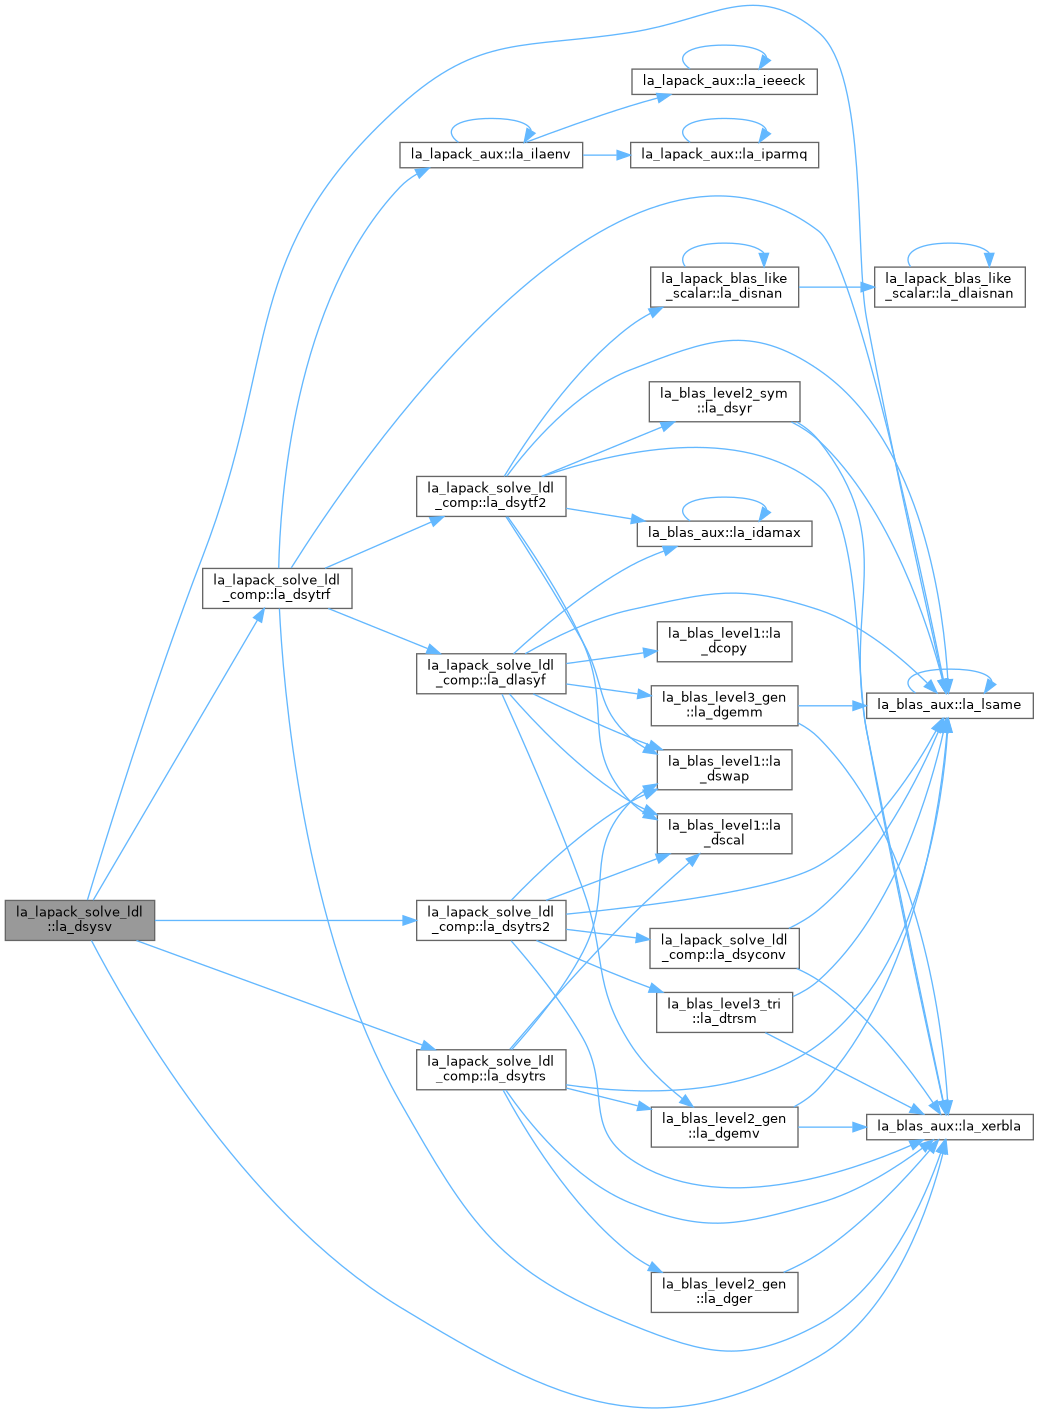
◆ la_dsysv()
| pure subroutine, public la_lapack_solve_ldl::la_dsysv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
DSYSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
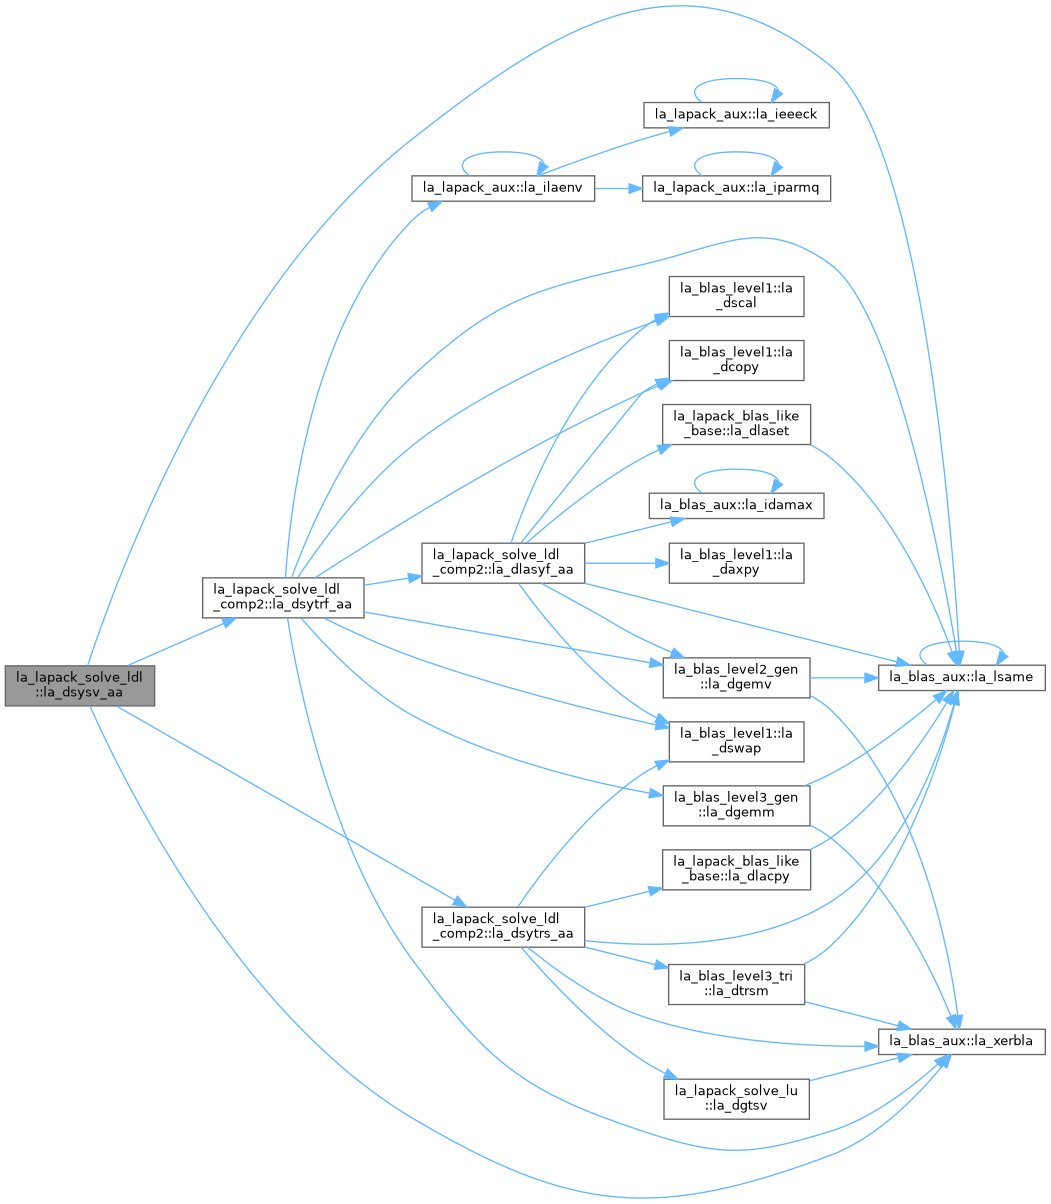
◆ la_dsysv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_dsysv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
DSYSV computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
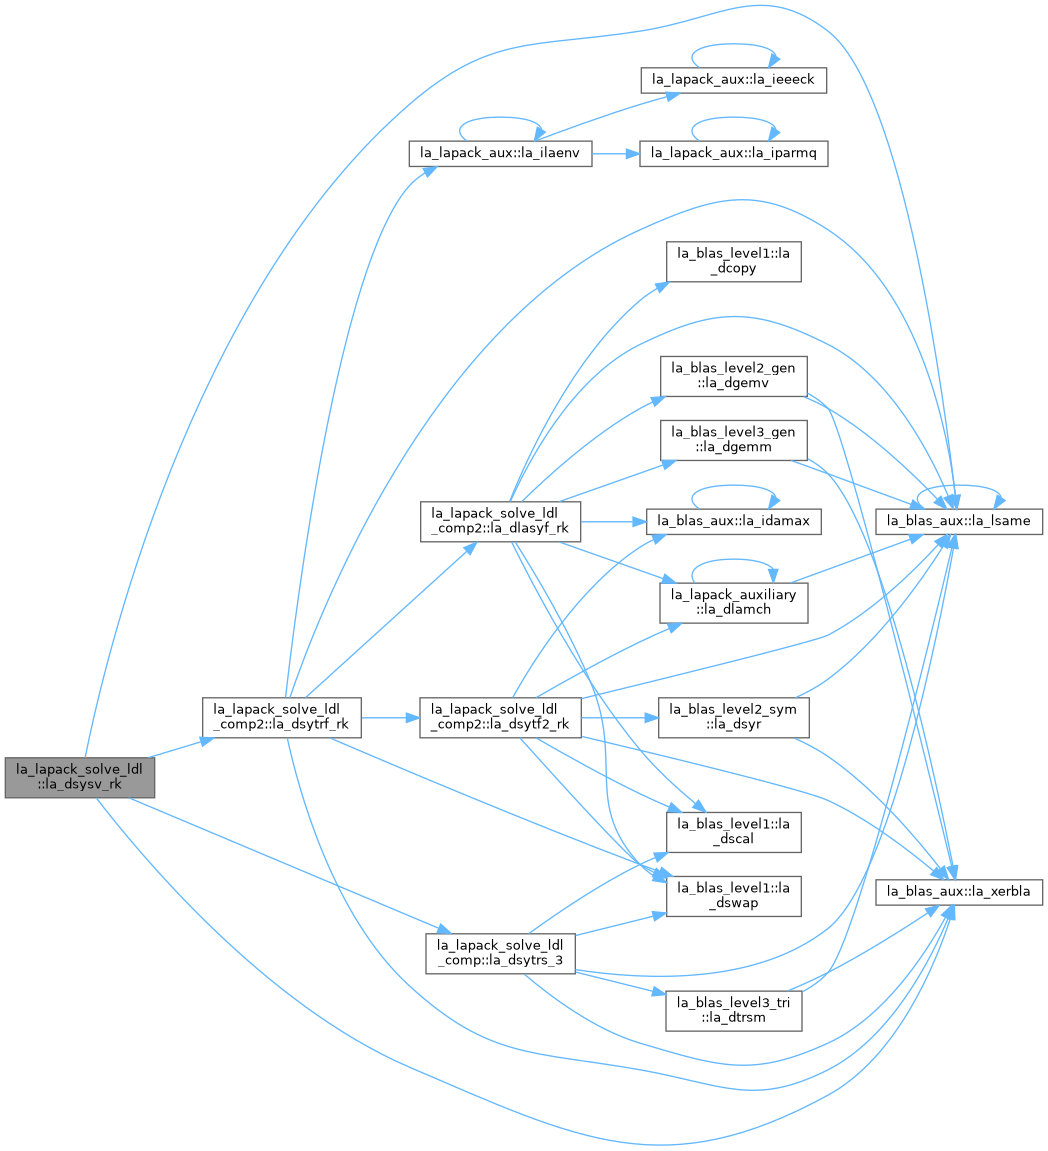
◆ la_dsysv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_dsysv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| real(dp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
DSYSV_RK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. DSYTRF_RK is called to compute the factorization of a real symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine DSYTRS_3.
◆ la_dsysv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_dsysv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
DSYSV_ROOK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. DSYTRF_ROOK is called to compute the factorization of a real symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling DSYTRS_ROOK.
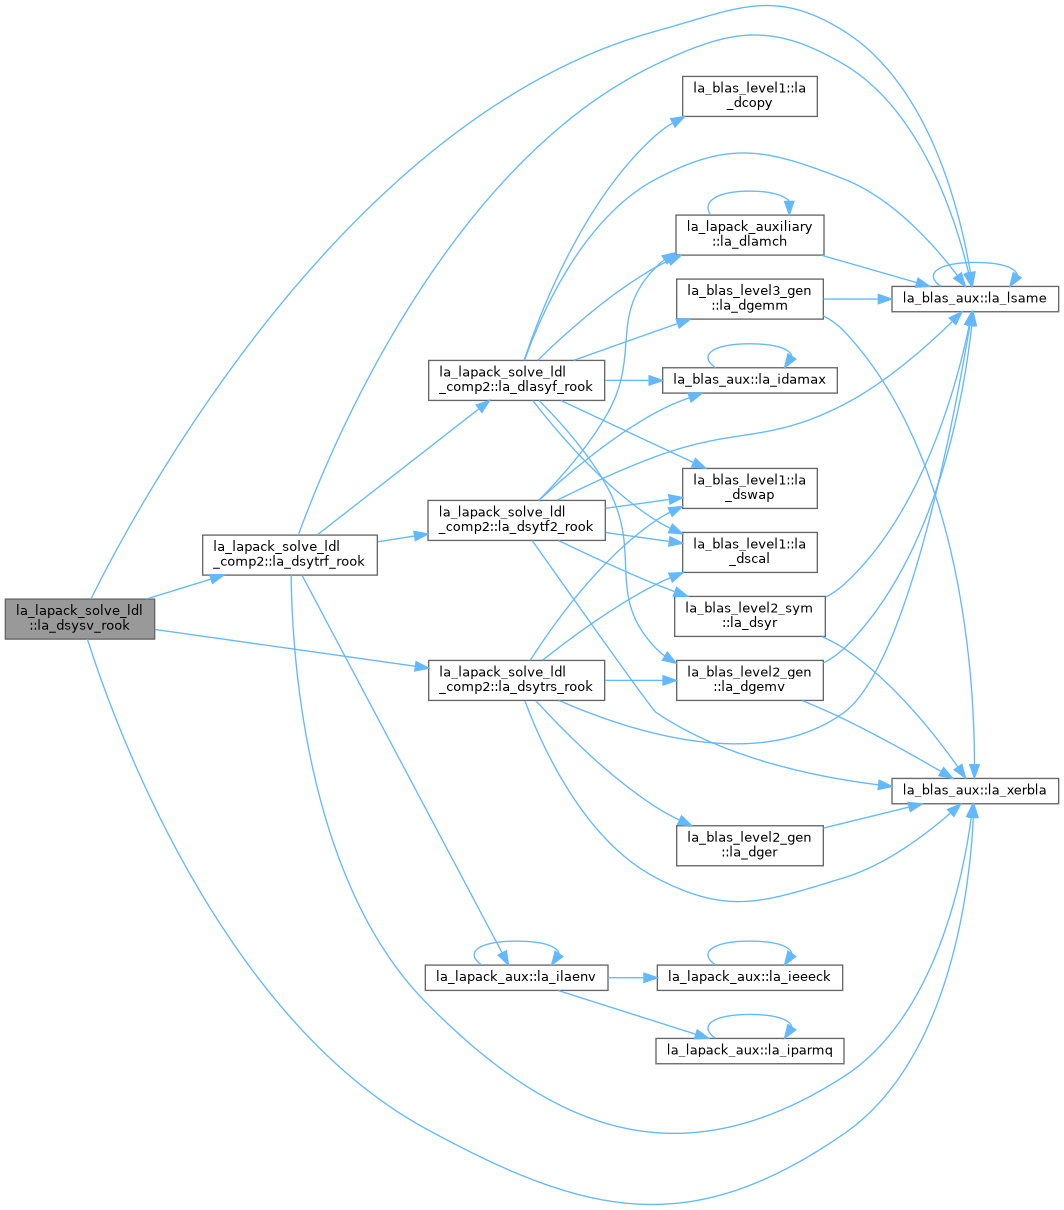
◆ la_dsysvx()
| subroutine, public la_lapack_solve_ldl::la_dsysvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(dp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| real(dp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| real(dp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(dp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(dp), intent(out) | rcond, | ||
| real(dp), dimension(*), intent(out) | ferr, | ||
| real(dp), dimension(*), intent(out) | berr, | ||
| real(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), dimension(*), intent(out) | iwork, | ||
| integer(ilp), intent(out) | info ) |
DSYSVX: uses the diagonal pivoting factorization to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
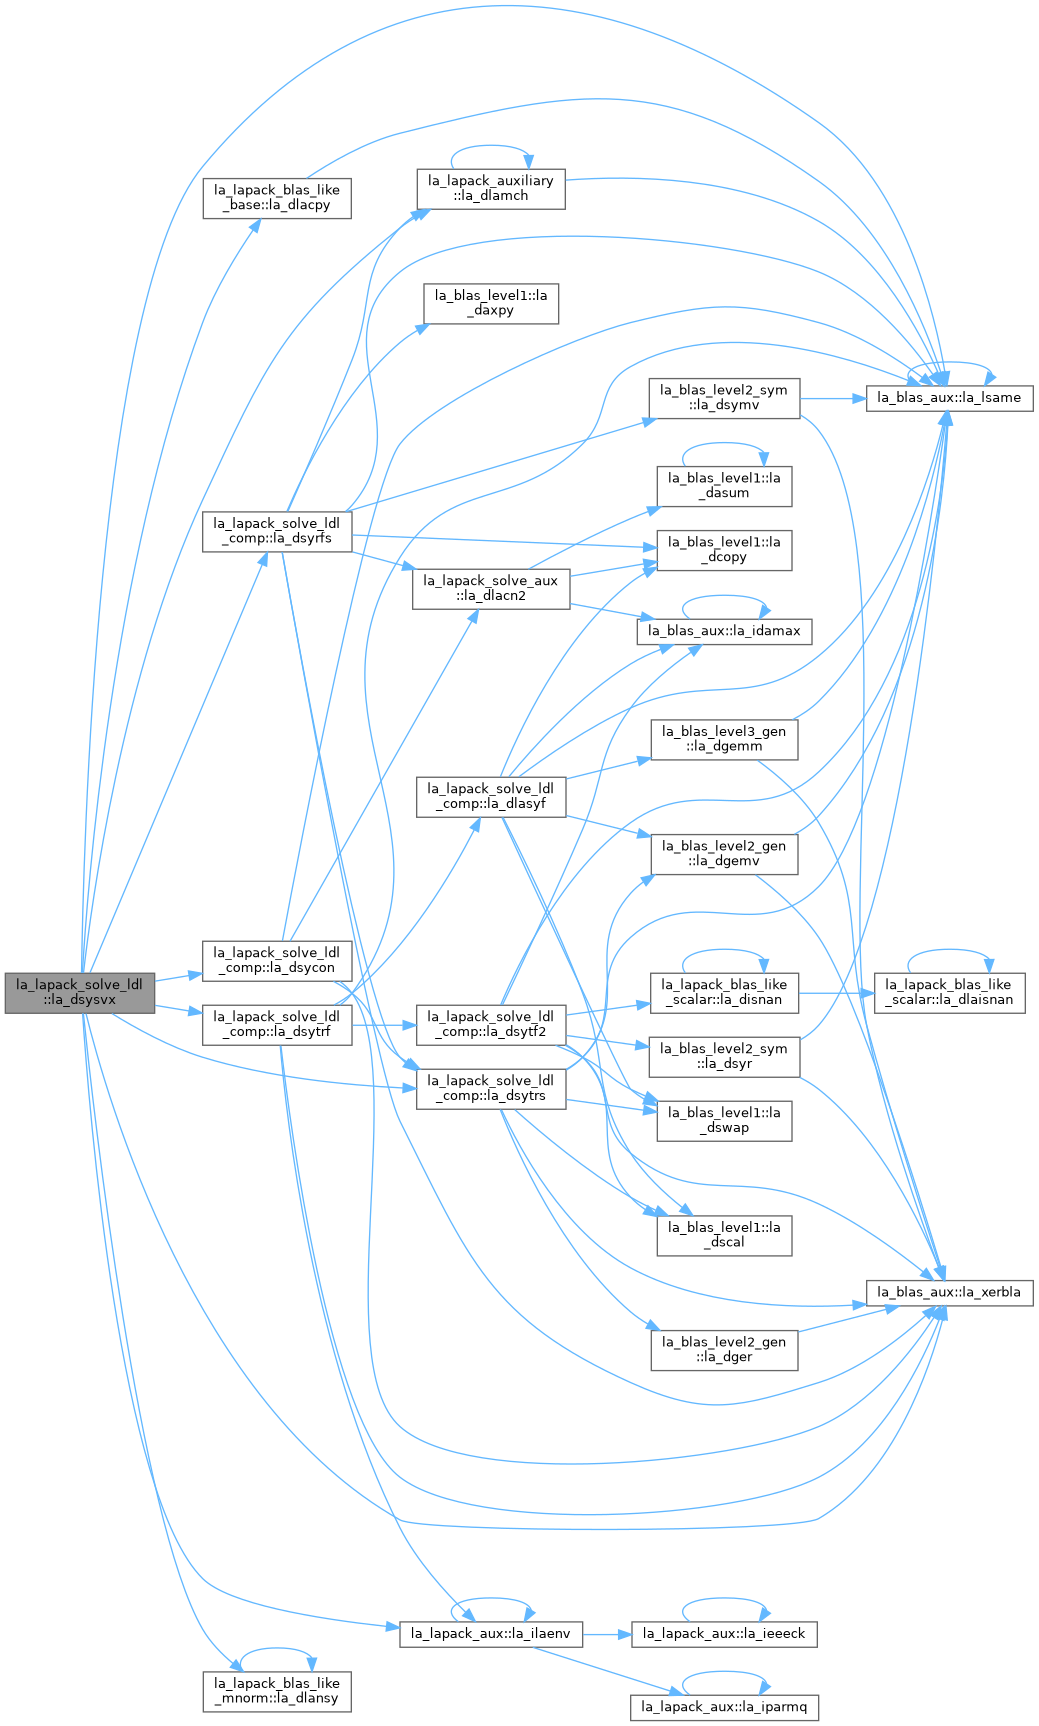
◆ la_qspsv()
| pure subroutine, public la_lapack_solve_ldl::la_qspsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
QSPSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
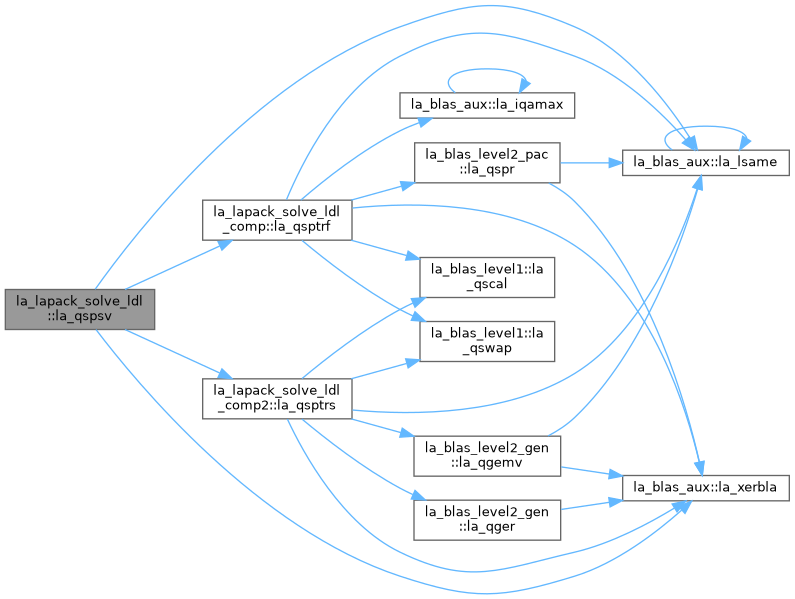
◆ la_qspsvx()
| subroutine, public la_lapack_solve_ldl::la_qspsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(*), intent(in) | ap, | ||
| real(qp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(qp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(qp), intent(out) | rcond, | ||
| real(qp), dimension(*), intent(out) | ferr, | ||
| real(qp), dimension(*), intent(out) | berr, | ||
| real(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), dimension(*), intent(out) | iwork, | ||
| integer(ilp), intent(out) | info ) |
QSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
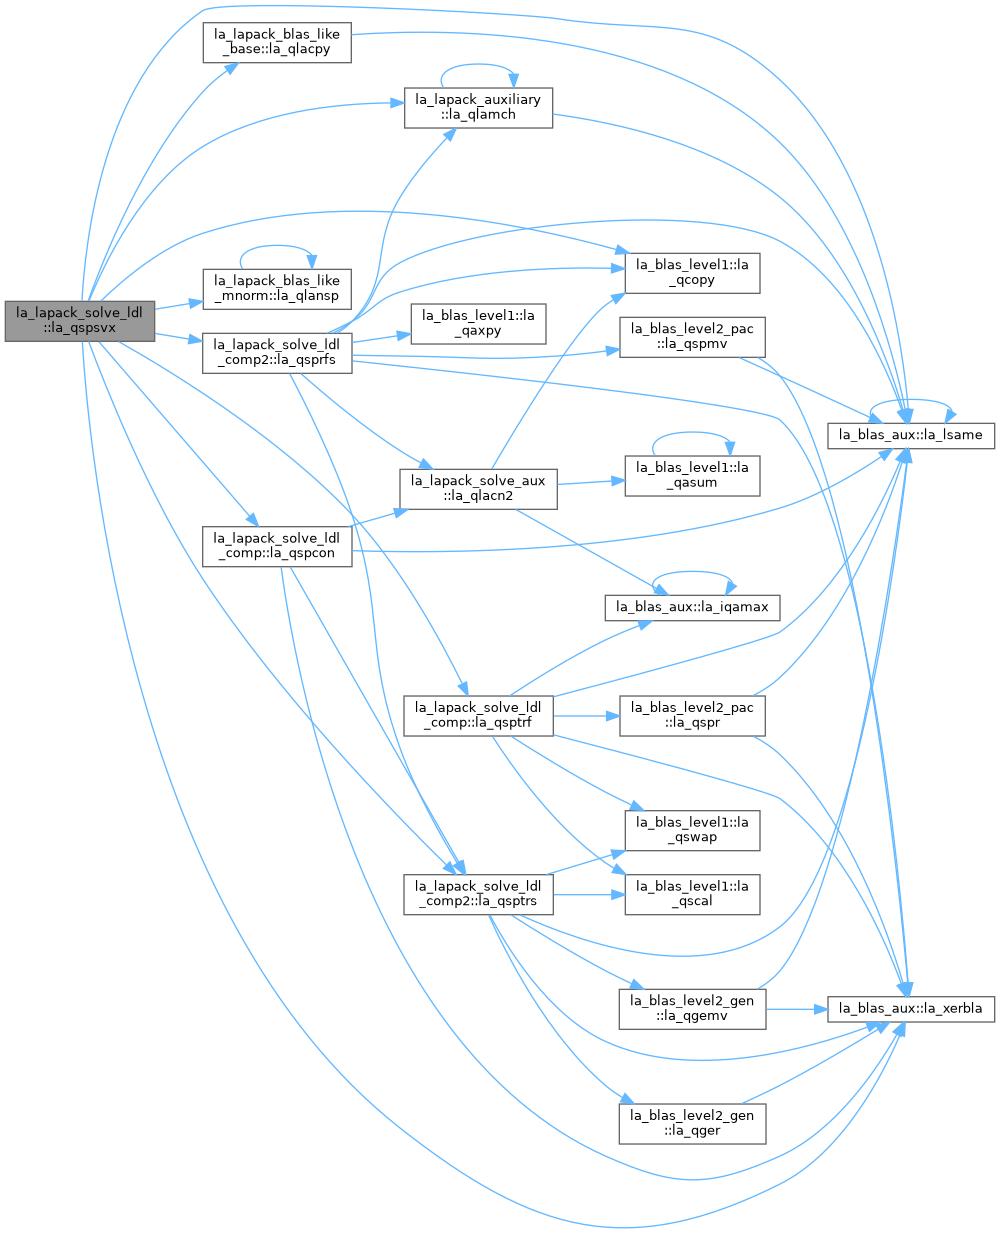
◆ la_qsysv()
| pure subroutine, public la_lapack_solve_ldl::la_qsysv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
QSYSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
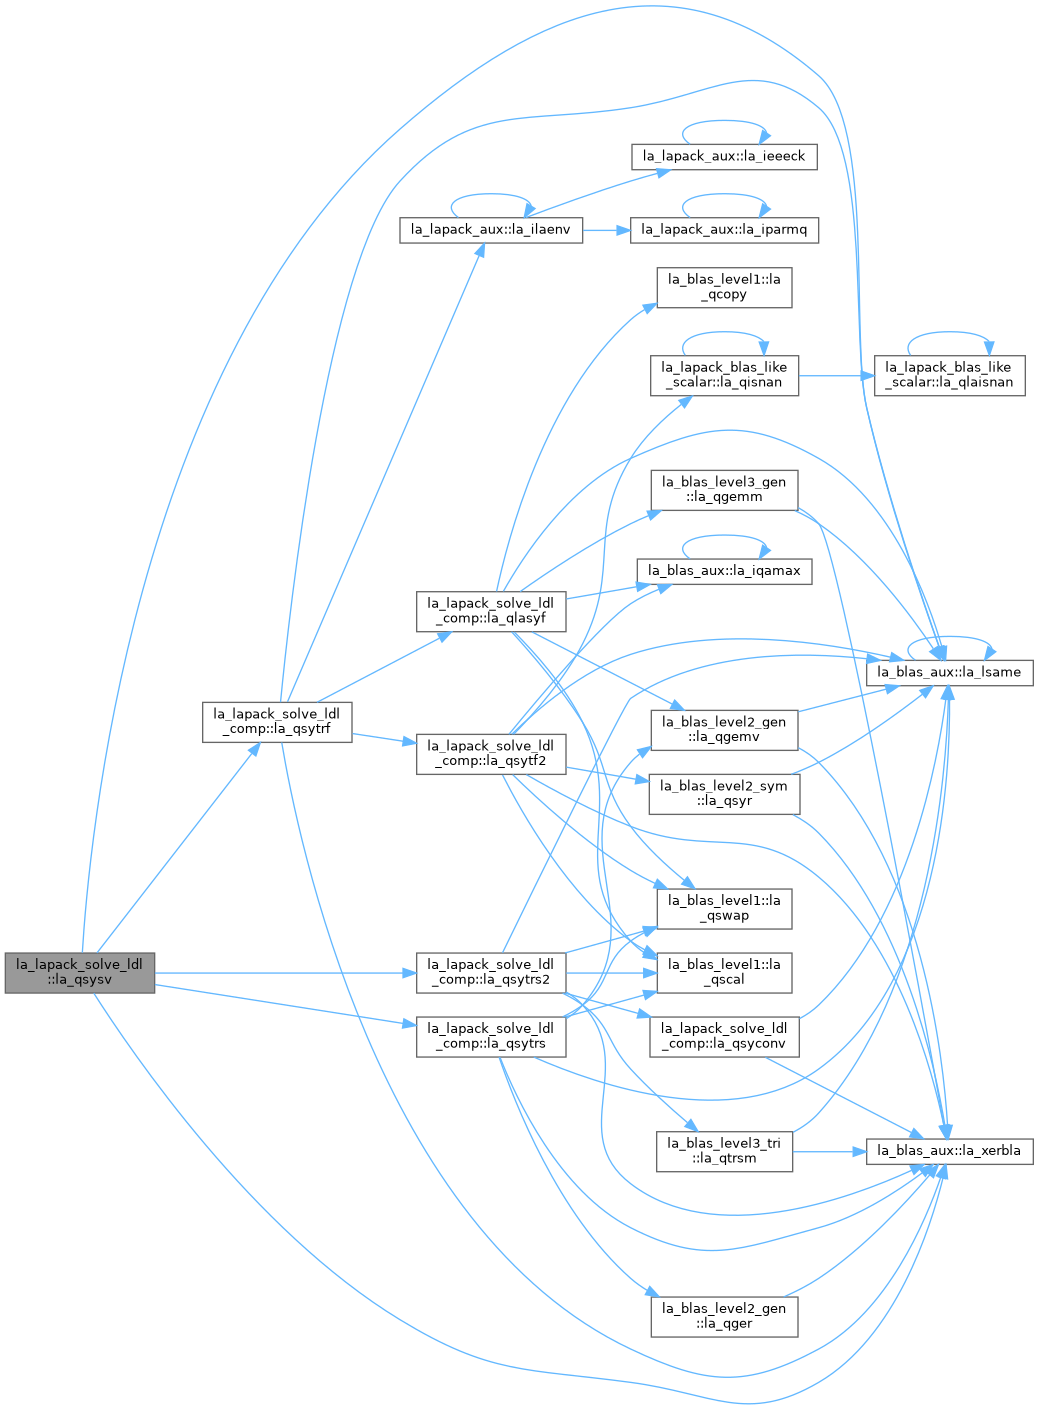
◆ la_qsysv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_qsysv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
QSYSV computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
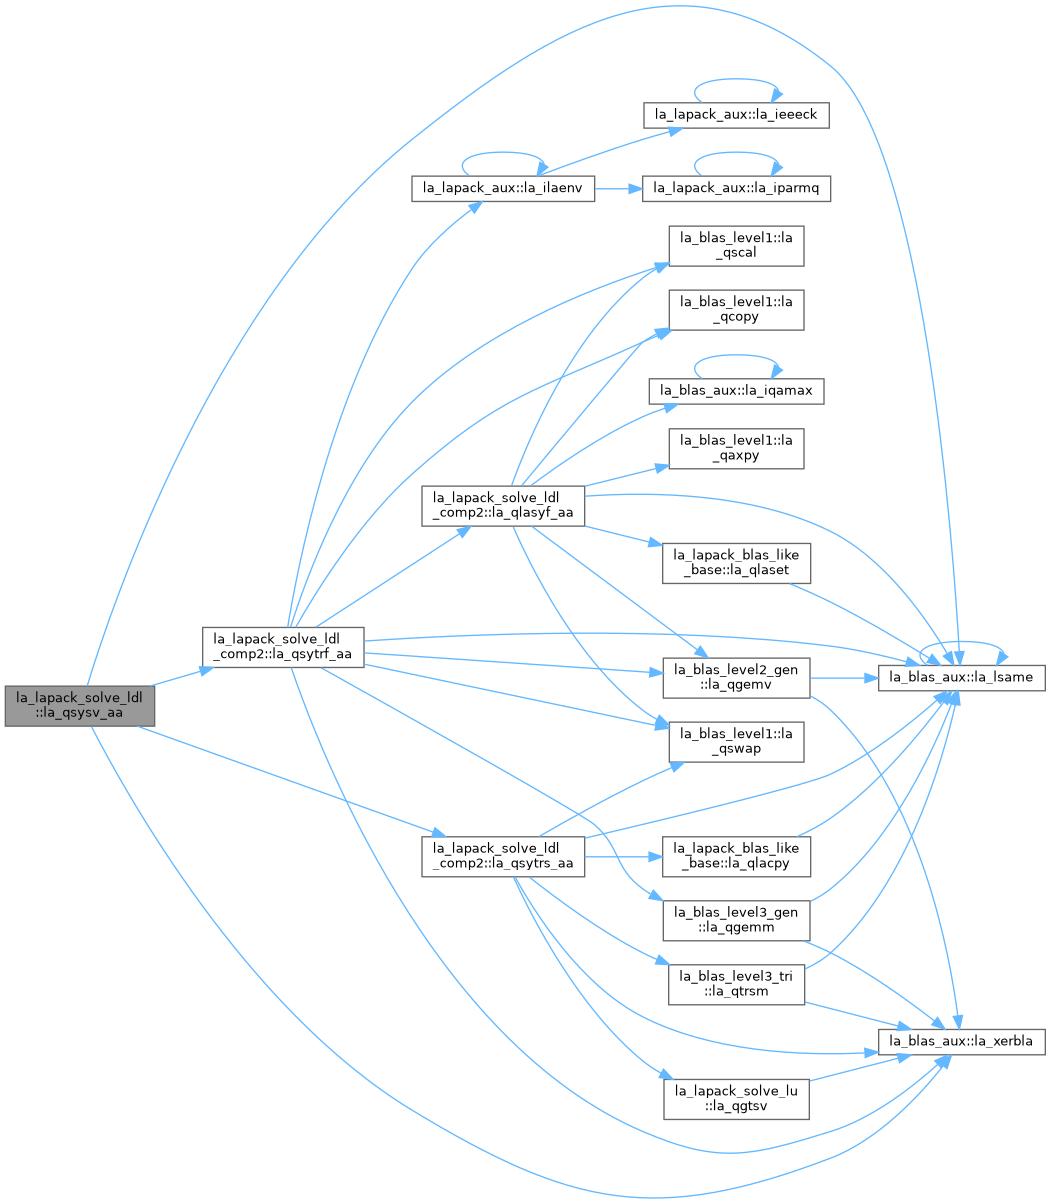
◆ la_qsysv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_qsysv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| real(qp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
QSYSV_RK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. QSYTRF_RK is called to compute the factorization of a real symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine QSYTRS_3.
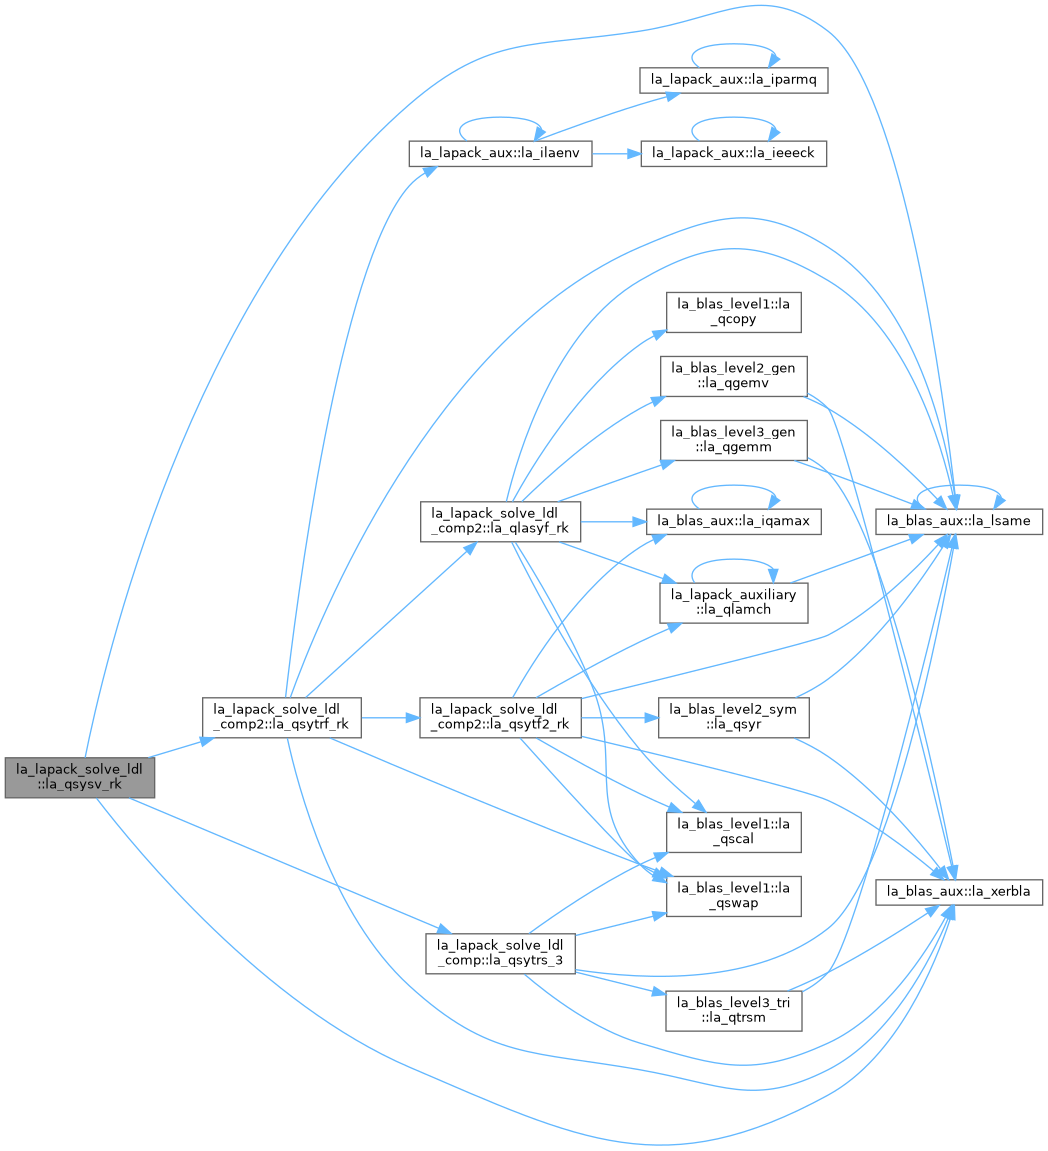
◆ la_qsysv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_qsysv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
QSYSV_ROOK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. QSYTRF_ROOK is called to compute the factorization of a real symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling QSYTRS_ROOK.
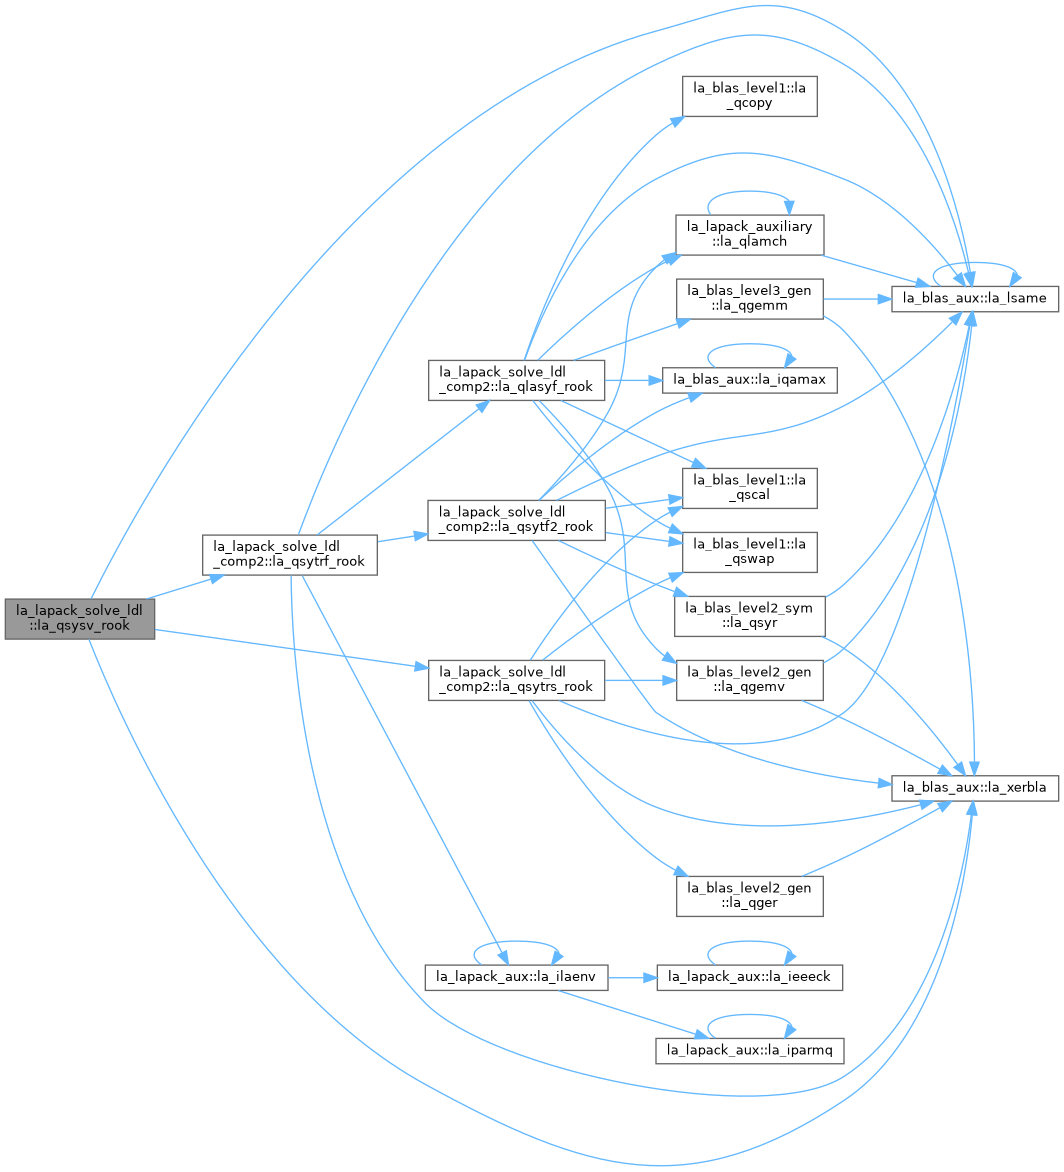
◆ la_qsysvx()
| subroutine, public la_lapack_solve_ldl::la_qsysvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(qp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| real(qp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| real(qp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(qp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(qp), intent(out) | rcond, | ||
| real(qp), dimension(*), intent(out) | ferr, | ||
| real(qp), dimension(*), intent(out) | berr, | ||
| real(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), dimension(*), intent(out) | iwork, | ||
| integer(ilp), intent(out) | info ) |
QSYSVX: uses the diagonal pivoting factorization to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
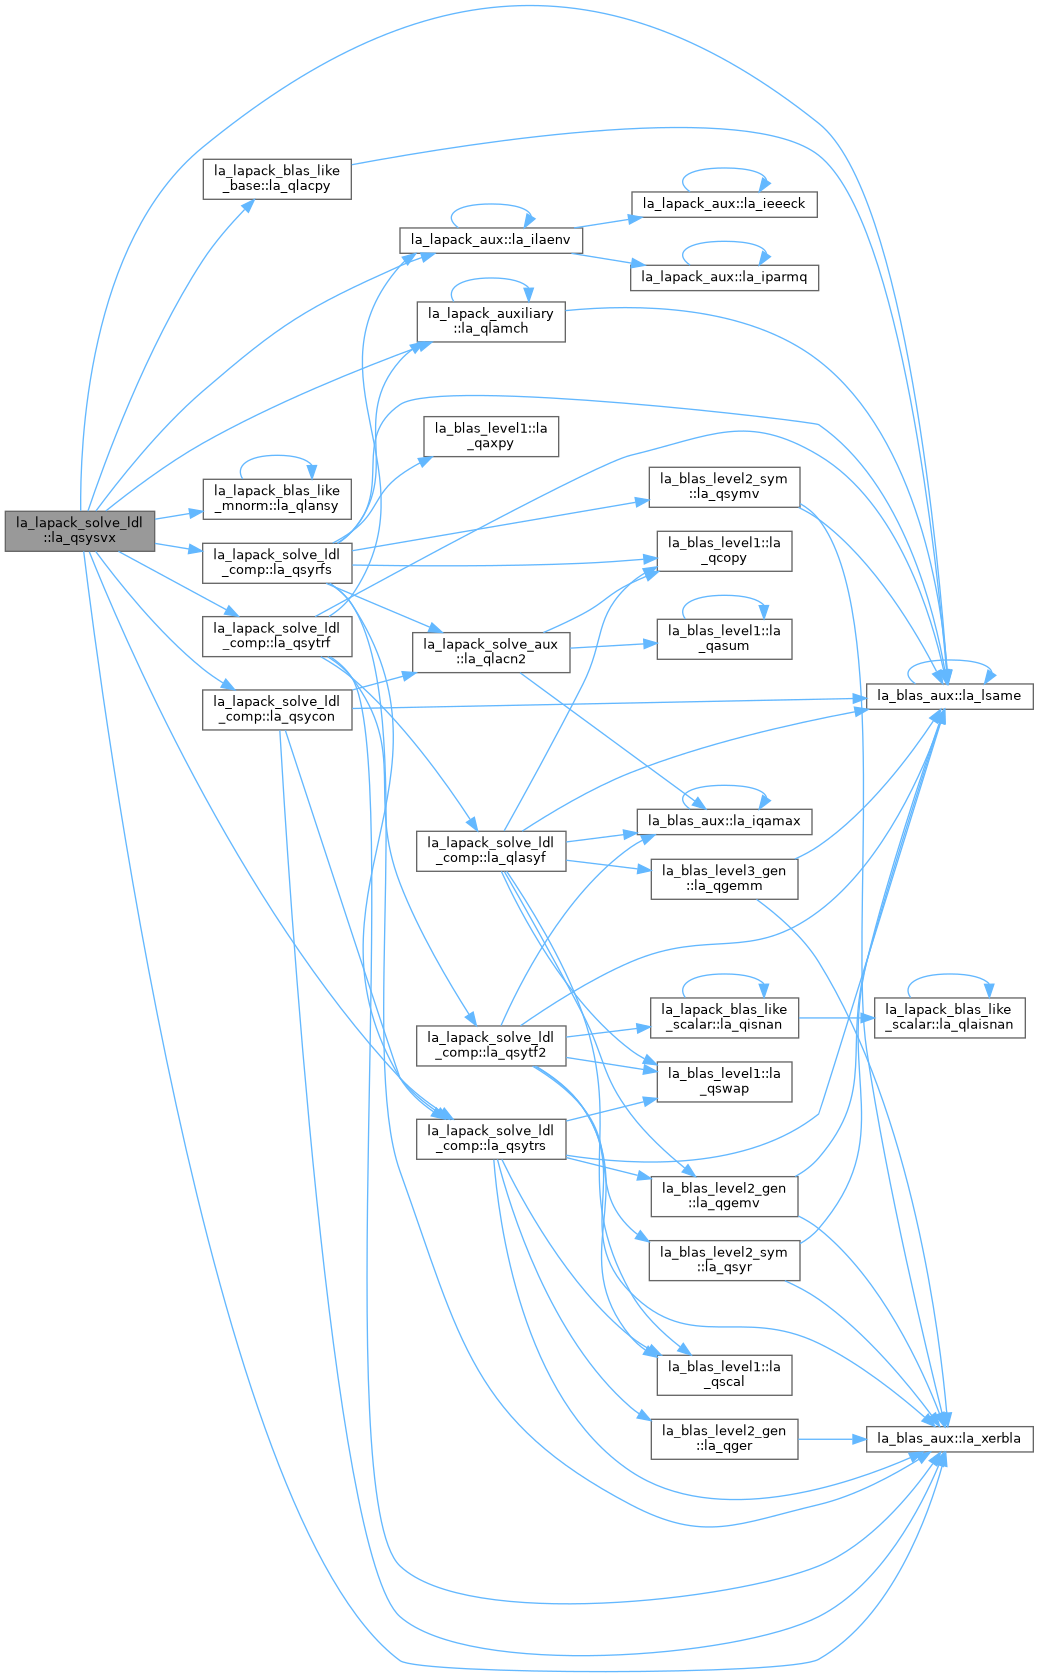
◆ la_sspsv()
| pure subroutine, public la_lapack_solve_ldl::la_sspsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
SSPSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
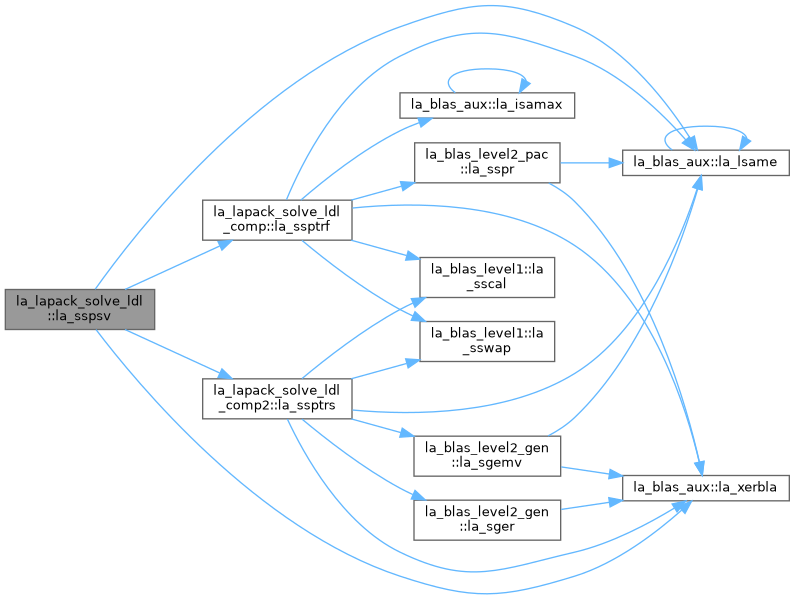
◆ la_sspsvx()
| subroutine, public la_lapack_solve_ldl::la_sspsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(*), intent(in) | ap, | ||
| real(sp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(sp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(sp), intent(out) | rcond, | ||
| real(sp), dimension(*), intent(out) | ferr, | ||
| real(sp), dimension(*), intent(out) | berr, | ||
| real(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), dimension(*), intent(out) | iwork, | ||
| integer(ilp), intent(out) | info ) |
SSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
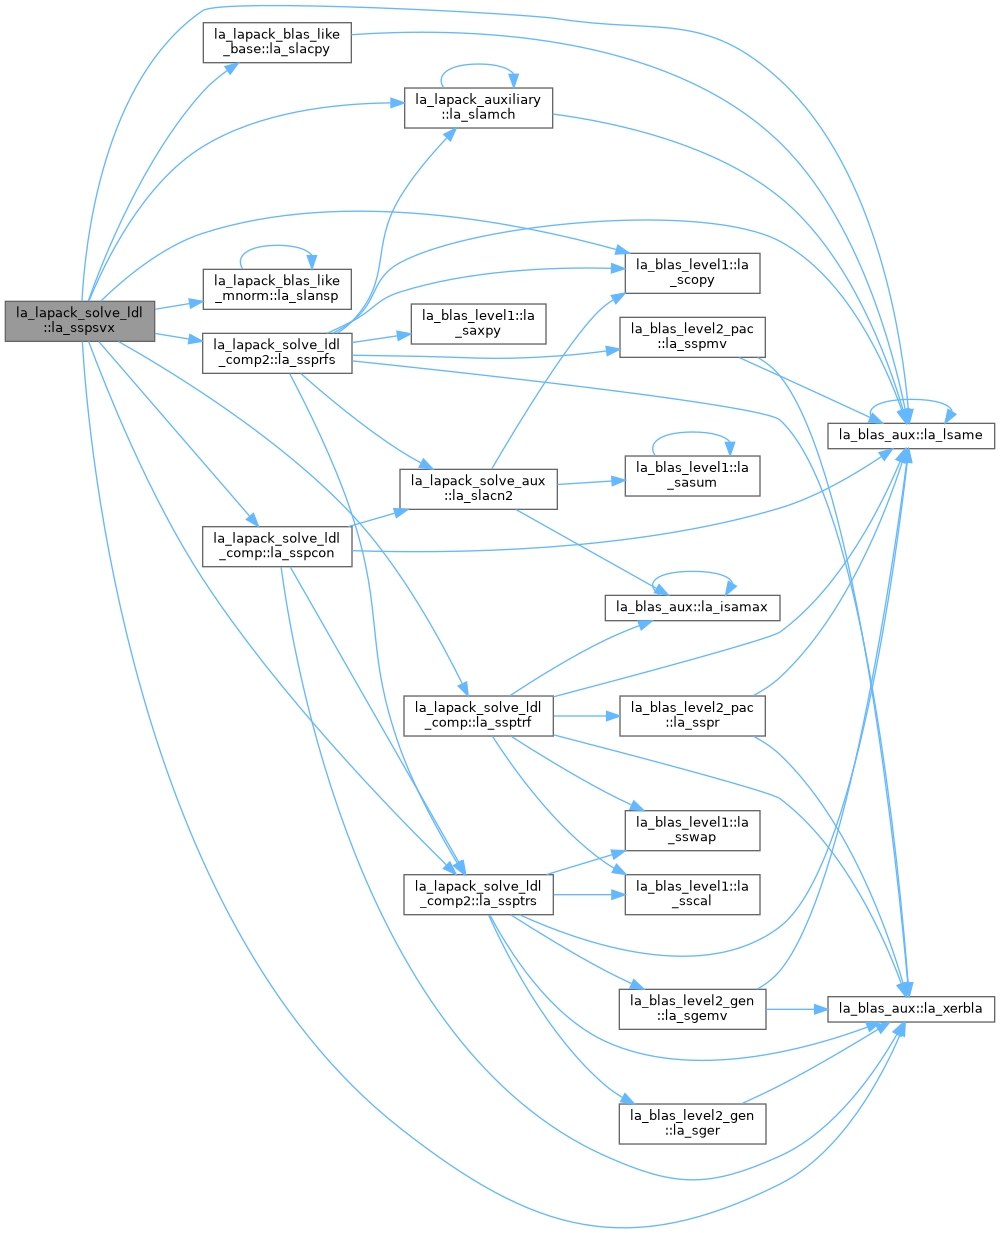
◆ la_ssysv()
| pure subroutine, public la_lapack_solve_ldl::la_ssysv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
SSYSV: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
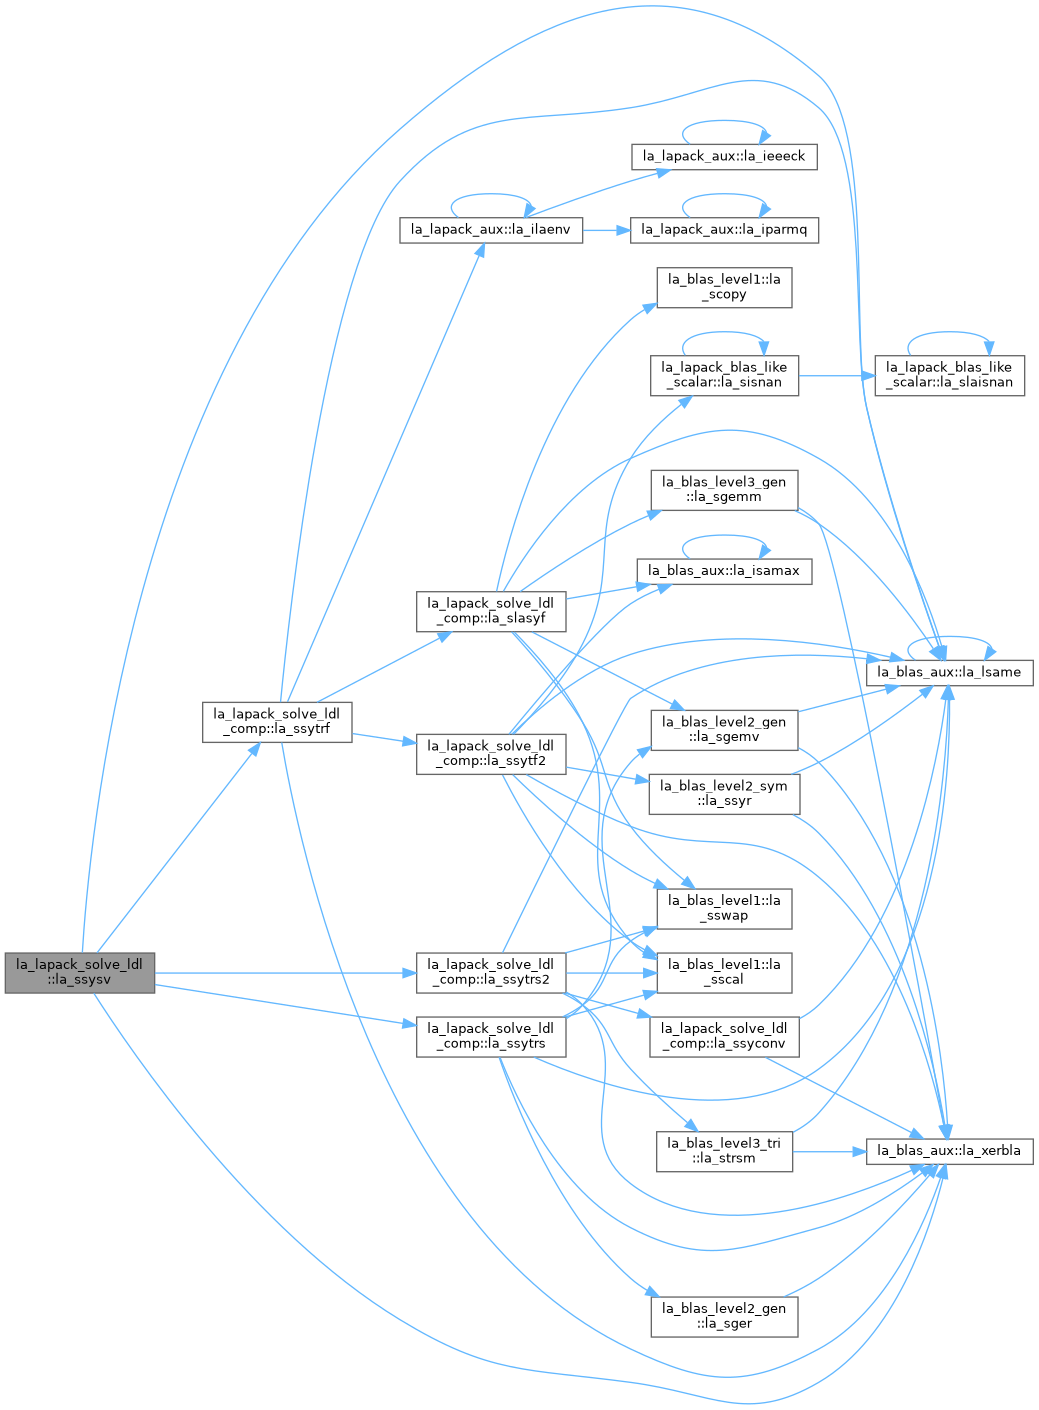
◆ la_ssysv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_ssysv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
SSYSV computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_ssysv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_ssysv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| real(sp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
SSYSV_RK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. SSYTRF_RK is called to compute the factorization of a real symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine SSYTRS_3.
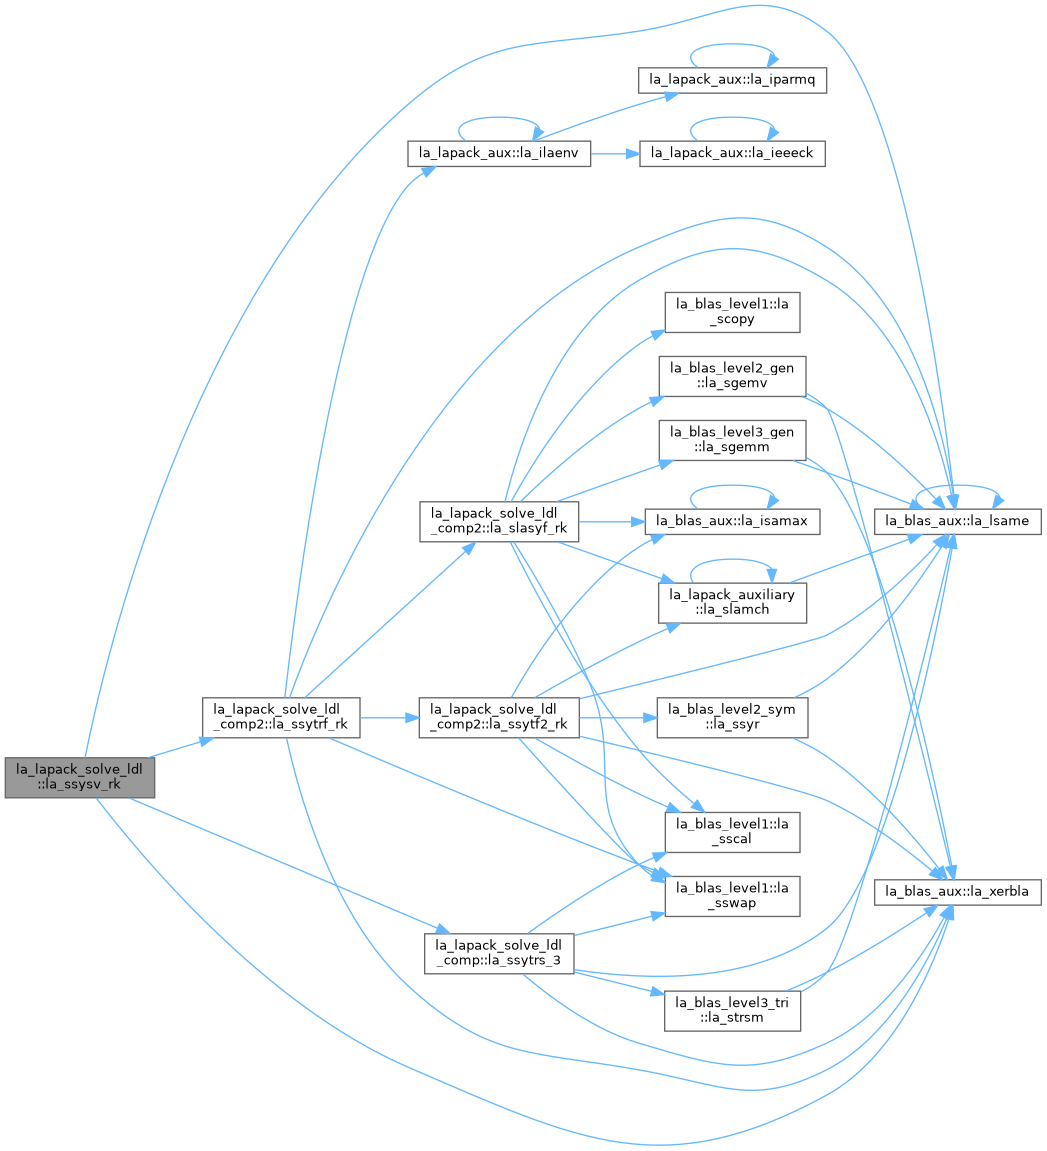
◆ la_ssysv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_ssysv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
SSYSV_ROOK: computes the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. SSYTRF_ROOK is called to compute the factorization of a real symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling SSYTRS_ROOK.
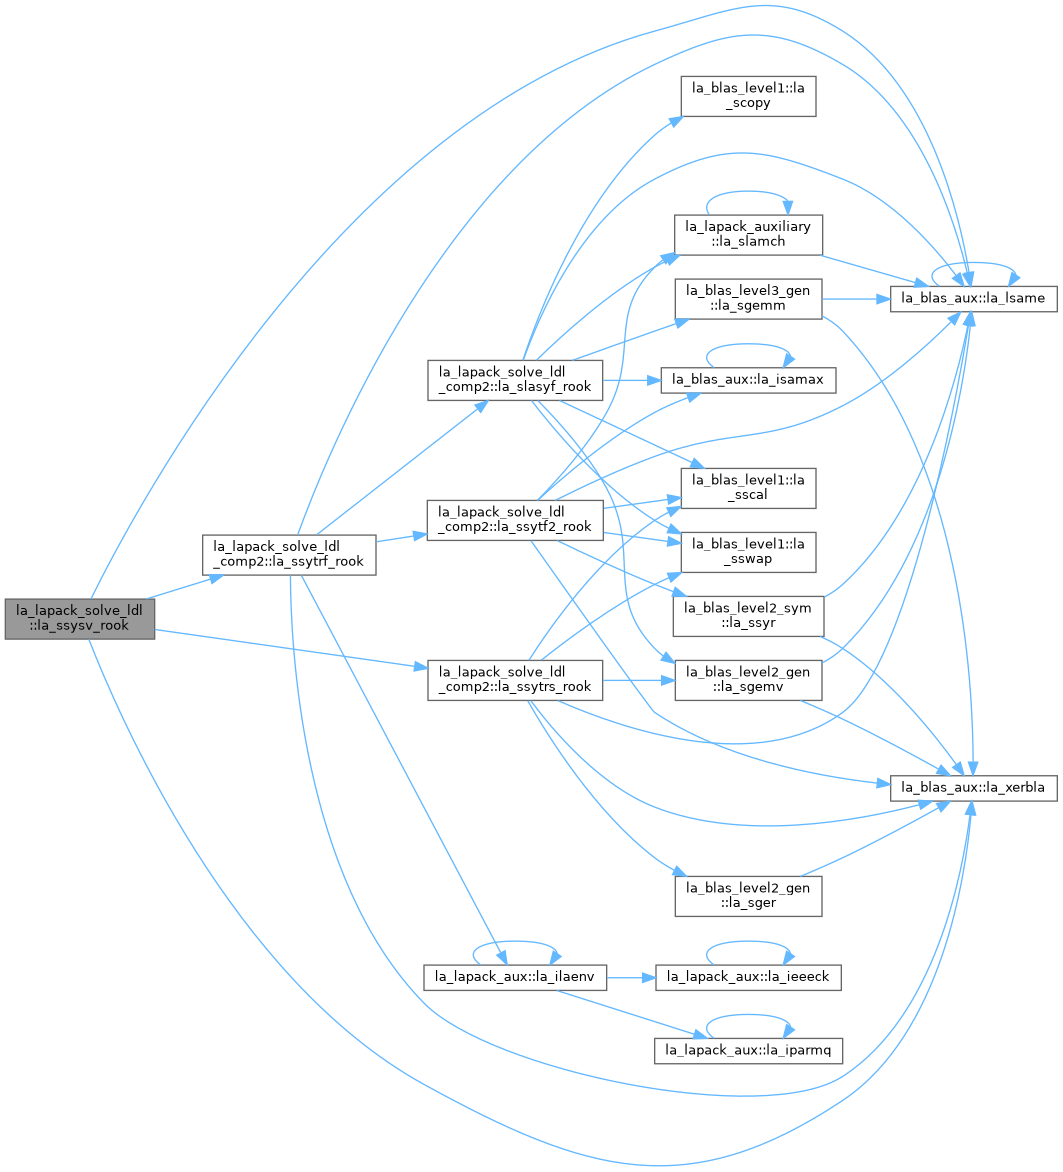
◆ la_ssysvx()
| subroutine, public la_lapack_solve_ldl::la_ssysvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| real(sp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| real(sp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| real(sp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| real(sp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(sp), intent(out) | rcond, | ||
| real(sp), dimension(*), intent(out) | ferr, | ||
| real(sp), dimension(*), intent(out) | berr, | ||
| real(sp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), dimension(*), intent(out) | iwork, | ||
| integer(ilp), intent(out) | info ) |
SSYSVX: uses the diagonal pivoting factorization to compute the solution to a real system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
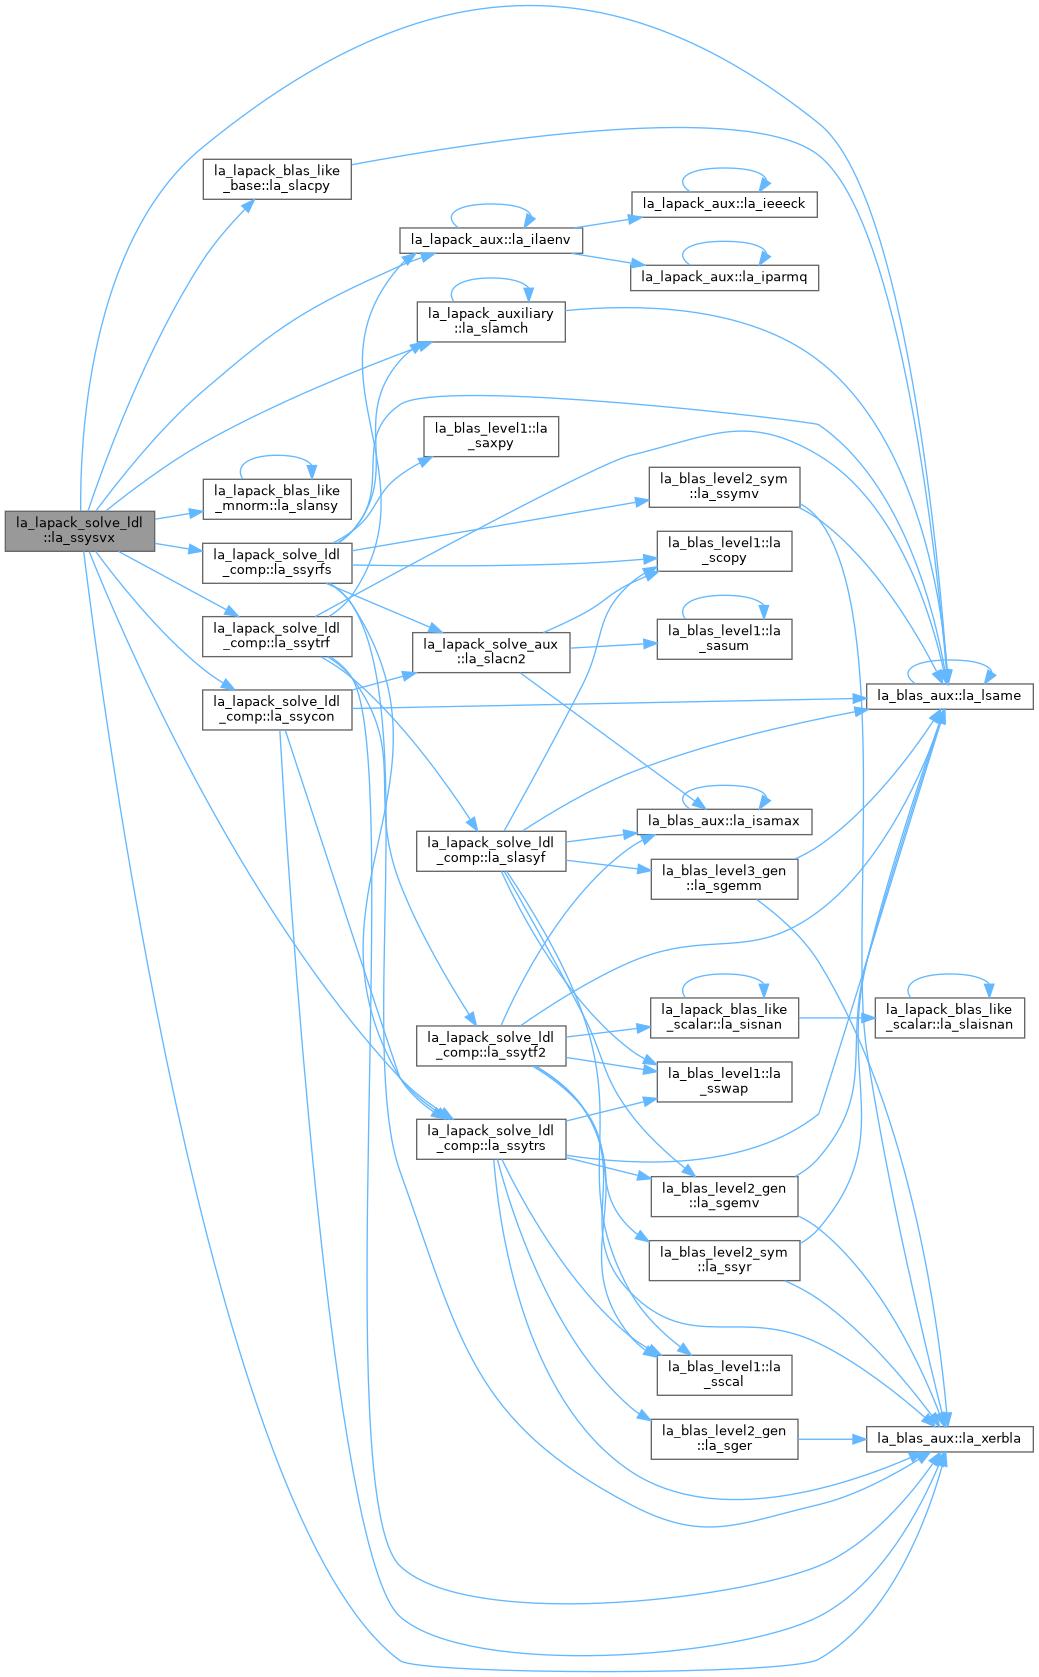
◆ la_whesv()
| pure subroutine, public la_lapack_solve_ldl::la_whesv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WHESV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
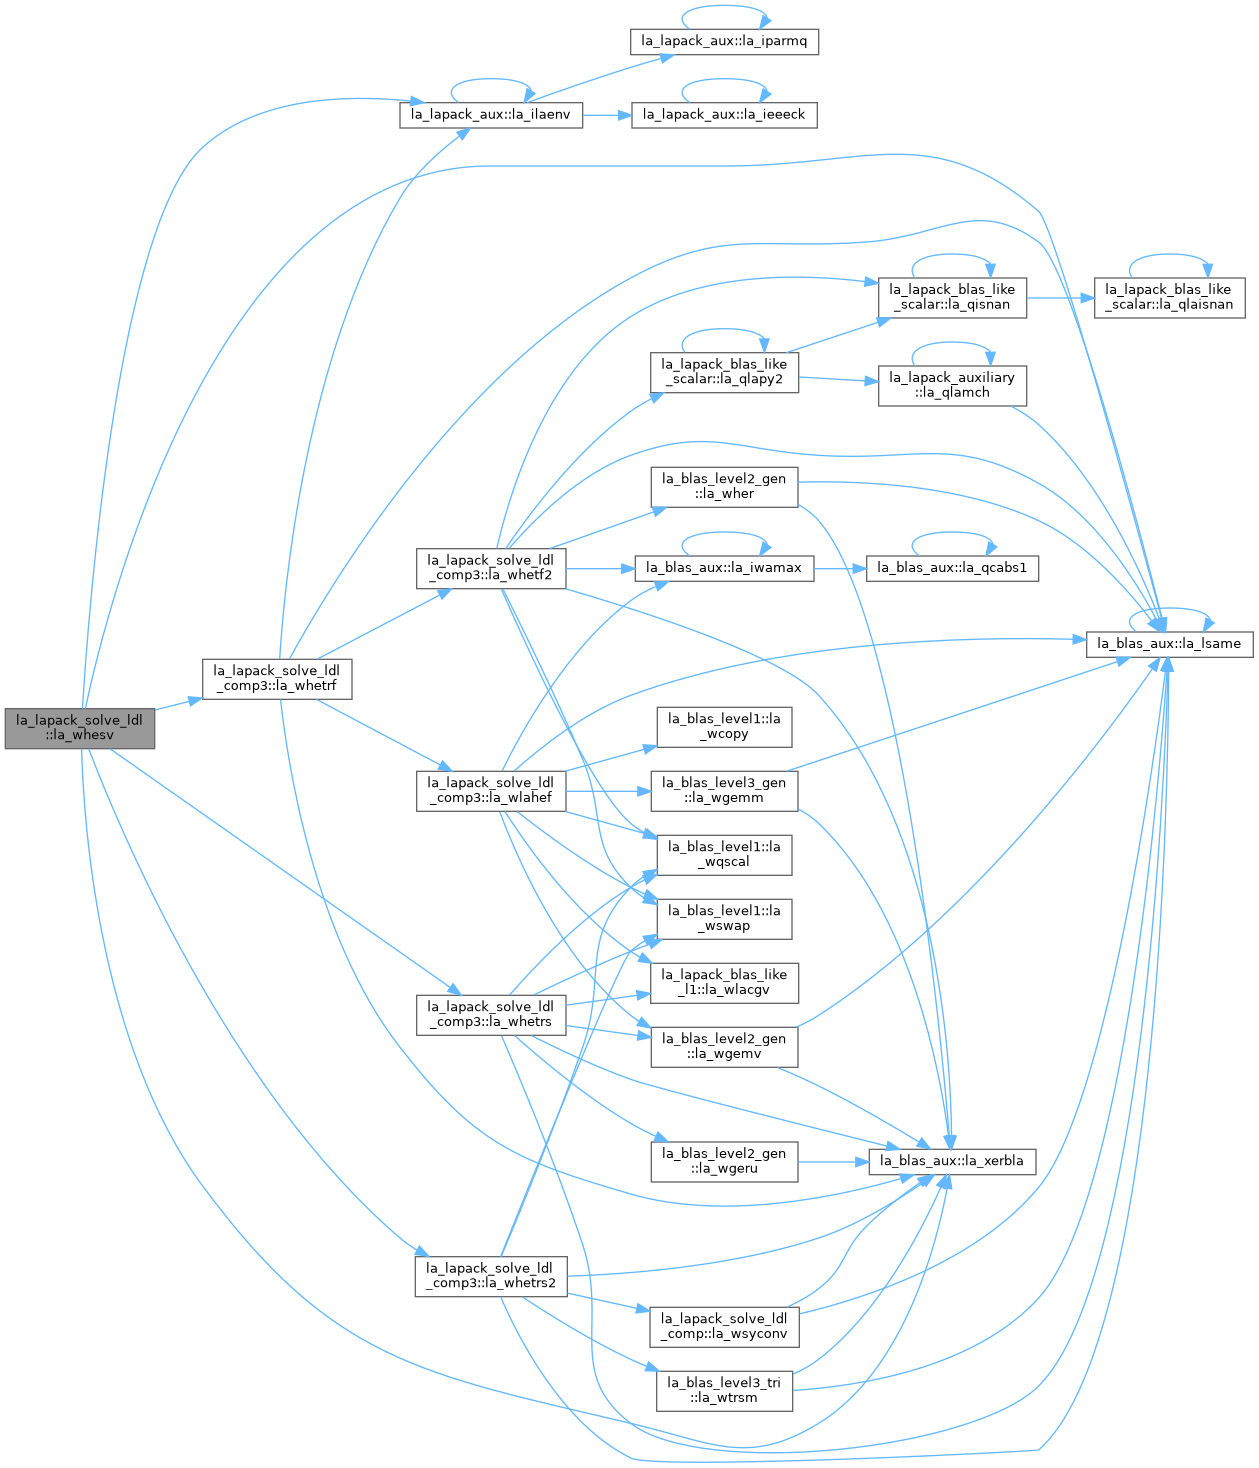
◆ la_whesv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_whesv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WHESV_AA: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**H * T * U, if UPLO = 'U', or A = L * T * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is Hermitian and tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
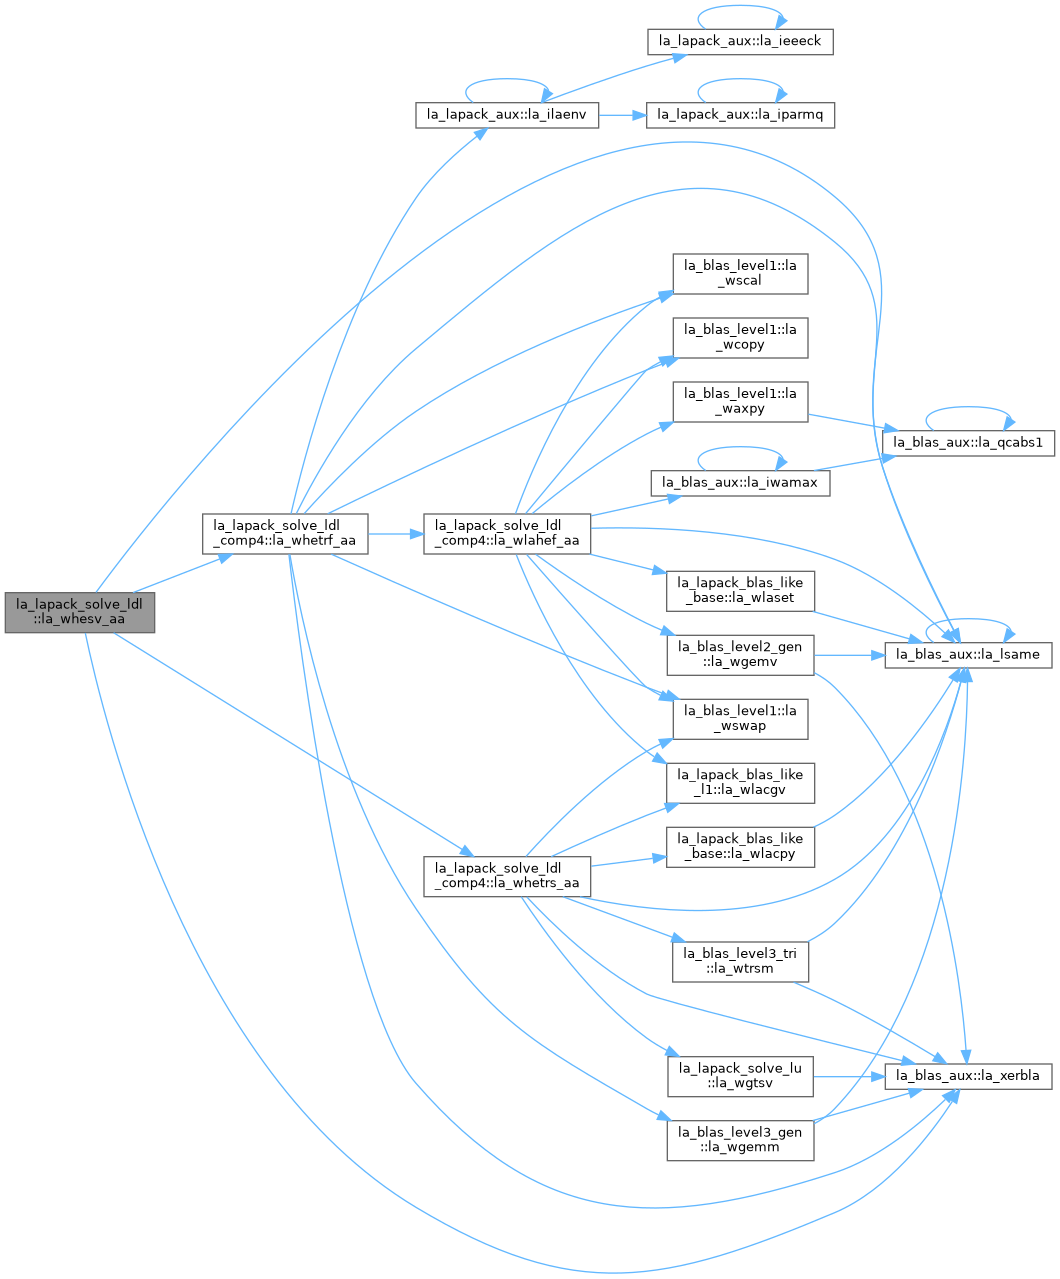
◆ la_whesv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_whesv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(qp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WHESV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**H)*(P**T), if UPLO = 'U', or A = P*L*D*(L**H)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**H (or L**H) is the conjugate of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WHETRF_RK is called to compute the factorization of a complex Hermitian matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine WHETRS_3.
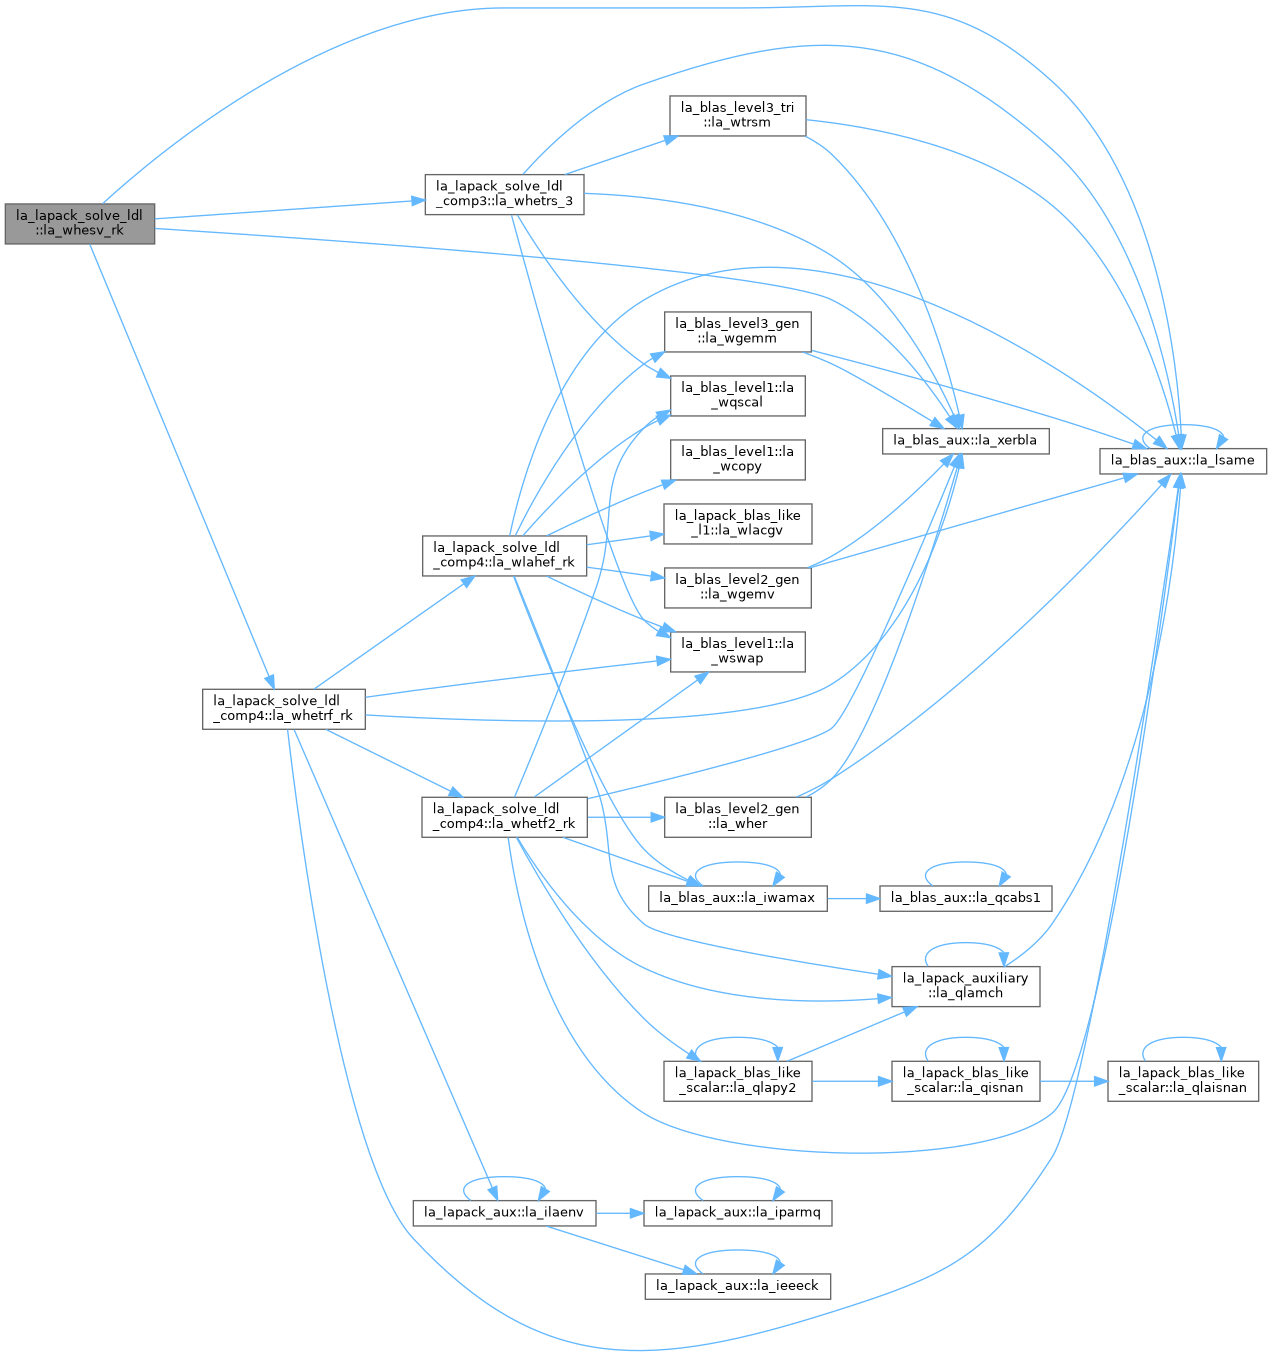
◆ la_whesv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_whesv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WHESV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman ("rook") diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WHETRF_ROOK is called to compute the factorization of a complex Hermition matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling WHETRS_ROOK (uses BLAS 2).
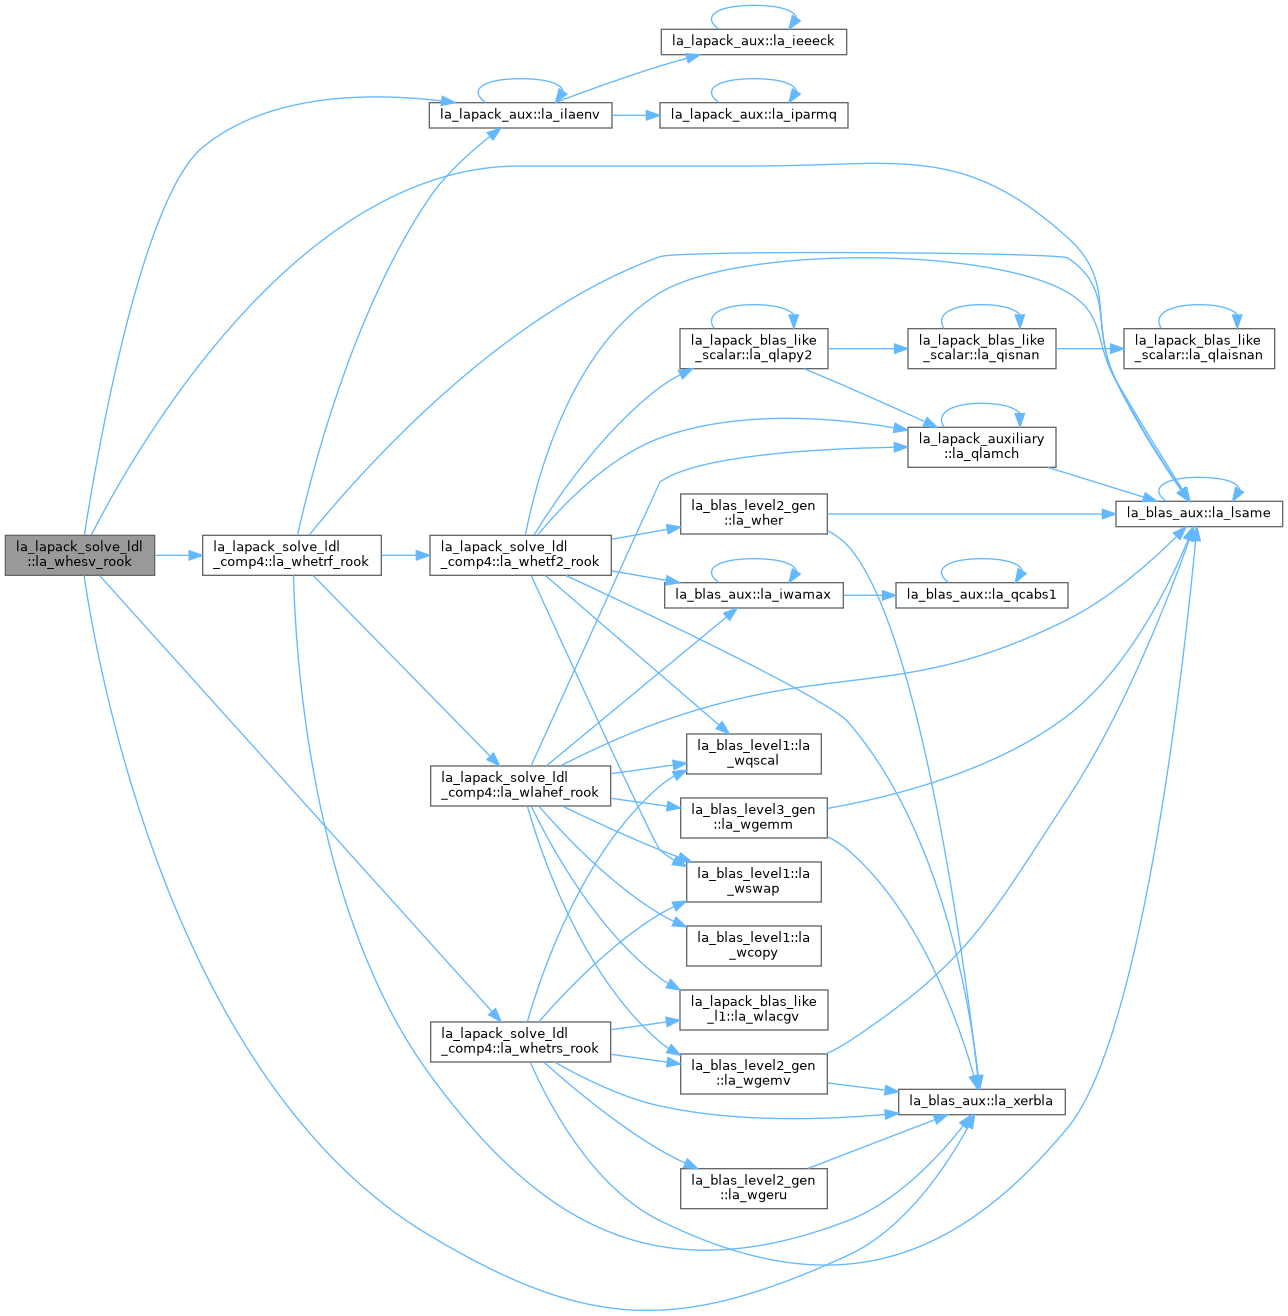
◆ la_whesvx()
| subroutine, public la_lapack_solve_ldl::la_whesvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(qp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(qp), intent(out) | rcond, | ||
| real(qp), dimension(*), intent(out) | ferr, | ||
| real(qp), dimension(*), intent(out) | berr, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| real(qp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
WHESVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
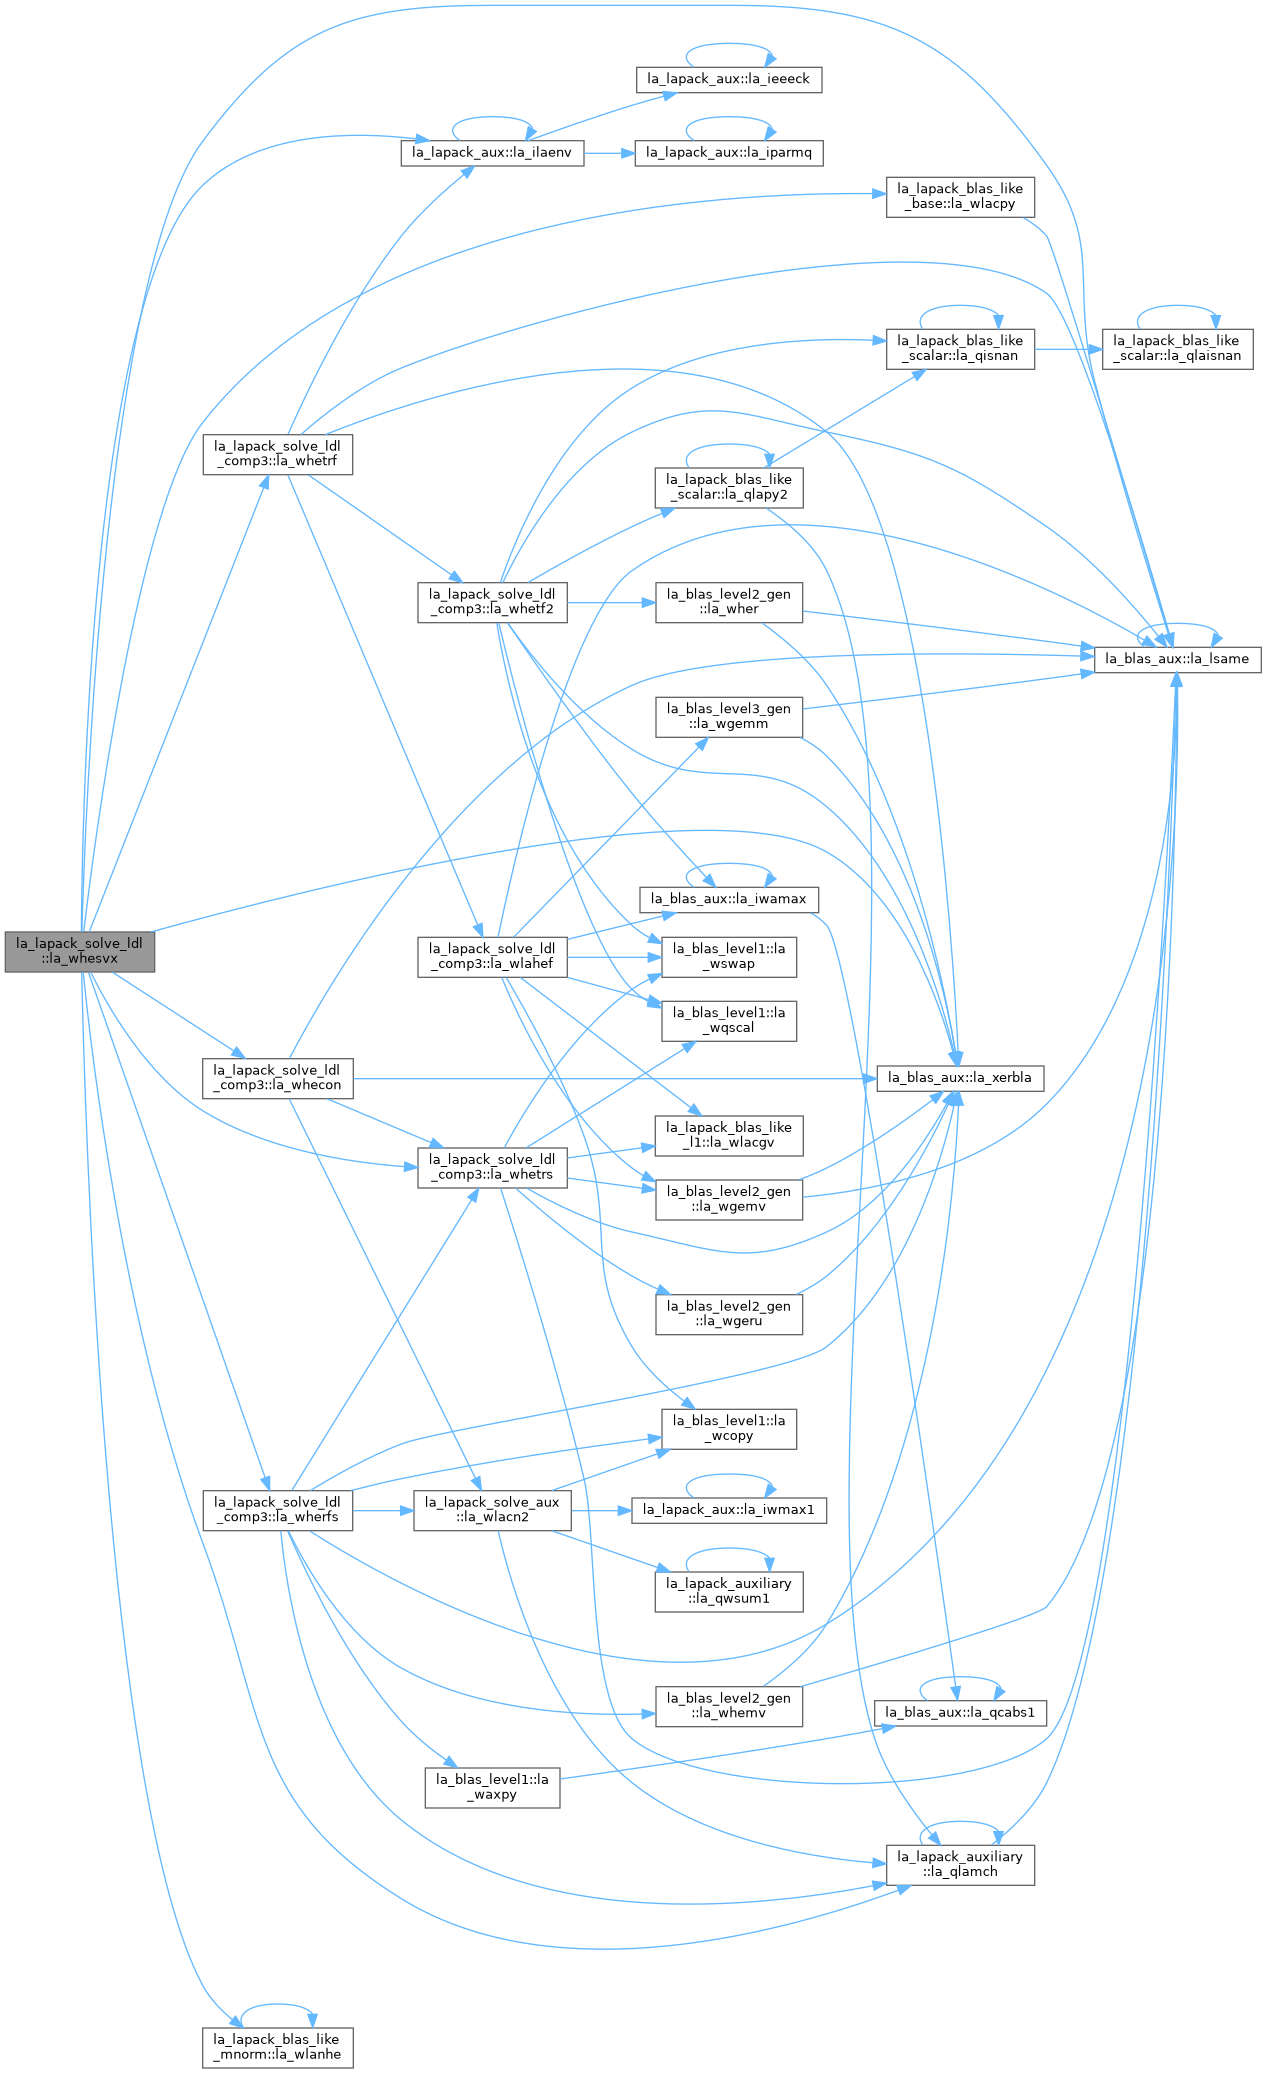
◆ la_whpsv()
| pure subroutine, public la_lapack_solve_ldl::la_whpsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
WHPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
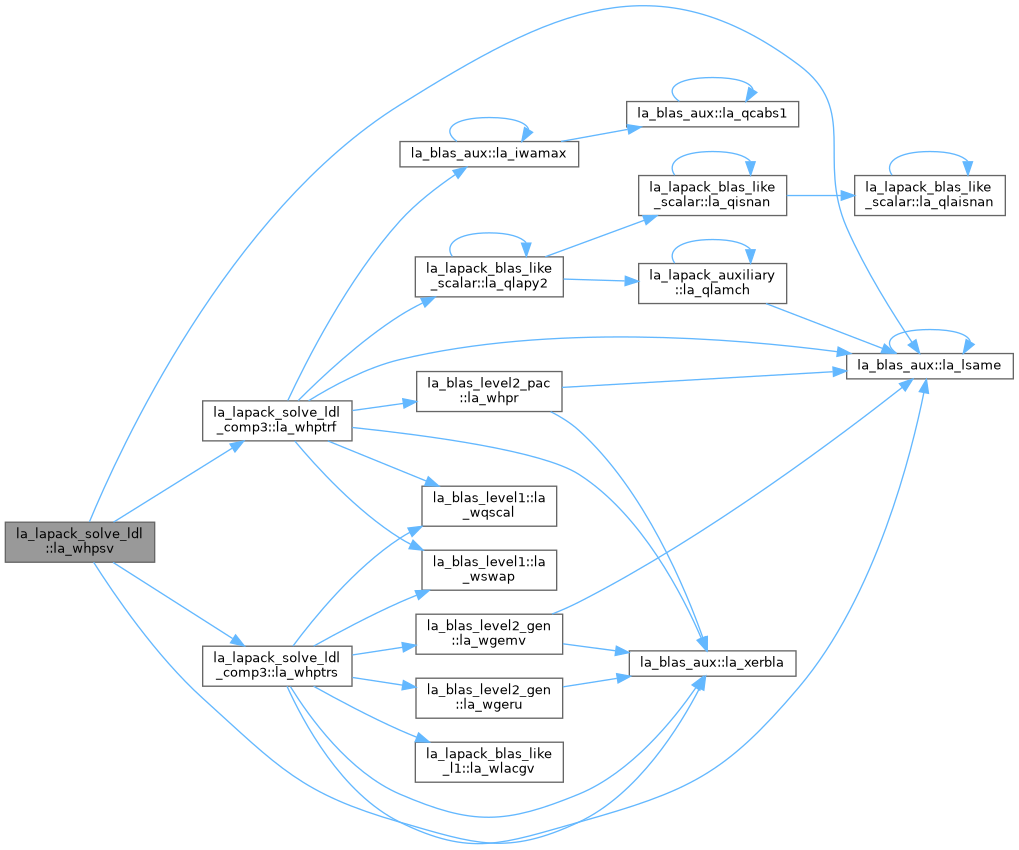
◆ la_whpsvx()
| subroutine, public la_lapack_solve_ldl::la_whpsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(*), intent(in) | ap, | ||
| complex(qp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(qp), intent(out) | rcond, | ||
| real(qp), dimension(*), intent(out) | ferr, | ||
| real(qp), dimension(*), intent(out) | berr, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| real(qp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
WHPSVX: uses the diagonal pivoting factorization A = U*D*U**H or A = L*D*L**H to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
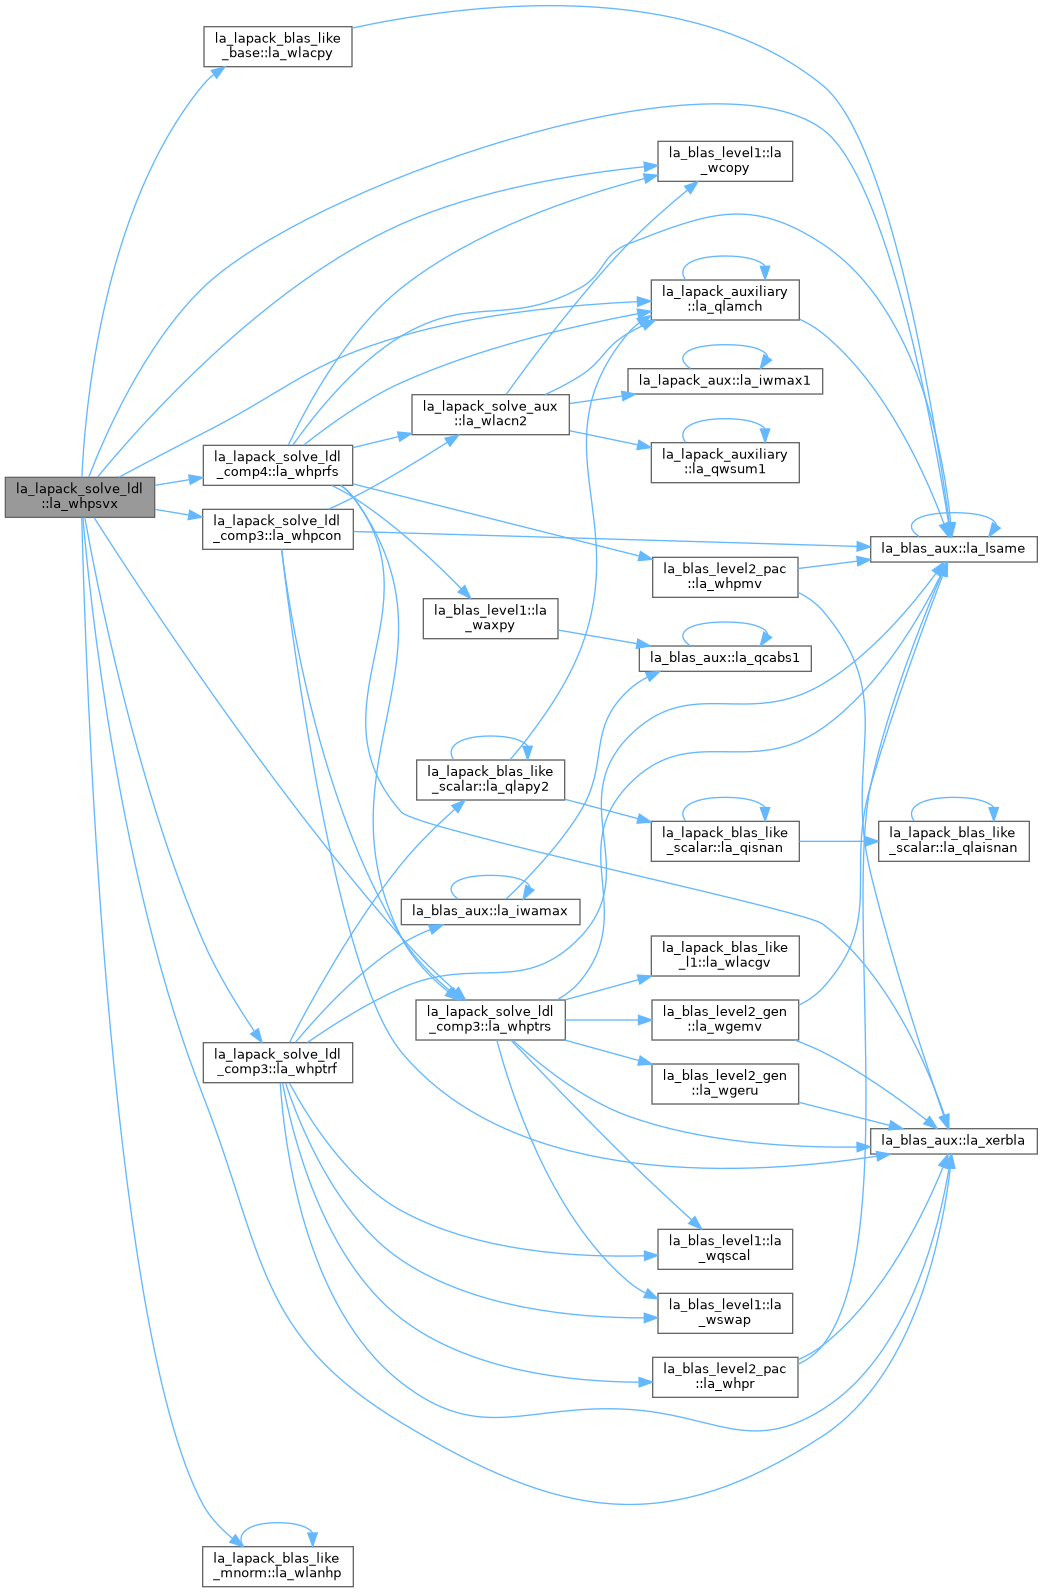
◆ la_wspsv()
| pure subroutine, public la_lapack_solve_ldl::la_wspsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
WSPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
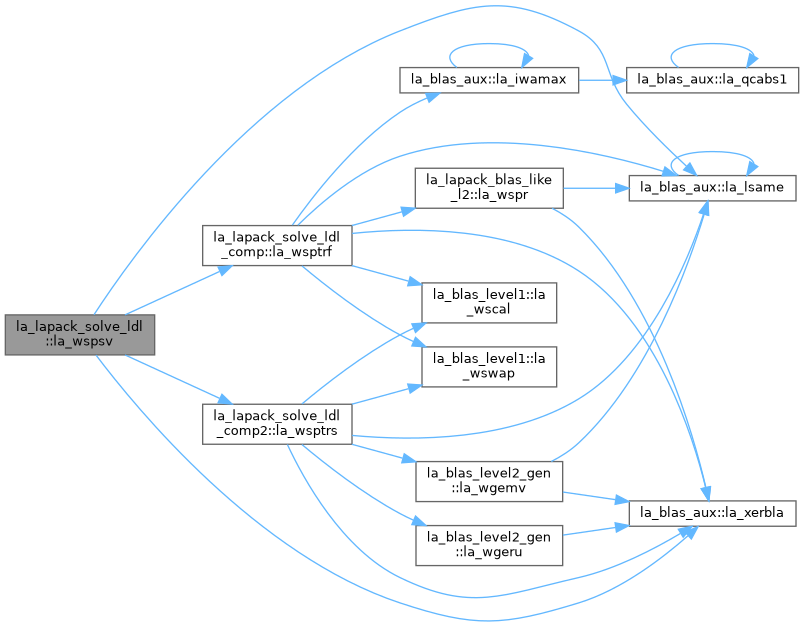
◆ la_wspsvx()
| subroutine, public la_lapack_solve_ldl::la_wspsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(*), intent(in) | ap, | ||
| complex(qp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(qp), intent(out) | rcond, | ||
| real(qp), dimension(*), intent(out) | ferr, | ||
| real(qp), dimension(*), intent(out) | berr, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| real(qp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
WSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
◆ la_wsysv()
| pure subroutine, public la_lapack_solve_ldl::la_wsysv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WSYSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_wsysv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_wsysv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WSYSV computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
◆ la_wsysv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_wsysv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(qp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WSYSV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WSYTRF_RK is called to compute the factorization of a complex symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine WSYTRS_3.
◆ la_wsysv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_wsysv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
WSYSV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. WSYTRF_ROOK is called to compute the factorization of a complex symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling WSYTRS_ROOK.
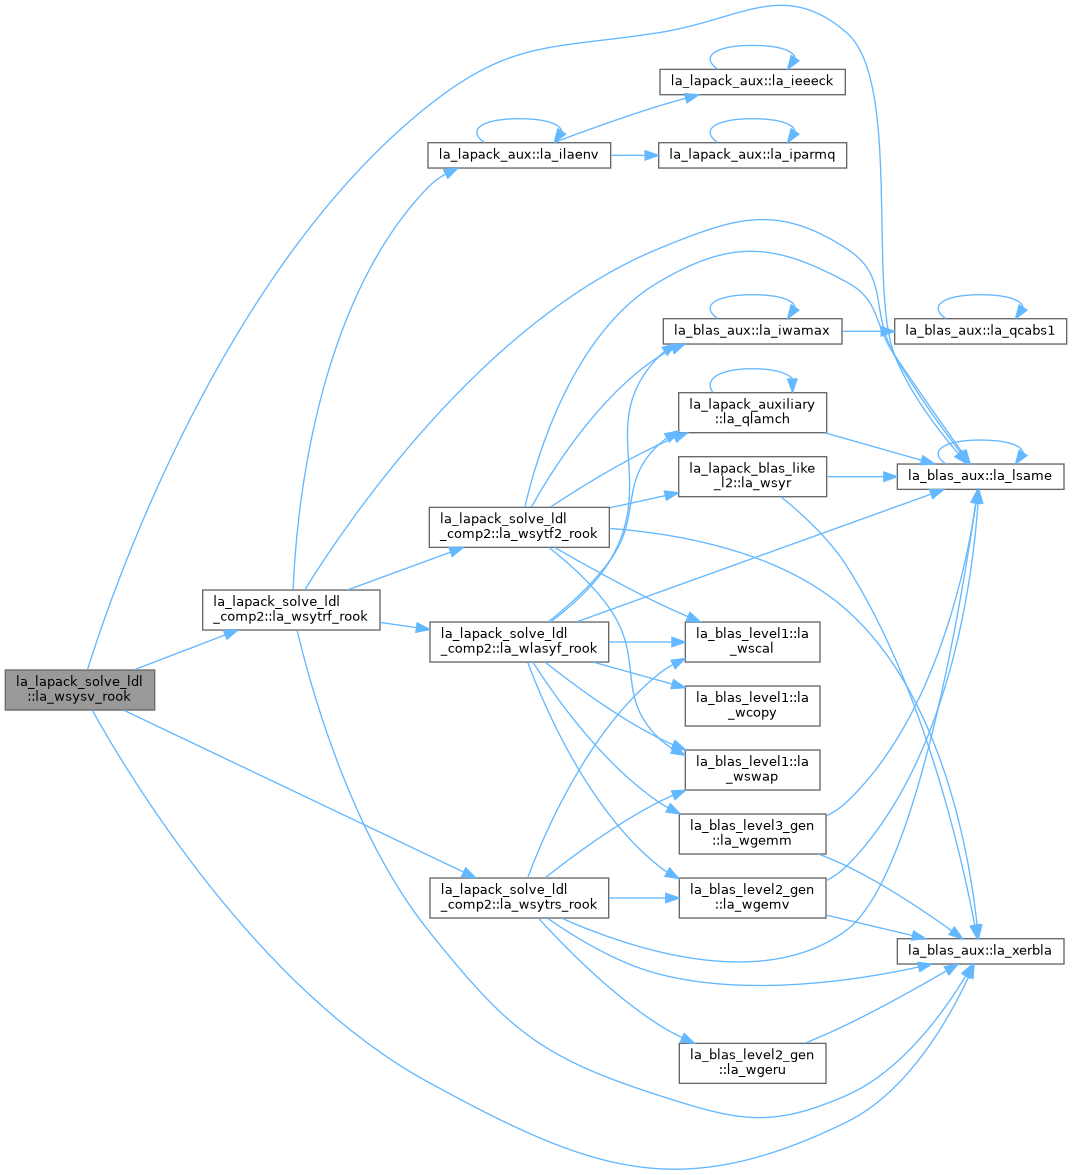
◆ la_wsysvx()
| subroutine, public la_lapack_solve_ldl::la_wsysvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(qp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(qp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(qp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(qp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(qp), intent(out) | rcond, | ||
| real(qp), dimension(*), intent(out) | ferr, | ||
| real(qp), dimension(*), intent(out) | berr, | ||
| complex(qp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| real(qp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
WSYSVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
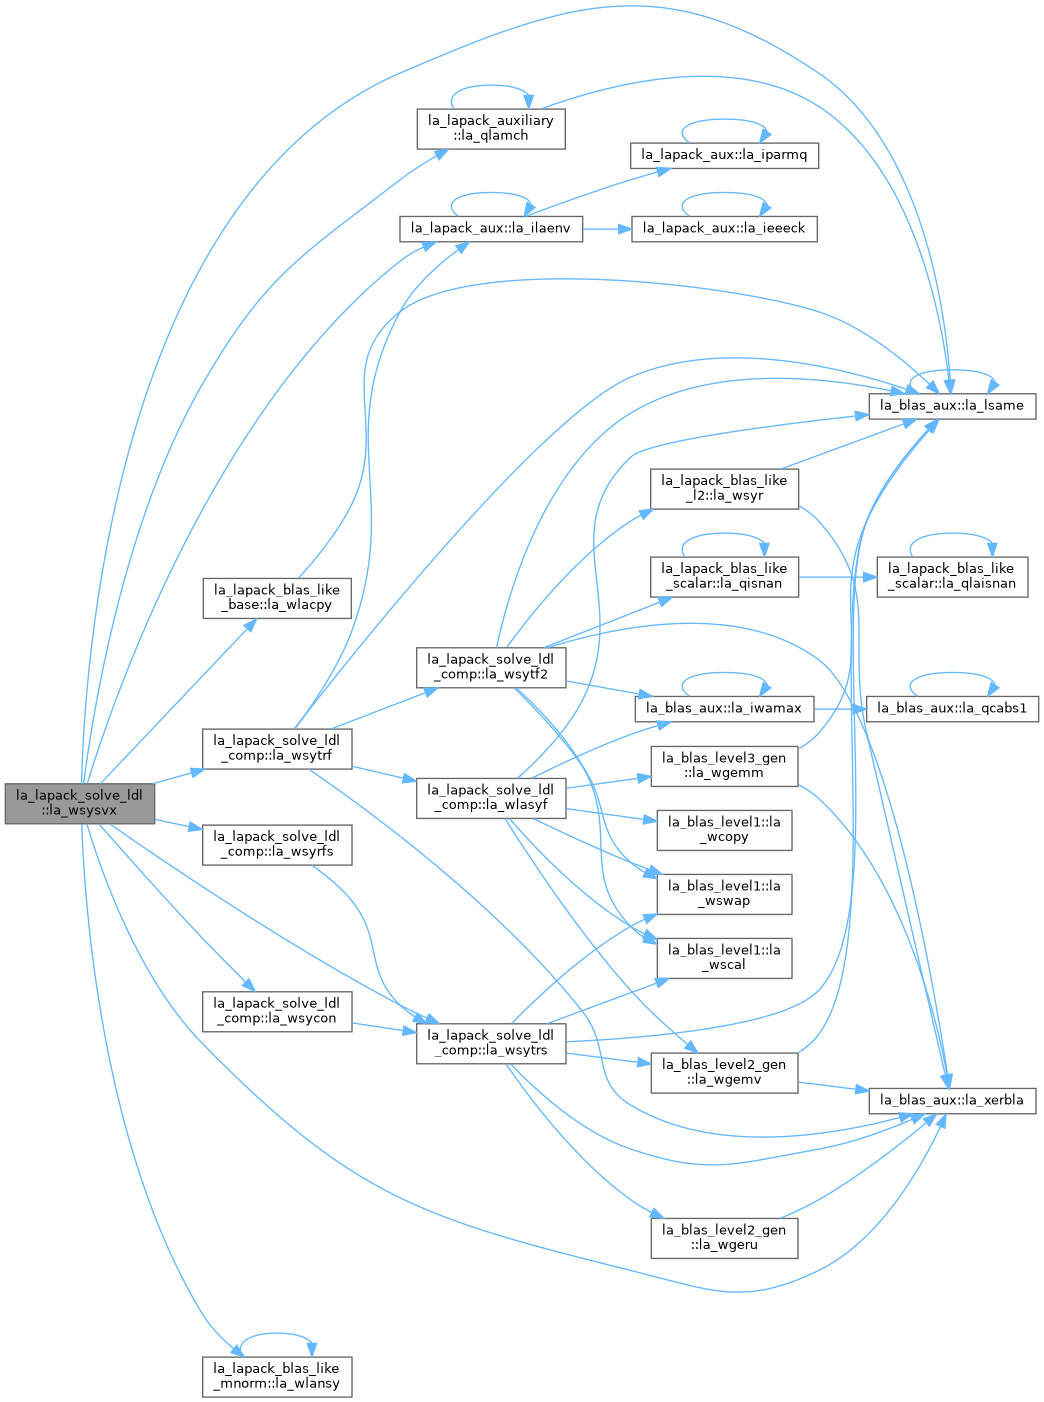
◆ la_zhesv()
| pure subroutine, public la_lapack_solve_ldl::la_zhesv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZHESV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
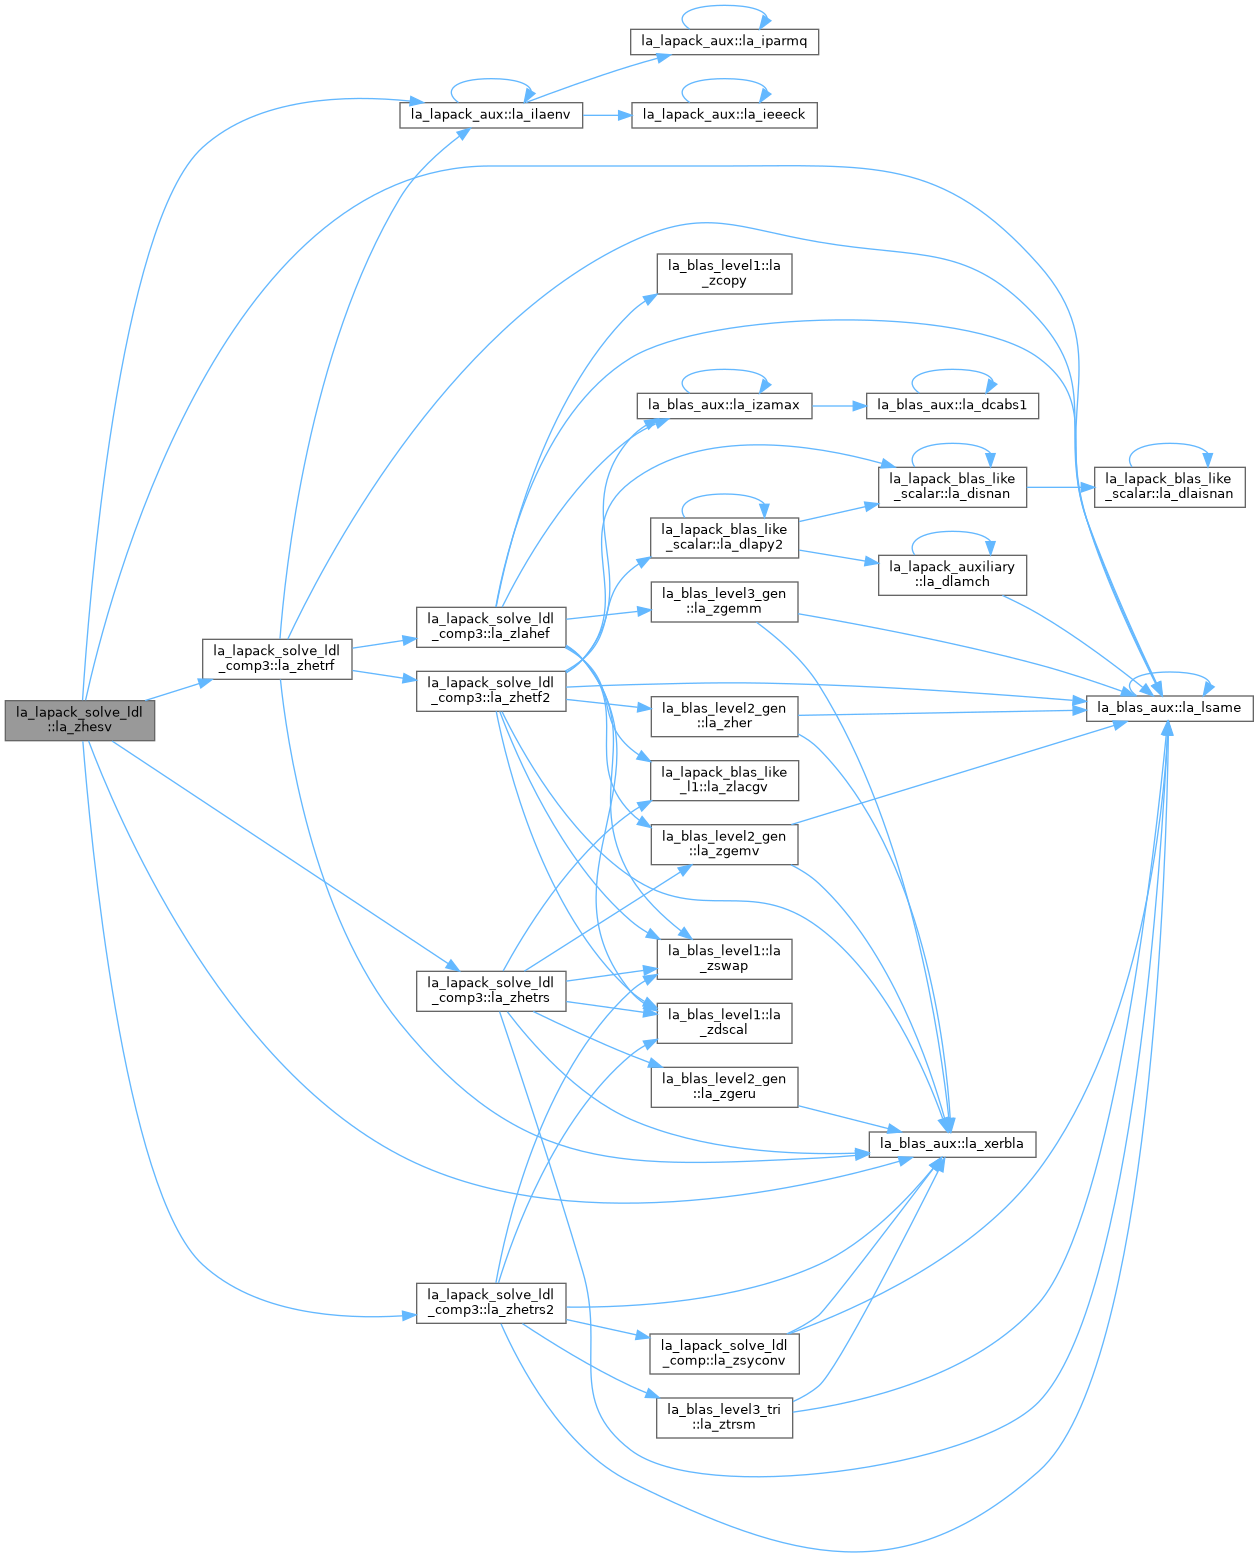
◆ la_zhesv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_zhesv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZHESV_AA: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**H * T * U, if UPLO = 'U', or A = L * T * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is Hermitian and tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
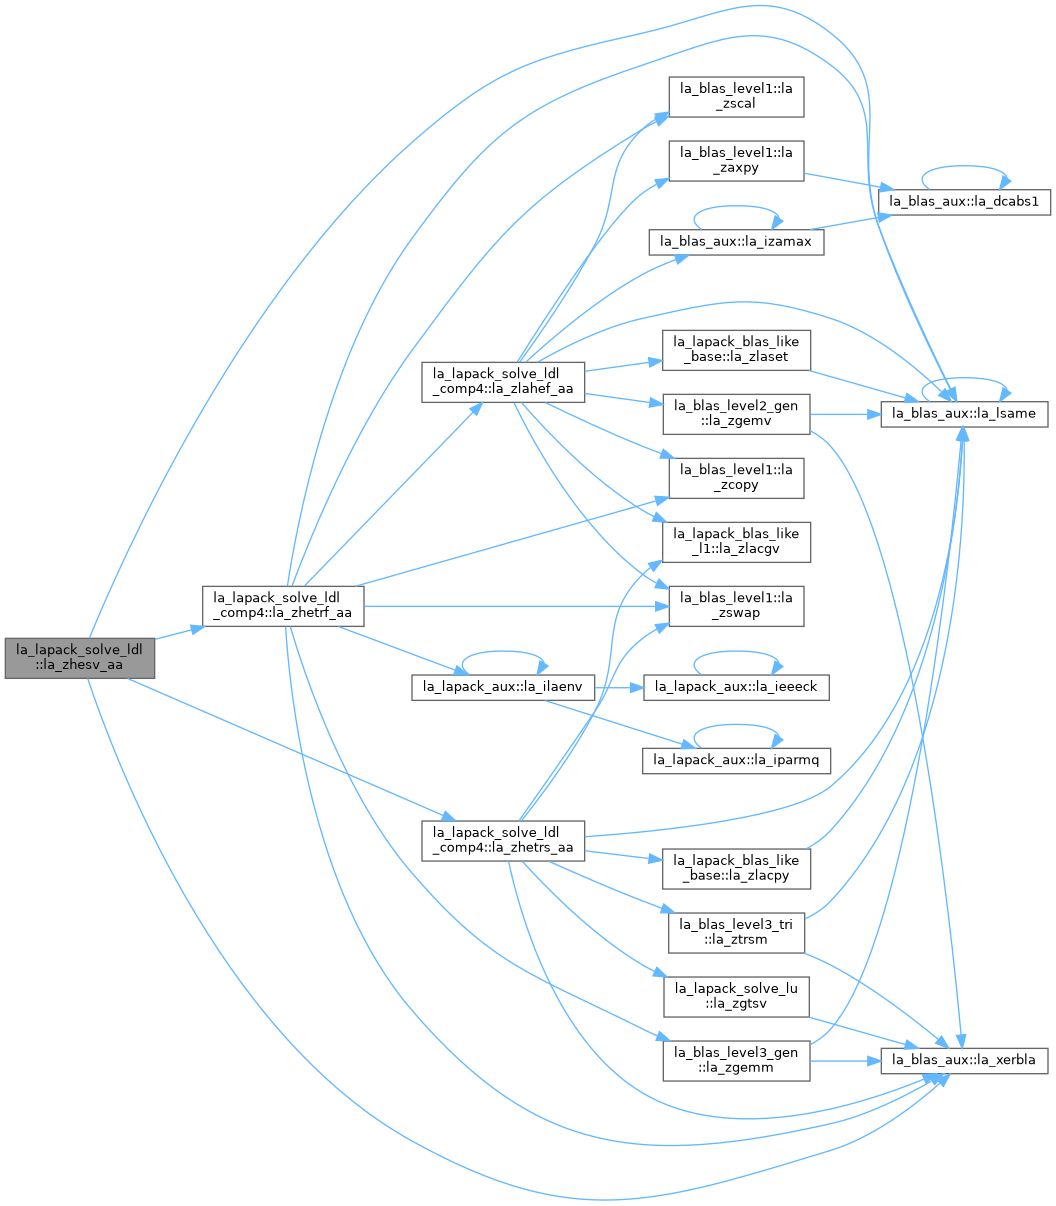
◆ la_zhesv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_zhesv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(dp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZHESV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**H)*(P**T), if UPLO = 'U', or A = P*L*D*(L**H)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**H (or L**H) is the conjugate of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZHETRF_RK is called to compute the factorization of a complex Hermitian matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine ZHETRS_3.
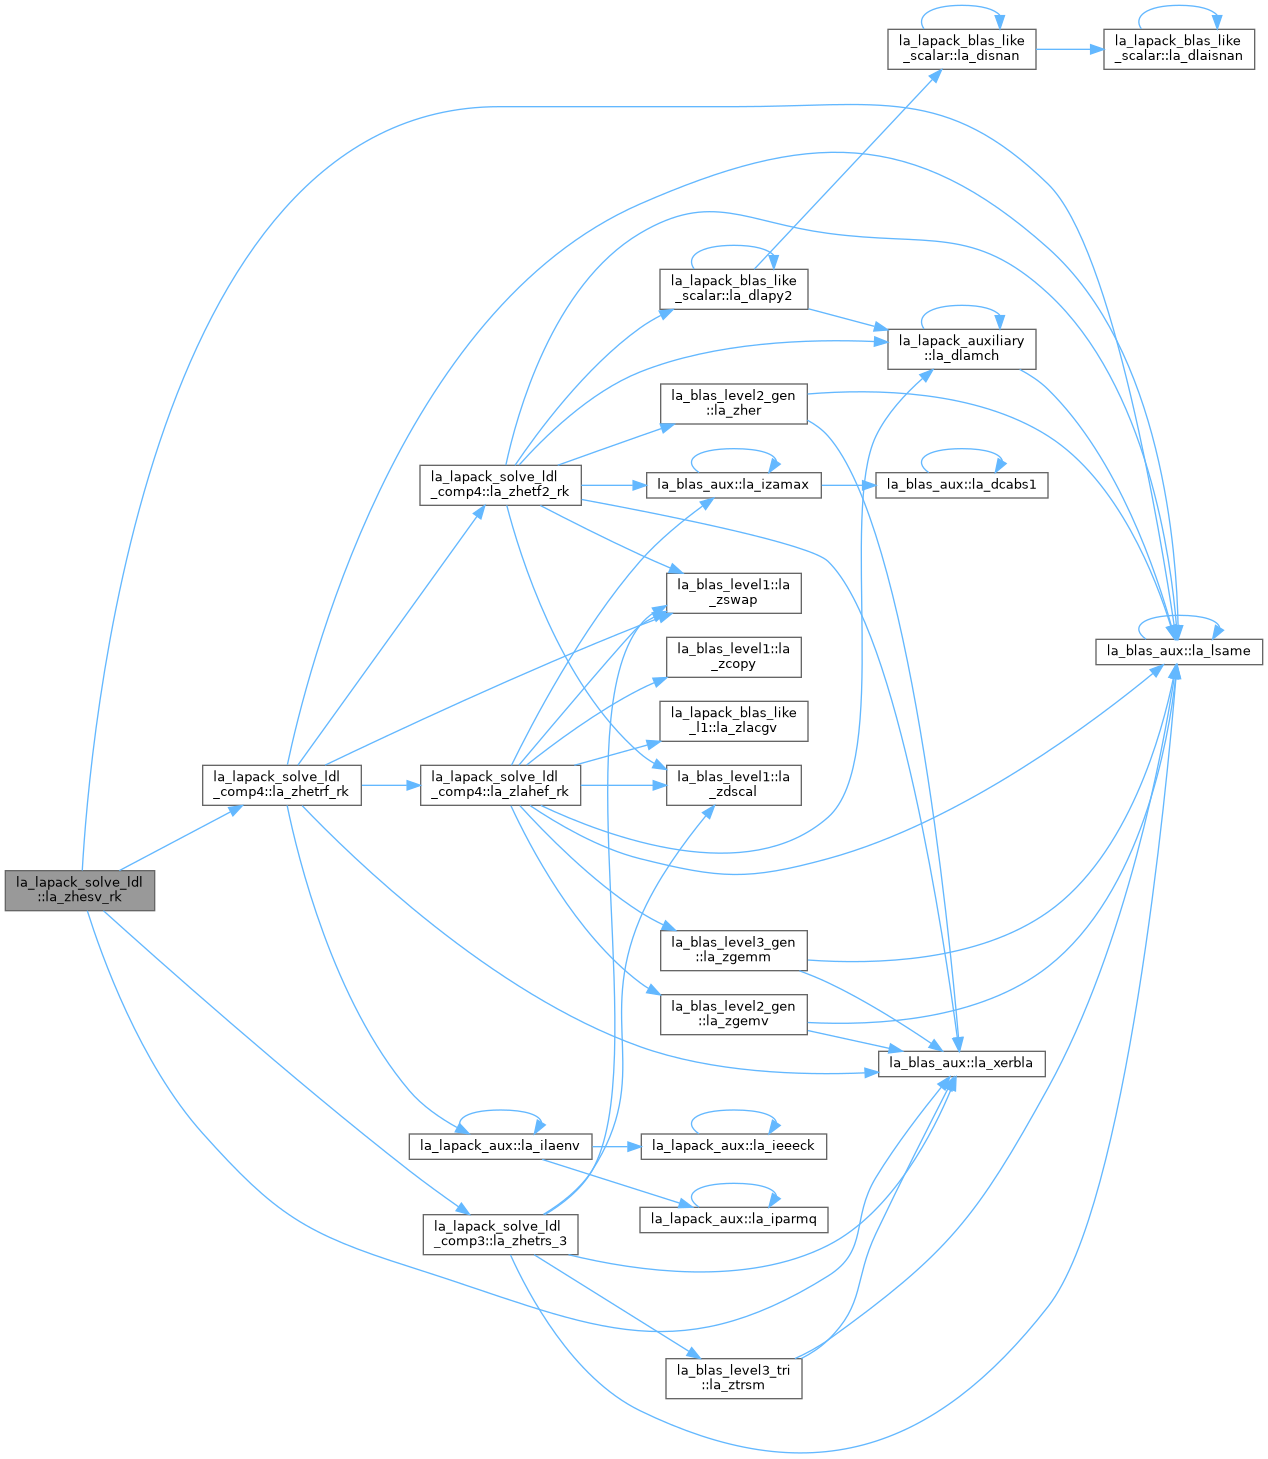
◆ la_zhesv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_zhesv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZHESV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman ("rook") diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZHETRF_ROOK is called to compute the factorization of a complex Hermition matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling ZHETRS_ROOK (uses BLAS 2).
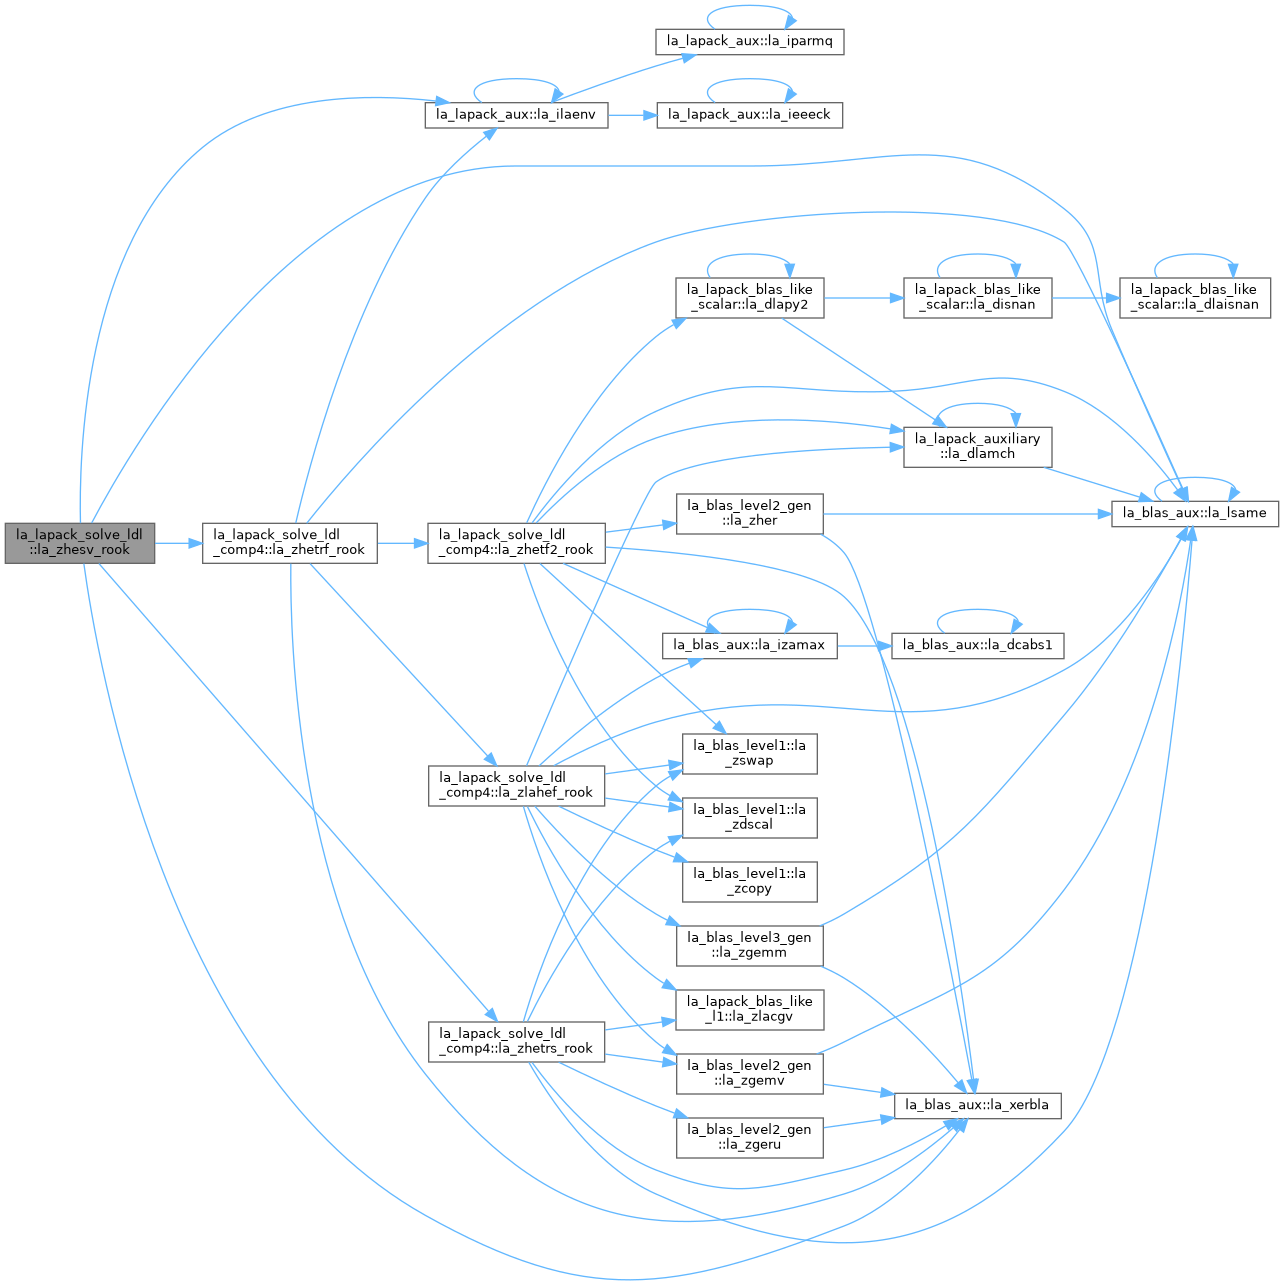
◆ la_zhesvx()
| subroutine, public la_lapack_solve_ldl::la_zhesvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(dp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(dp), intent(out) | rcond, | ||
| real(dp), dimension(*), intent(out) | ferr, | ||
| real(dp), dimension(*), intent(out) | berr, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| real(dp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
ZHESVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
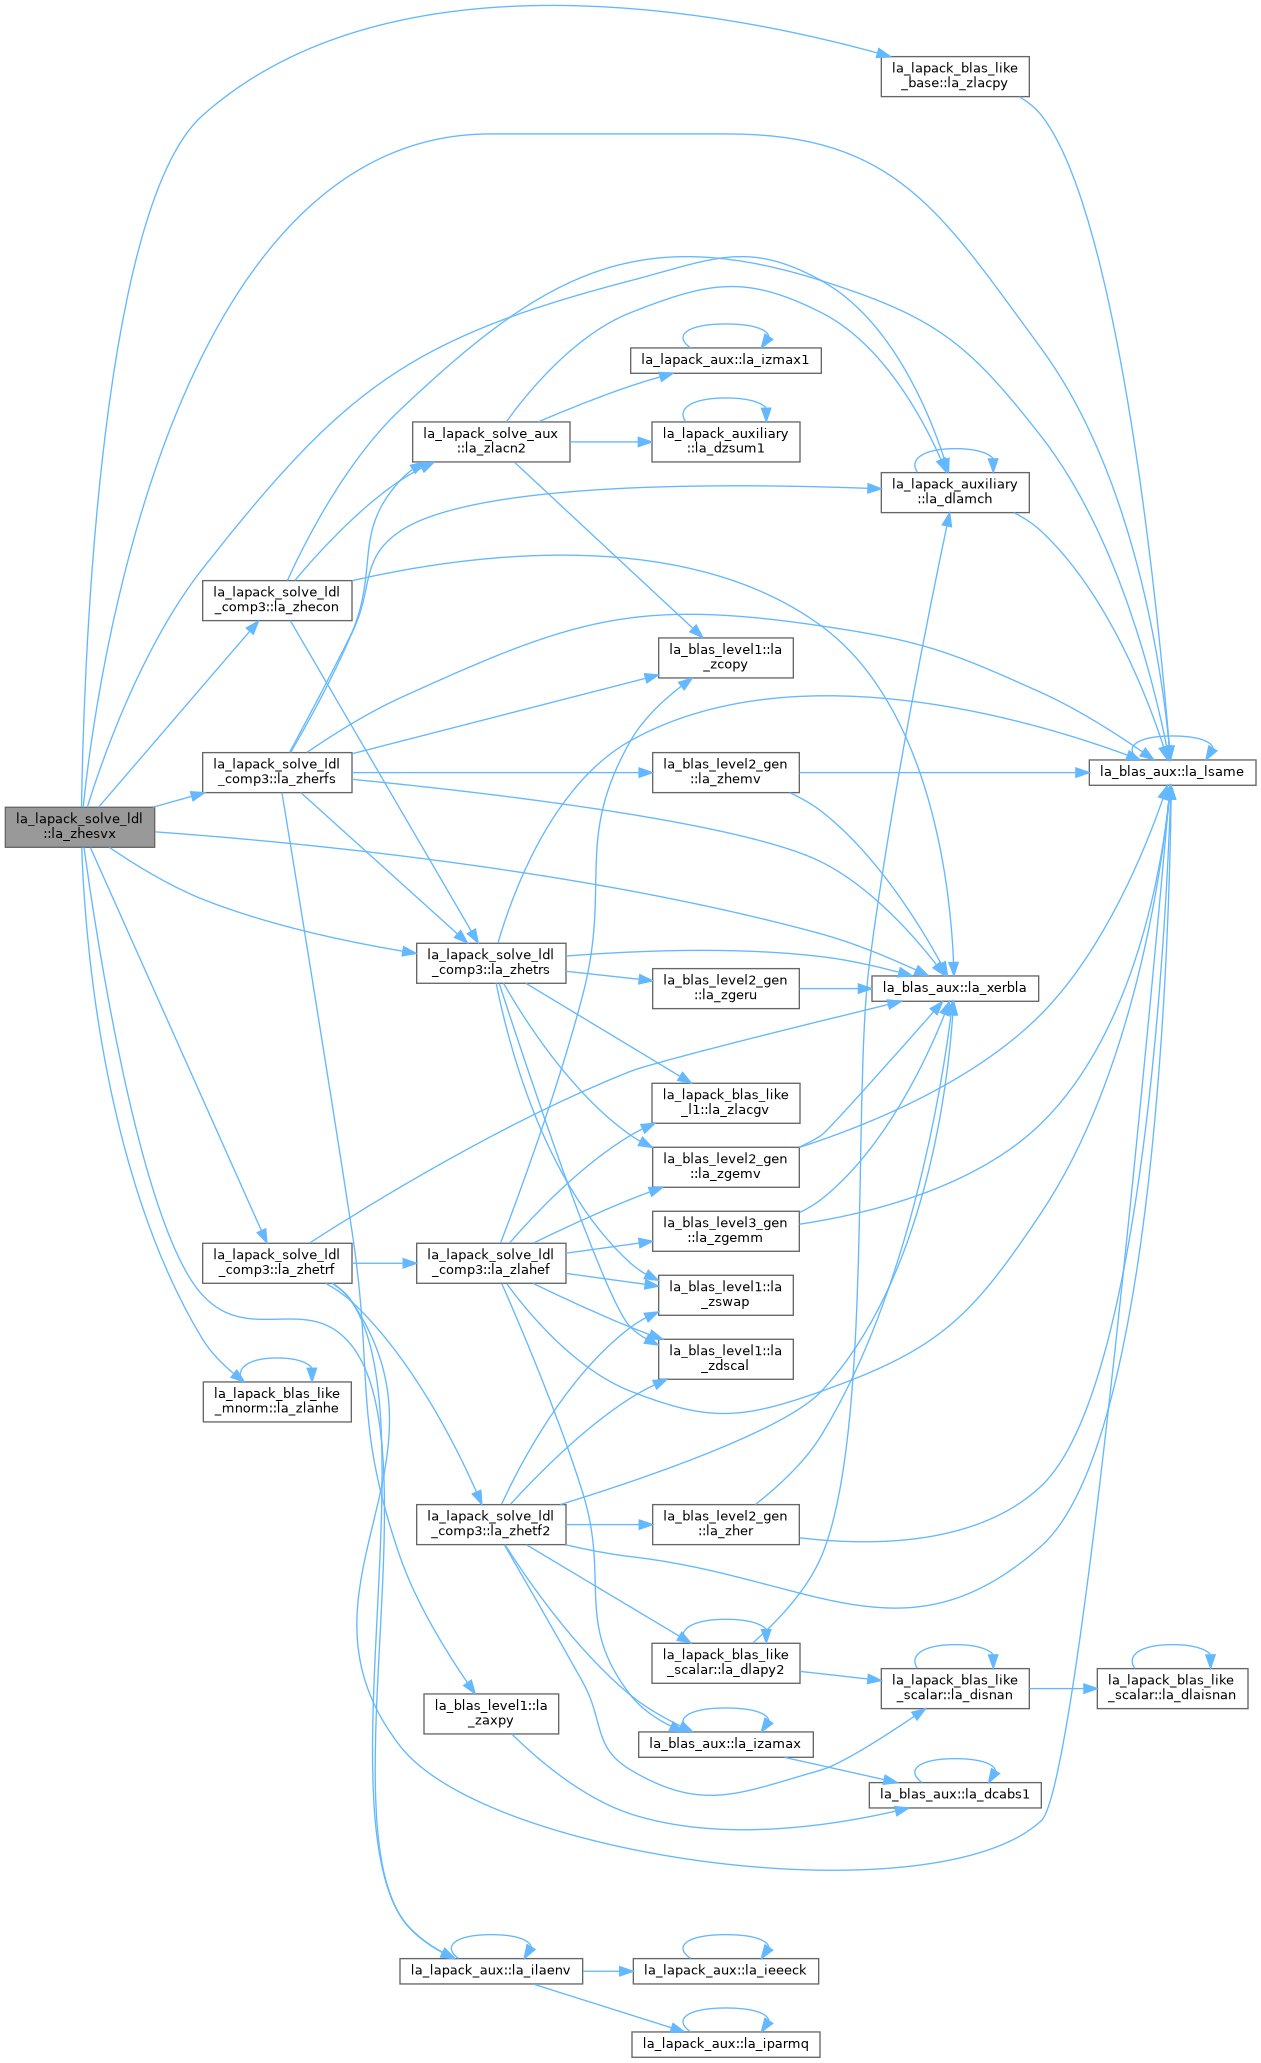
◆ la_zhpsv()
| pure subroutine, public la_lapack_solve_ldl::la_zhpsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
ZHPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**H, if UPLO = 'U', or A = L * D * L**H, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is Hermitian and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
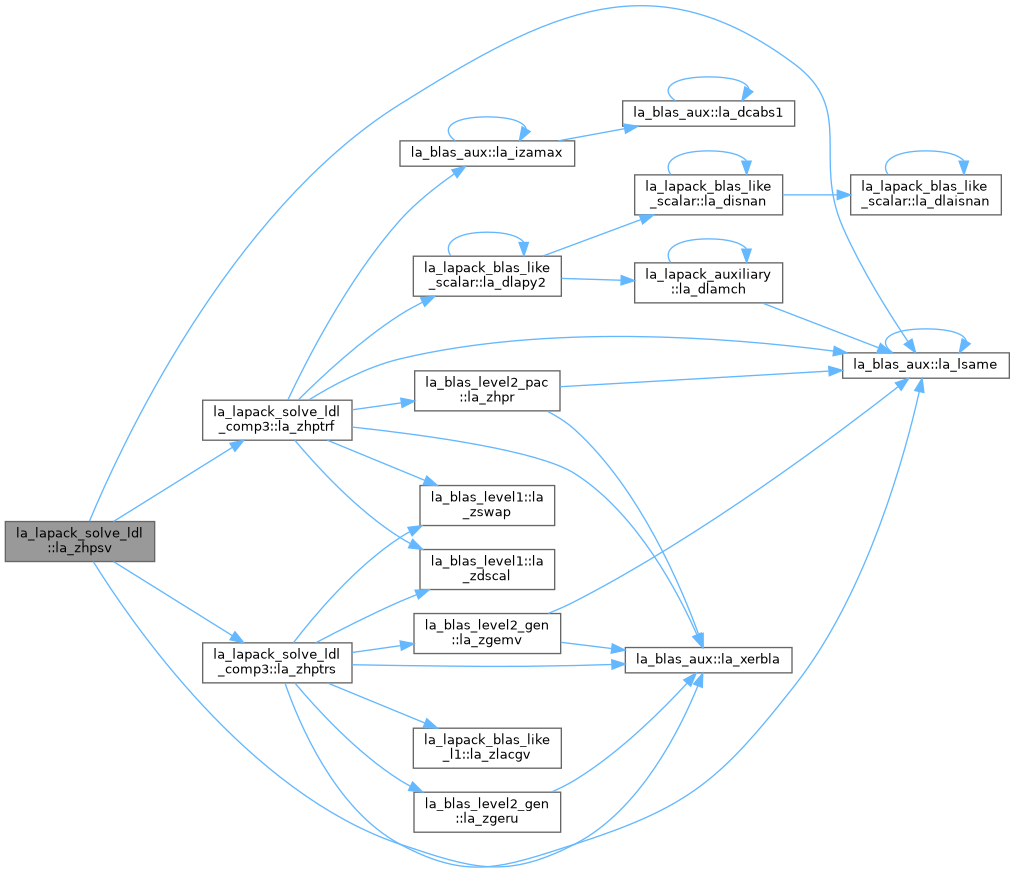
◆ la_zhpsvx()
| subroutine, public la_lapack_solve_ldl::la_zhpsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(*), intent(in) | ap, | ||
| complex(dp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(dp), intent(out) | rcond, | ||
| real(dp), dimension(*), intent(out) | ferr, | ||
| real(dp), dimension(*), intent(out) | berr, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| real(dp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
ZHPSVX: uses the diagonal pivoting factorization A = U*D*U**H or A = L*D*L**H to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N Hermitian matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
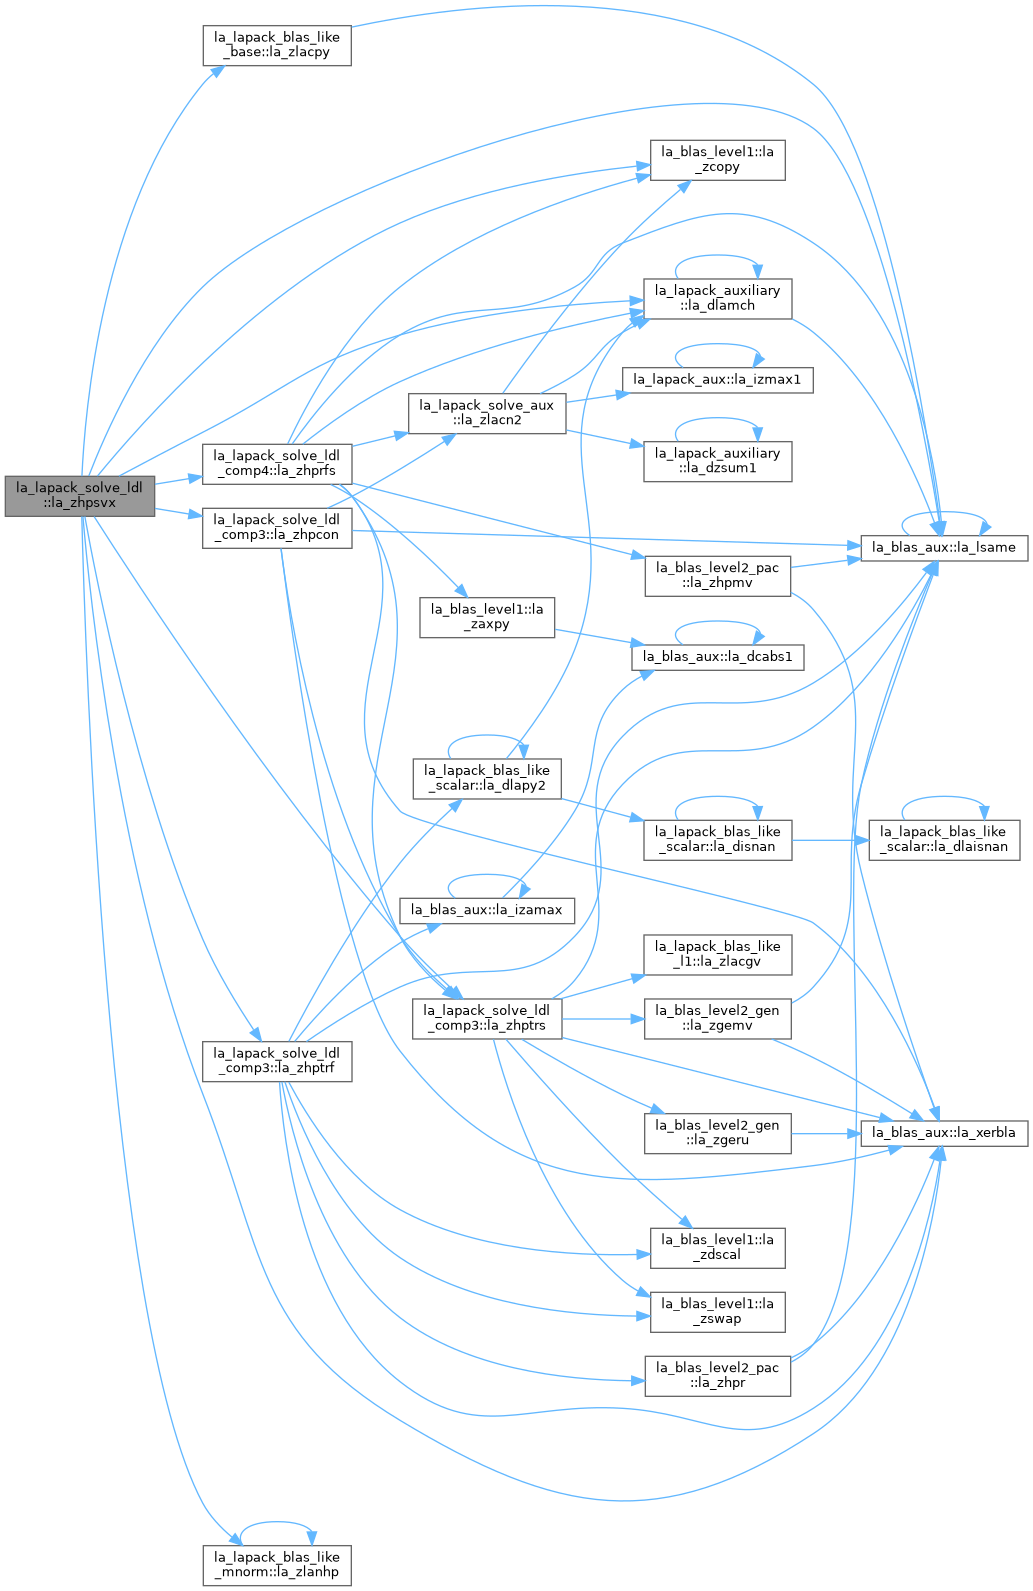
◆ la_zspsv()
| pure subroutine, public la_lapack_solve_ldl::la_zspsv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(*), intent(inout) | ap, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| integer(ilp), intent(out) | info ) |
ZSPSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
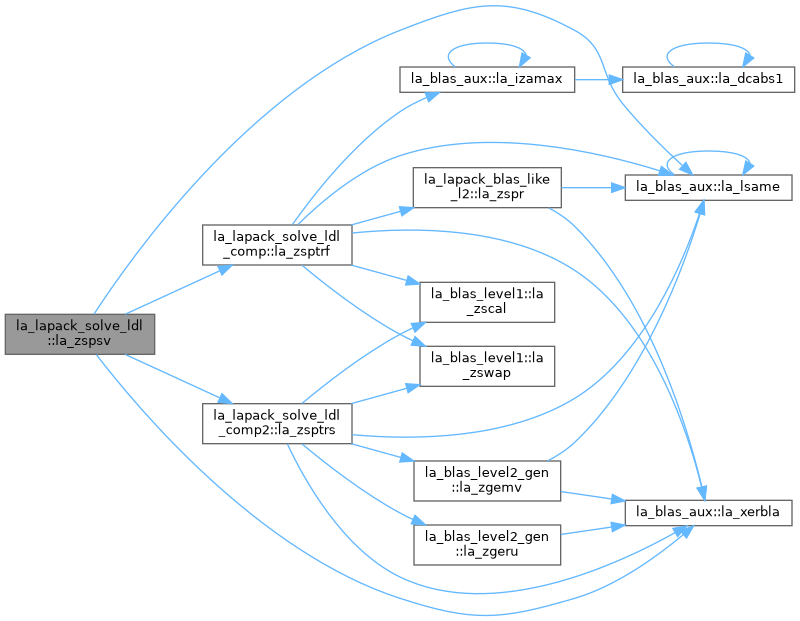
◆ la_zspsvx()
| subroutine, public la_lapack_solve_ldl::la_zspsvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(*), intent(in) | ap, | ||
| complex(dp), dimension(*), intent(inout) | afp, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(dp), intent(out) | rcond, | ||
| real(dp), dimension(*), intent(out) | ferr, | ||
| real(dp), dimension(*), intent(out) | berr, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| real(dp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
ZSPSVX: uses the diagonal pivoting factorization A = U*D*U**T or A = L*D*L**T to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix stored in packed format and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.
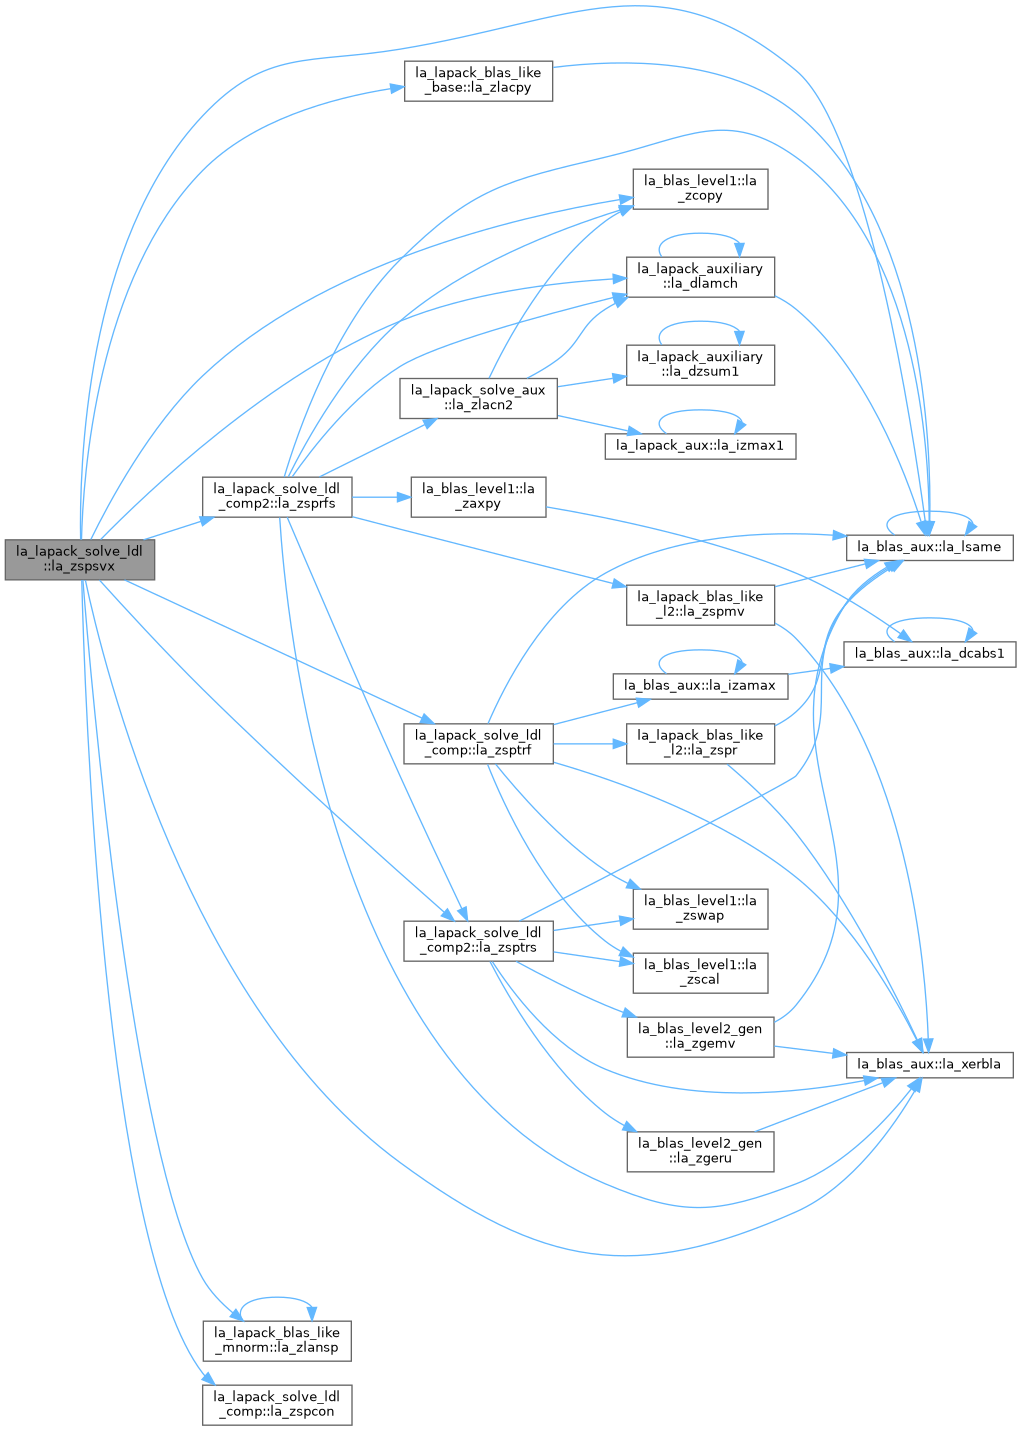
◆ la_zsysv()
| pure subroutine, public la_lapack_solve_ldl::la_zsysv | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZSYSV: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. The factored form of A is then used to solve the system of equations A * X = B.
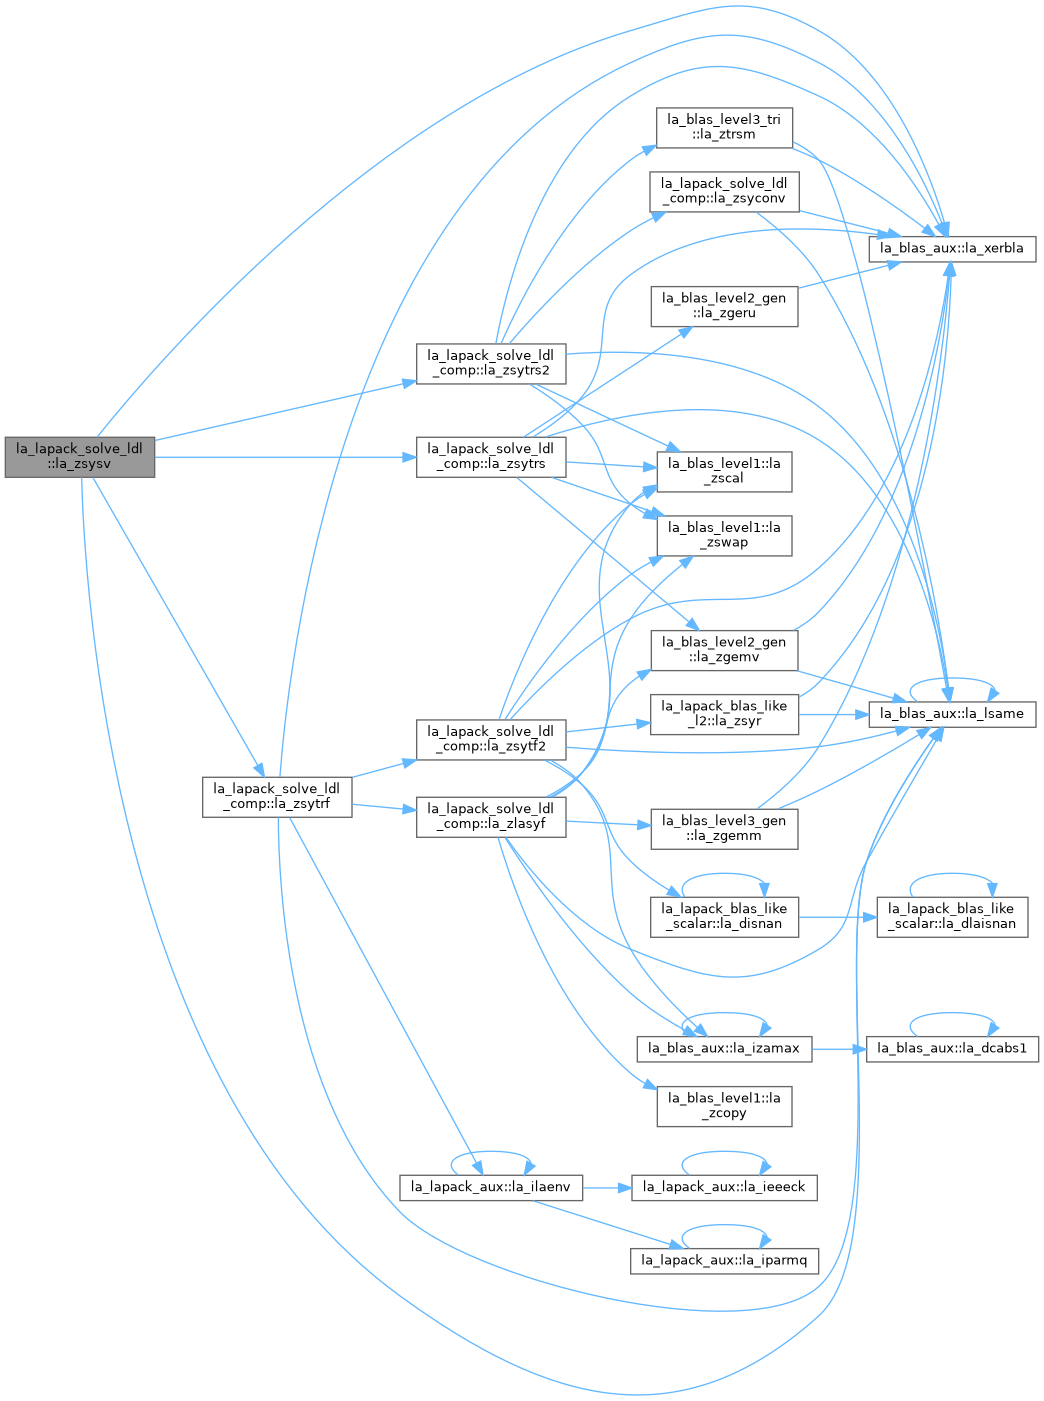
◆ la_zsysv_aa()
| pure subroutine, public la_lapack_solve_ldl::la_zsysv_aa | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZSYSV computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Aasen's algorithm is used to factor A as A = U**T * T * U, if UPLO = 'U', or A = L * T * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and T is symmetric tridiagonal. The factored form of A is then used to solve the system of equations A * X = B.
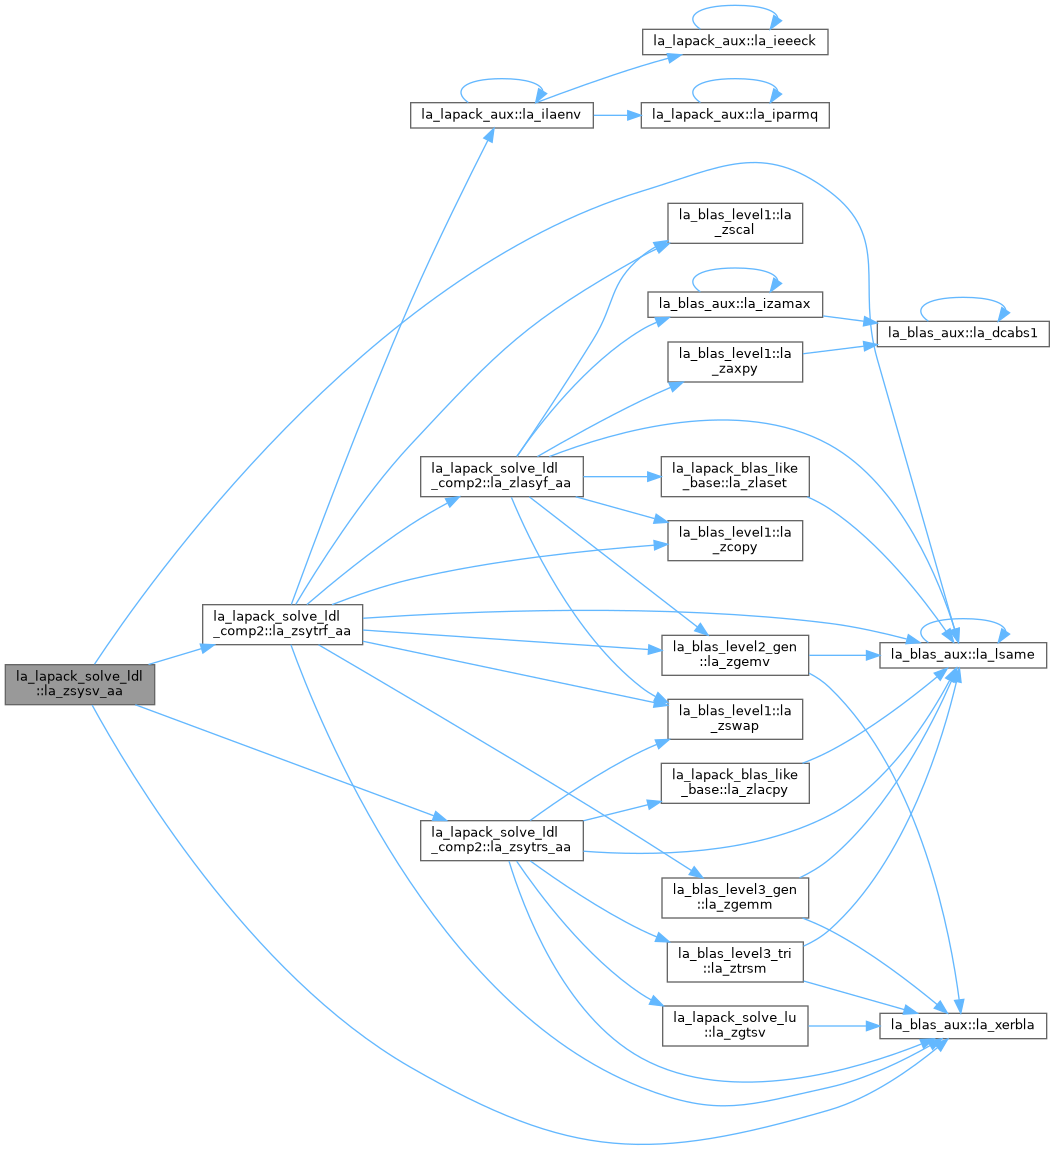
◆ la_zsysv_rk()
| pure subroutine, public la_lapack_solve_ldl::la_zsysv_rk | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(dp), dimension(*), intent(out) | e, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZSYSV_RK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The bounded Bunch-Kaufman (rook) diagonal pivoting method is used to factor A as A = P*U*D*(U**T)*(P**T), if UPLO = 'U', or A = P*L*D*(L**T)*(P**T), if UPLO = 'L', where U (or L) is unit upper (or lower) triangular matrix, U**T (or L**T) is the transpose of U (or L), P is a permutation matrix, P**T is the transpose of P, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZSYTRF_RK is called to compute the factorization of a complex symmetric matrix. The factored form of A is then used to solve the system of equations A * X = B by calling BLAS3 routine ZSYTRS_3.
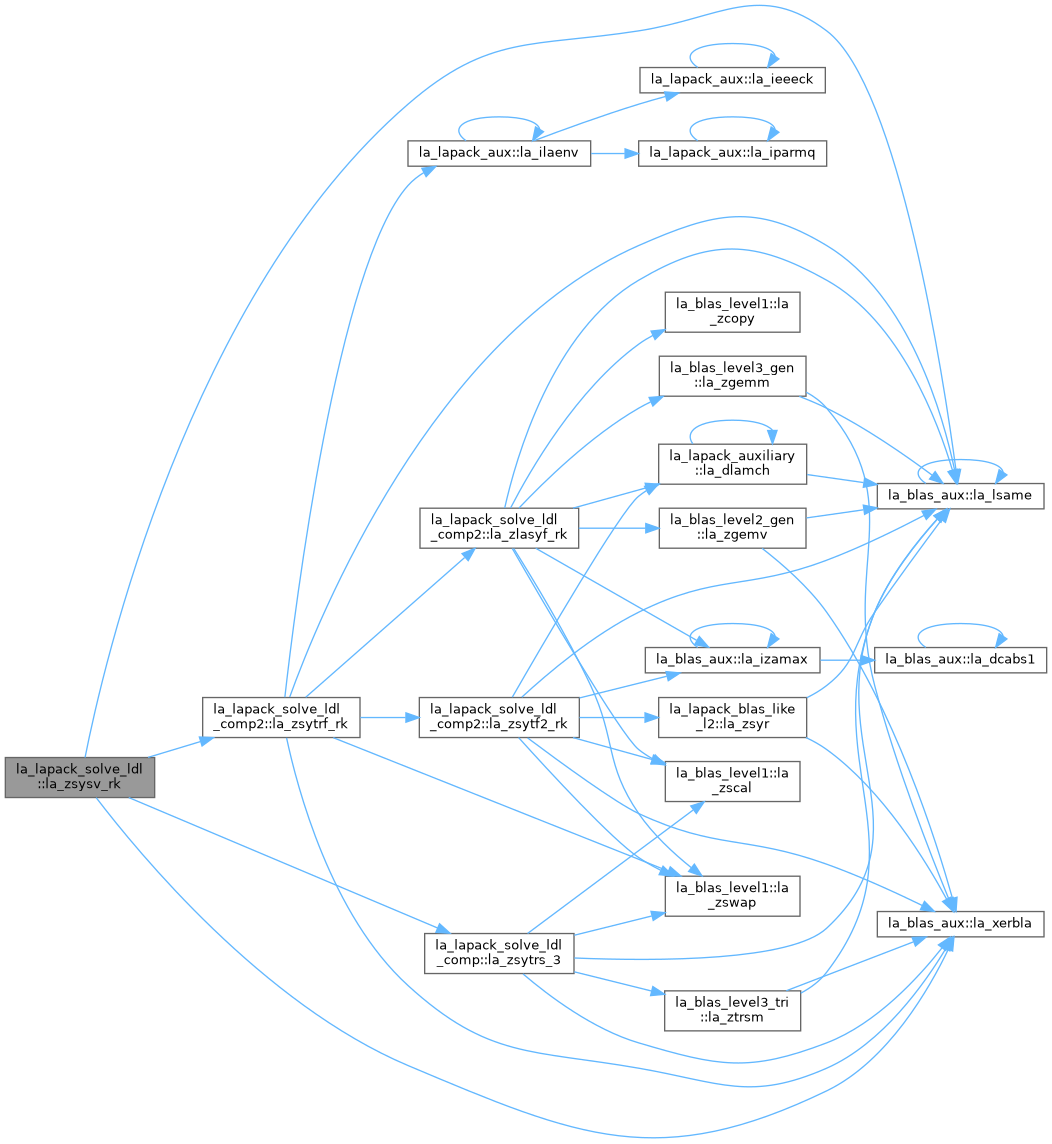
◆ la_zsysv_rook()
| pure subroutine, public la_lapack_solve_ldl::la_zsysv_rook | ( | character, intent(in) | uplo, |
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(inout) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| integer(ilp), dimension(*), intent(out) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(inout) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| integer(ilp), intent(out) | info ) |
ZSYSV_ROOK: computes the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. The diagonal pivoting method is used to factor A as A = U * D * U**T, if UPLO = 'U', or A = L * D * L**T, if UPLO = 'L', where U (or L) is a product of permutation and unit upper (lower) triangular matrices, and D is symmetric and block diagonal with 1-by-1 and 2-by-2 diagonal blocks. ZSYTRF_ROOK is called to compute the factorization of a complex symmetric matrix A using the bounded Bunch-Kaufman ("rook") diagonal pivoting method. The factored form of A is then used to solve the system of equations A * X = B by calling ZSYTRS_ROOK.
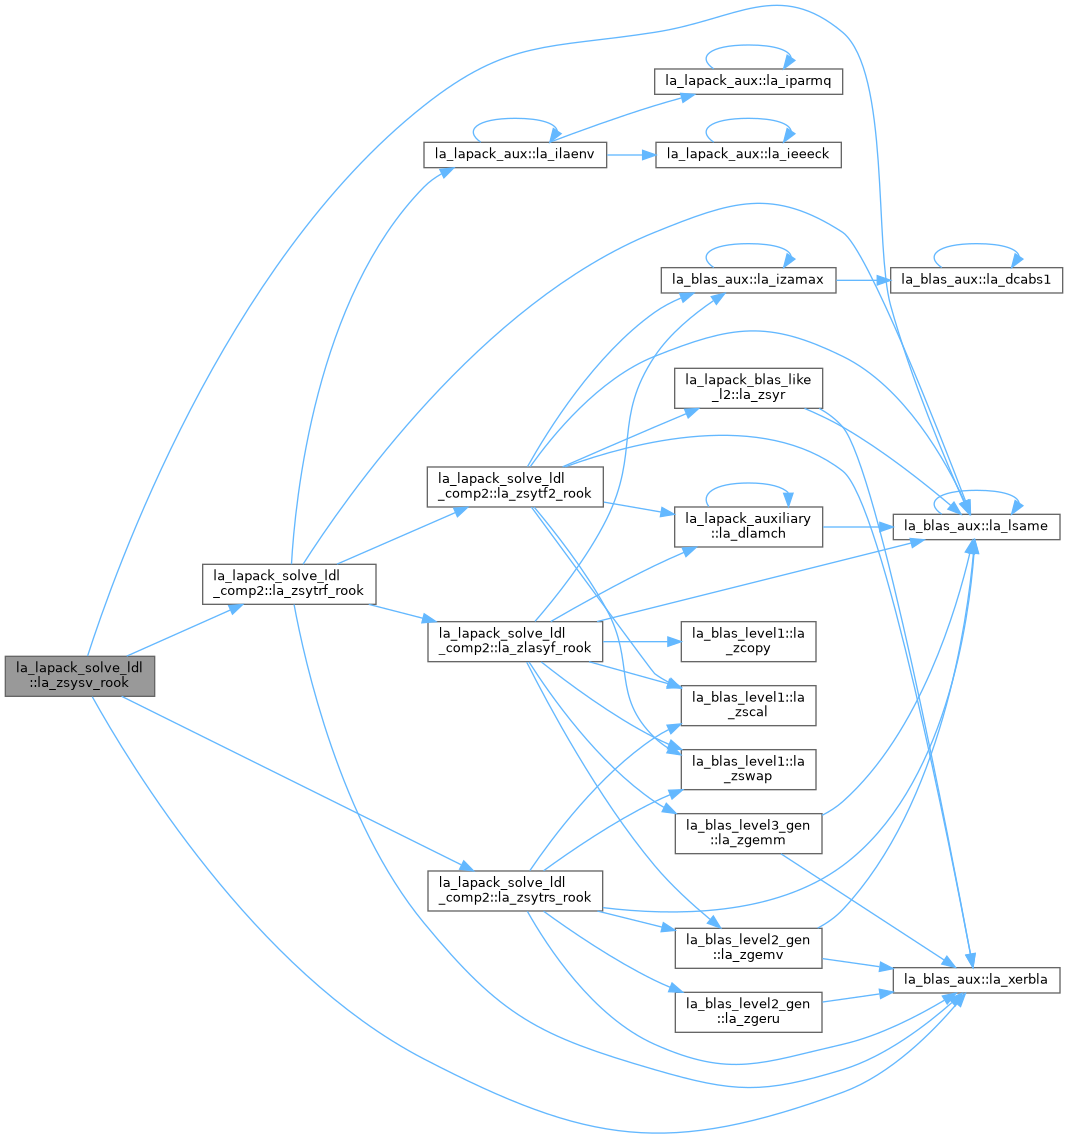
◆ la_zsysvx()
| subroutine, public la_lapack_solve_ldl::la_zsysvx | ( | character, intent(in) | fact, |
| character, intent(in) | uplo, | ||
| integer(ilp), intent(in) | n, | ||
| integer(ilp), intent(in) | nrhs, | ||
| complex(dp), dimension(lda,*), intent(in) | a, | ||
| integer(ilp), intent(in) | lda, | ||
| complex(dp), dimension(ldaf,*), intent(inout) | af, | ||
| integer(ilp), intent(in) | ldaf, | ||
| integer(ilp), dimension(*), intent(inout) | ipiv, | ||
| complex(dp), dimension(ldb,*), intent(in) | b, | ||
| integer(ilp), intent(in) | ldb, | ||
| complex(dp), dimension(ldx,*), intent(out) | x, | ||
| integer(ilp), intent(in) | ldx, | ||
| real(dp), intent(out) | rcond, | ||
| real(dp), dimension(*), intent(out) | ferr, | ||
| real(dp), dimension(*), intent(out) | berr, | ||
| complex(dp), dimension(*), intent(out) | work, | ||
| integer(ilp), intent(in) | lwork, | ||
| real(dp), dimension(*), intent(out) | rwork, | ||
| integer(ilp), intent(out) | info ) |
ZSYSVX: uses the diagonal pivoting factorization to compute the solution to a complex system of linear equations A * X = B, where A is an N-by-N symmetric matrix and X and B are N-by-NRHS matrices. Error bounds on the solution and a condition estimate are also provided.